10/20/2026
JR West Rolls Out New Railway Maintenance Robots
Single-arm heavy lifter and improved humanoid for overhead lines and tree cutting.
Read full story →The humanoid adjusts mid-motion during handshakes, fist bumps, and high-fives using on-device VLA 2.0, reassessing the scene roughly every 0.2 seconds.
XPENG has released video of its IRON humanoid following a person’s changing hand gestures without spoken commands. In the sequence a tester offers a handshake, switches to a fist bump, and then moves into a high-five. When the target shifts beyond the reach of the arm IRON first extends, the robot brings in its other hand. The company attributes the behavior to an upgraded VLA 2.0 model running on-device, with stronger temporal understanding and future-behavior prediction. XPENG states that the robot reassesses the visual scene approximately every 0.2 seconds and predicts action changes within about six seconds. The footage is labeled an R&D test-version demonstration. No success rates, end-to-end latency figures, or results across multiple users have been published. The video shows continuous observation and adjustment rather than a fixed routine completed before the next response. IRON is XPENG’s general-purpose humanoid that uses the company’s Physical AI foundation.
Fixed gesture recognition followed by a complete pre-planned motion is simpler to implement but fails when a person changes intention midway. Continuous re-evaluation while the arm is already moving requires the model to update its plan in real time. XPENG’s description of on-device VLA 2.0 inference matches the visual result in the clip. The same model family is used in the company’s vehicles. Transferring temporal prediction capability to the humanoid is a company claim. The 0.2-second interval and six-second horizon are XPENG figures. Independent timing measurements have not been released. The demonstration is useful as a qualitative illustration of adaptive upper-body interaction. It does not show the same behavior in unstructured public environments, under varying lighting, or with people who move more erratically than the staged tester. The company notes that final product behavior may differ from the development footage.
IRON incorporates a spine-like core, bionic muscle layout, and soft skin covering. The interaction test focuses on upper-body coordination and the ability to switch limbs when the target moves. Earlier XPENG videos have shown the robot walking, tracking speakers with a microphone array and lip reading, and holding multi-language conversations. The current clip isolates the gesture-following loop. No contact-force data or safety margins for the handshake and high-five interactions have been published. For researchers studying closed-loop human-robot interaction, the relevant open questions are the actual latency of the vision-to-motion cycle, the robustness of the prediction when intentions change rapidly, and the force limits during physical contact. Those details are not included in the promotional video. The sequence demonstrates on-device temporal reasoning applied to social motion under controlled conditions.
VLA 2.0 is XPENG’s vision-language-action model. The company has deployed versions in its vehicles and is applying an upgraded version to IRON. The on-device claim indicates that inference occurs on the robot’s compute rather than in the cloud. IRON carries multiple Turing chips. The video does not show the internal compute configuration or power draw during the interaction. Continuous adjustment during a short social gesture is a limited but visible test of the loop. Broader claims of general social competence would require longer trials with more varied participants and environments. No such data have been released. The demonstration is consistent with XPENG’s positioning of IRON as a platform that combines physical motion with real-time AI. The video remains the primary public evidence of the adaptive interaction behavior.
XPENG has shown its IRON humanoid adjusting in real time during handshakes, fist bumps, and high-fives without spoken commands. The company attributes the behavior to an upgraded on-device VLA 2.0 model with temporal understanding and prediction. The robot is said to reassess the scene roughly every 0.2 seconds. The video demonstrates continuous observation and motion adjustment under controlled conditions. No independent metrics have been published. The sequence is an R&D test-version demonstration. Final product behavior may differ. The clip illustrates adaptive social interaction on the IRON platform. No long-duration or unstructured public trials of the same capability have been released.
XPENG’s IRON humanoid follows changing hand gestures in real time without spoken commands. The company links the behavior to an upgraded on-device VLA 2.0 model that reassesses the scene approximately every 0.2 seconds. The video shows the robot switching hands and modifying its motion mid-interaction. The footage is a controlled development demonstration. No independent latency or success-rate data have been published. The demonstration focuses on adaptive upper-body interaction. Broader operational results in unstructured settings remain unreleased. The platform continues to be developed as a general-purpose humanoid using XPENG’s Physical AI stack.
Finnish integrator Siipotec has delivered an automated production system for ET Listat that combines KUKA industrial robots, a 36-meter linear track, and autonomous mobile robots. The line sorts cut-to-length wood products and directs them to up to 18 stations based on length and quality. Two KUKA robots retrieve finished layers from sorting bins and perform handling operations that include 180-degree rotation around two axes. A third KUKA robot mounted on the 36-meter linear track assembles individual product layers into finished bundles. AMRs then transport the bundles. Siipotec describes the installation as an award-winning solution that improves productivity, consistency, ergonomics, and material flow while reducing waste. The video shows the robots, track, and AMR movement inside the ET Listat facility. No independent throughput measurements or before-and-after production figures have been published outside company statements.
Wood-processing lines often involve long, heavy, and variable-length pieces that are difficult to handle manually. The combination of fixed robots, a long linear track, and mobile robots allows the system to cover a large area without requiring workers to move between stations. The linear-track robot can reach multiple sorting and bundling positions. Servo-controlled guides and positioning systems are used to maintain accuracy. Siipotec specializes in automation for the mechanical wood industry and has previously delivered robotic cells and production lines for Finnish manufacturers. The ET Listat project is presented as a complete material-handling and internal-logistics solution. The company has not released cycle times, uptime percentages, or energy-consumption data. The video illustrates the physical layout and the movement of the robots and AMRs. It does not include quantitative performance metrics.
KUKA industrial robots are widely used for material handling, packaging, and assembly. Mounting one on a 36-meter track extends its working envelope for long products. The AMRs handle the final transport step, removing the need for fixed conveyors across the entire facility. Siipotec integrated the robots, track, vision or sensing systems, and AMR fleet control. The installation is one of several wood-industry projects the integrator has completed. No customer quote or specific award name is given in the publicly available description beyond the general “award-winning” characterization. The video is a customer-success overview rather than a technical deep dive. For manufacturers evaluating similar lines, the relevant questions are the actual throughput gain, the maintenance requirements of the long track, and the reliability of the AMR handoff. Those details are not provided in the promotional material.
ET Listat manufactures building mouldings, profiles, decoration panels, and wooden floors. The company produces large volumes of cut-to-length products that must be sorted, bundled, and moved. The Siipotec system automates the sorting, bundling, and internal transport steps. The 36-meter track robot and the AMR fleet are the two most visible elements in the video. The project demonstrates how industrial robot arms, linear motion, and mobile robots can be combined for variable-length material handling. No data on worker reassignment, injury reduction, or long-term reliability have been released. The video shows the system operating in the factory. Claims of higher productivity and improved ergonomics are company statements. The installation is a practical example of integrated industrial automation rather than a humanoid-robot application.
Siipotec has installed a KUKA-based automation system at ET Listat that uses industrial robots on a 36-meter linear track and AMRs to sort, bundle, and transport wood products. The solution is described as award-winning and is intended to improve productivity, quality, and ergonomics. The video shows the robots and mobile units in operation. No independent performance metrics have been published. The project is a conventional industrial-robot and AMR installation for the wood industry. It demonstrates integrated material handling across a large floor area. Quantitative results remain company-reported. The system is an example of production-line automation rather than humanoid deployment.
Luwu Dynamics has published the hardware, runtime, and training resources for XGO-Duck, a 3D-printable biped adapted from Pollen Robotics’ Microduck. The robot uses an Arduino UNO Q (Qualcomm processor running Linux plus STM32 microcontroller), 15 Feetech 1910 serial servos, a custom expansion board with a QMI8658A IMU, and printed structural parts. The supplied runtime includes walking, get-up, and pick policies that run on the UNO Q. The hardware repository contains STL files, PCB designs, a bill of materials, and an assembly guide. The project is explicitly credited to Pollen Robotics’ Microduck and microduck_rl work. The video introduces the hardware, assembly, on-robot software, and simulation workflow. No commercial production timeline or large-scale user base has been announced. The robot is a maker-oriented open-source platform rather than a finished consumer product.
Microduck is a small duck-shaped biped with 15 degrees of freedom that Pollen Robotics has shown walking and interacting. XGO-Duck retains the body shape, joint layout, and joint order but replaces the electronics and servos. The Arduino UNO Q splits compute: the Linux side runs policy inference and a web interface, while the STM32 handles real-time servo and sensor communication. The expansion board manages power, the servo bus, and the IMU. Luwu Dynamics has released ONNX policy files for walking, recovery, and picking so builders can start without training their own models. A separate training repository allows users to explore reinforcement learning. The video shows the assembly process and the robot executing learned motions. Independent long-duration reliability data from multiple builders have not been published. The project is an open hardware and software adaptation intended for makers who want to experiment with biped locomotion and on-device policies.
Open-source robot platforms lower the barrier for experimenting with learned motion policies. XGO-Duck provides printable parts, a documented electronics stack, and ready-to-run policies. Builders still need to source the Arduino UNO Q, the 15 servos, the expansion board, and batteries, then calibrate the joints. The runtime includes a web interface for control and monitoring. The training repository is separate and requires a suitable GPU machine for new policy development. The video walks through the hardware, assembly steps, and the transition from simulation to the physical robot. No formal safety certification or commercial support package has been announced. The project is suitable for research and hobby use. Claims of reliable walking or picking are limited to the supplied policies under the conditions shown. Broader performance depends on individual builds and calibration.
Pollen Robotics previously demonstrated Microduck and has made related software available. Luwu Dynamics adapted the design for the Arduino UNO Q and Feetech servos and published the full set of files. The expansion board is a custom design that integrates the IMU and servo interfaces. The video shows both the mechanical assembly and the software side, including policy execution. The project does not include a camera or advanced perception in the base configuration. Additional sensors can be added by builders. No large community deployment numbers have been reported. The repositories are public on GitHub. For makers and students, the combination of printable mechanics, dual-chip compute, and learned policies offers a complete starting point. The video is a project overview rather than a controlled benchmark.
Luwu Dynamics has released open-source hardware and software for XGO-Duck, a 3D-printable biped based on Pollen Robotics’ Microduck. The robot uses an Arduino UNO Q, 15 Feetech servos, and a custom expansion board. Supplied policies cover walking, get-up, and pick. The video shows hardware, assembly, and on-robot software. The project is a maker platform rather than a commercial product. No independent large-scale reliability data have been published. Builders can start with the supplied policies or explore the training repository. The adaptation is credited to the original Microduck work. The robot is intended for hands-on experimentation with learned motion.
Tiger Global leads new commitments with participation from Mark Cuban Companies; total capital tied to the proposed SPAC exceeds $50 million.
FORT Robotics announced on October 22 approximately $20 million in additional funding commitments from existing investors. Tiger Global is leading an approximately $10 million financing, with participation from Mark Cuban Companies, expected to close this week. Tiger Global has also committed an additional $10 million to a previously announced common equity PIPE connected to FORT’s proposed business combination with Newbury Street II Acquisition Corp. Together with earlier PIPE commitments, the total capital tied to the transaction now exceeds $50 million. Upon closing, the combined company is expected to be named FORT Robotics Holdings, Inc. and list on Nasdaq under the ticker FROB, subject to regulatory approvals. FORT develops the Trust Layer for Physical AI, a safety platform currently deployed across more than 19,500 units to over 600 customers, including Agility Robotics, DoorDash, Zoox, and Google DeepMind. The video shows the company’s Wireless E-Stop Pro wearable safety device.
The additional capital is intended to expand the team and operating capacity as customer demand grows across warehousing, defense, construction, and other markets adopting autonomous systems. FORT has positioned its products as foundational safety infrastructure that allows robot manufacturers and end users to certify safety and accelerate deployment. The company holds 25 patents and has been backed by Tiger Global since its Series B in 2022. The proposed SPAC combination values the business at roughly $500 million pre-financing, with an enterprise value near $557 million. No new product performance data or customer contract values were released with the funding announcement. The Wireless E-Stop Pro is a SIL 3-certified wearable device with 200-meter range and an IP65 enclosure, designed for operators to stop machines remotely. The video demonstrates that product rather than the funding itself.
Physical AI safety has drawn increasing attention at industry events. Speakers at RoboBusiness in Santa Clara this week repeatedly cited safety as a prerequisite for scaling autonomous systems. FORT’s Trust Layer is one commercial response to that requirement. The company says its solutions are used in warehousing, transportation, manufacturing, construction, agriculture, mining, energy, and defense. The funding expands resources for growth but does not include disclosed revenue figures or order backlogs. The Nasdaq listing, if completed, would make FORT the first publicly traded company focused principally on physical AI safety, according to the company. Regulatory approvals and closing conditions remain outstanding. The video illustrates one of FORT’s mobile safety products in use on industrial equipment.
FORT was founded in 2018 by Samuel Reeves. The company has expanded from hardware-centric safety devices to a broader software and connectivity platform. Recent milestones include an expanded partnership with Agility Robotics and the introduction of Connectivity Aggregation software. The new commitments from Tiger Global and Mark Cuban Companies are incremental to earlier financing. No independent verification of the 19,500-unit deployment figure has been published outside company statements. The Wireless E-Stop Pro video shows the device pairing with machines and providing status feedback. It is relevant as an example of the safety hardware the company sells. The funding announcement is the primary news; the video provides product context.
The proposed listing under the FROB ticker remains subject to regulatory review and other closing conditions. FORT intends to use the capital to support new and expanding customer opportunities. The company has not published updated financial results with the announcement. The Wireless E-Stop Pro is marketed for dense worksite environments where operators need mobile protection. The video demonstrates its range, status display, and rugged enclosure. For observers tracking capital flows into physical AI infrastructure, the $20 million commitment and the path toward a Nasdaq listing are the material developments. Deployment numbers and customer names are company-reported. The transaction has not yet closed.
FORT Robotics has secured approximately $20 million in additional funding commitments led by Tiger Global with participation from Mark Cuban Companies. Total capital connected to its proposed SPAC with Newbury Street II exceeds $50 million. The company expects to list on Nasdaq as FORT Robotics Holdings under the ticker FROB if the combination closes. Its Trust Layer is deployed across more than 19,500 units to over 600 customers. The video shows the Wireless E-Stop Pro safety device. The funding is intended to expand capacity as demand grows. The listing remains subject to approvals. The announcement is a capital and public-market update rather than a product launch.
NVIDIA CEO Jensen Huang delivered the GTC Berlin 2026 keynote on October 21. Announcements included the Agile ONE SN reference humanoid developed with Agile Robots, scheduled for early 2027; RTX Spark Windows laptops with up to 128 GB of memory for local AI agents; the Vera Rubin DSX Pod, a containerized AI factory design that NVIDIA says can deploy in as little as 14 days at a prepared site; and confirmation that Vera Rubin is in full production, with Huang claiming another roughly 30-times performance leap over Blackwell. OpenShell and Sentry security tools for autonomous AI agents were also introduced. The video is a third-party recap that also covers Unitree’s H2-X demonstration. All performance and availability figures are company claims. No independent benchmarks were released with the keynote.
The Agile ONE SN is a 31-DoF reference platform built on NVIDIA Isaac GR00T and Jetson Thor. NVIDIA says it ships preconfigured with compute and software to reduce researcher setup time from weeks to days. Agile Robots is targeting Q1 2027 availability. RTX Spark is a line of Windows PCs with RTX graphics and up to 1 petaflop of local AI performance. Vera Rubin NVL72 systems are liquid-cooled and connect 72 GPUs per rack. The DSX Pod packages these systems in modular containers for faster site deployment. OpenShell is an open-source runtime for isolating and monitoring AI agents. The video attributes every figure to the announcing company. Huang’s keynote also addressed European AI infrastructure and Hyperion vehicle platforms. The humanoid and compute announcements are the portions most relevant to robotics.
Reference platforms are intended to give developers a validated starting point rather than a finished commercial product. The Agile ONE SN is one such system. NVIDIA has not published pricing or production volumes. Vera Rubin’s “full production” status has been stated at multiple events; racks are reported to be running at customers. The 30-times claim is a company comparison under specific workloads. Independent measurements of end-to-end robot performance on the new stack have not been released. The video recap includes the Unitree H2-X high-impact demonstration alongside the GTC announcements. It does not add new technical data. For teams evaluating onboard compute or simulation tools, the Jetson Thor and Isaac GR00T updates are the practical takeaways. Availability timelines remain early 2027 for the reference humanoid and DSX Pods.
NVIDIA has expanded its robotics platform with GR00T models, Isaac tools, and Jetson Thor modules. Multiple companies, including Agile Robots, are building on the stack. The GTC Berlin keynote presented these elements together with data-center and personal-AI hardware. The video is a summary that also covers Unitree’s recent H2-X video. No new customer deployments or quantitative robot task success rates were announced. The reference humanoid is positioned for research and development. RTX Spark targets local agent workloads on Windows. Vera Rubin targets large-scale inference and training. All claims are attributed to NVIDIA or the partner companies. The keynote is a platform update rather than a product launch with immediate availability.
NVIDIA’s GTC Berlin keynote highlighted the Agile ONE SN reference humanoid, RTX Spark laptops, Vera Rubin in full production, and the DSX Pod containerized AI factory design. OpenShell agent security tools were also introduced. The video is a recap that includes Unitree’s H2-X demonstration. All specifications and timelines are company statements. The Agile ONE is scheduled for early 2027. No independent performance data were released. The announcements expand NVIDIA’s robotics and AI infrastructure offerings. Operational results on robots will depend on subsequent integrations. The keynote is a platform and hardware update.
XPENG has released video of its IRON humanoid adjusting mid-interaction during handshakes, fist bumps, and high-fives. When a palm closes into a fist or the high-five position changes, the robot switches hands or modifies its motion without completing a fixed routine first. The company attributes the behavior to an upgraded VLA 2.0 model with stronger temporal understanding and future-behavior prediction, running on-device. XPENG says the robot reassesses the scene approximately every 0.2 seconds and predicts action changes within about six seconds. The demonstration is a controlled interaction test. No independent latency measurements or success rates across varied users have been published. The video shows continuous observation and adjustment rather than a single pre-scripted sequence. IRON is XPENG’s general-purpose humanoid powered by the company’s Physical AI stack.
Real-time motion following requires the robot to update its plan while an action is already under way. Fixed gesture recognition followed by a complete motion is simpler but less flexible when a person changes intention. XPENG’s description of continuous observation and on-device VLA 2.0 inference is consistent with the visual result in the video. The model is also used in the company’s vehicles. Transferring the same foundation to the humanoid is a company claim. The 0.2-second reassessment interval and six-second prediction horizon are XPENG figures. No third-party timing data have been released. The video is useful as a qualitative demonstration of adaptive social interaction. It does not show the robot performing the same behavior in unstructured public settings or under varying lighting and crowd conditions.
IRON features a spine-like structure, bionic muscle layout, and soft skin. The interaction sequence tests upper-body coordination and the ability to switch limbs when the target moves. XPENG has previously shown IRON walking, tracking speakers, and holding multi-language conversations. The current video focuses on physical gesture following. The company notes that the footage is from development and testing and that the final product may differ. No force or contact-safety data for the handshake interactions have been published. For researchers studying human-robot interaction, the relevant questions are the latency of the closed loop, the robustness of the prediction model when intentions change rapidly, and the safety margins during contact. Those details are not included in the promotional clip. The demonstration illustrates on-device temporal reasoning applied to social motion.
VLA 2.0 is XPENG’s vision-language-action model. The company has deployed it in vehicles and is now applying an upgraded version to IRON. The on-device claim means inference occurs on the robot’s compute rather than in the cloud. IRON carries multiple Turing chips. The video does not show the internal compute configuration. Continuous adjustment during a handshake is a limited but visible test of the loop. Broader claims of general social competence would require longer, more varied trials. No such data have been released. The demonstration is consistent with XPENG’s positioning of IRON as a platform that combines physical motion with real-time AI. The video is the primary public evidence of the adaptive interaction behavior.
XPENG has shown its IRON humanoid adjusting in real time during handshakes, fist bumps, and high-fives. The company attributes the behavior to an upgraded on-device VLA 2.0 model with temporal understanding and prediction. The robot is said to reassess the scene every 0.2 seconds. The video demonstrates continuous observation and motion adjustment. No independent metrics have been published. The sequence is a controlled development demonstration. Final product behavior may differ. The clip illustrates adaptive social interaction on the IRON platform.
The child-sized wheeled robot is built for conversation, facial expression, and social interaction in education, healthcare, and hospitality settings.
Mind Children has released new footage of MC1, the social humanoid prototype also known as Codey. The robot is approximately three feet tall, rides on wheels, and is designed for conversation, expressive facial movement, and social engagement rather than industrial labor. The company identifies education, healthcare, and hospitality as potential application areas. Co-founders Chris Kudla and Ben Goertzel have described the robot as a low-cost interface for human connection. Target production price is under $10,000. A second unit named Joy has been built with Korean manufacturing partners. The Seattle prototype can hold eye contact, respond to emotional cues, and carry on autonomous conversations using onboard computing and AI. Physical capabilities remain limited; the robot cannot yet fetch objects or perform complex manipulation. In the video, Codey remains stationary and introduces itself through speech and facial expression.
Social humanoids differ from factory or warehouse platforms in both form and function. MC1 uses a child-sized body, a stylized gray face with servo-driven expressions, and low-torque motors intended to fail safely on contact. Mind Children has tested the robot’s responses to inappropriate prompts and has designed the architecture so the underlying language model can be replaced. Recent updates include integration of SingularityNET’s OmegaClaw agent framework, which the company says allows the robot to remember past interactions and adapt. The prototype has appeared at technology events and has been shown in controlled indoor settings. No large-scale public deployments have been announced. Pilot studies in museums and event spaces are planned for later this year. A second-generation model is targeted for 2027. The video focuses on the robot’s conversational introduction.
Affordability is a central design constraint. Most full-size humanoids cost tens of thousands of dollars. Mind Children argues that a sub-$10,000 price point is necessary for classrooms, care facilities, and hospitality venues. The modular 3D-printed construction of the current prototype is expected to transition to more conventional manufacturing as volumes increase. The company has raised crowdfunding and is backed by SingularityNET. Physical limits are acknowledged: the robot is not intended for heavy lifting or unsupervised outdoor operation. Near-term goals include teaching simple button-pushing and expanding memory for relationship building. The video shows Codey speaking and presenting itself without locomotion. Independent testing of long-term reliability and user acceptance has not been published.
Mind Children was founded in 2023 in the Seattle area. The team includes engineers with backgrounds in automotive, aerospace, and consumer products. Codey’s personality is described as curious and childlike, with the ability to make simple jokes and maintain conversational context. The company has said the robot is aware of its surroundings and can describe scenes in front of it. These capabilities depend on the quality of the language model and the sensor suite. The video shows the robot introducing itself through voice and expression while remaining in place. It does not demonstrate autonomous navigation or multi-day continuous operation. Those remain development targets. For observers tracking social robotics, the low target price and the explicit focus on education and care distinguish the project from industrial humanoid efforts.
The MC1 prototype is still in the laboratory and demonstration stage. Mind Children has stated that commercial units will be hardened for field use. Current limitations include restricted physical dexterity and the need for controlled environments. The company plans pilot deployments in public attractions by the end of 2026 and broader use in healthcare and education thereafter. The video provides a clear view of the robot’s face, speech, and introductory style while it stays stationary. No performance metrics on conversation success rate, battery life, or safety incidents have been released. The project is an early-stage social humanoid aimed at human interaction rather than labor replacement.
Mind Children has shown its MC1 Codey social humanoid prototype. The child-sized wheeled robot is designed for conversation, facial expression, and social engagement in education, healthcare, and hospitality. Target price is under $10,000. Physical capabilities are limited. In the video, Codey introduces itself through speech and expression while remaining stationary. Pilot deployments are planned for later this year. The platform remains a prototype. No large-scale operational data have been published. The project focuses on affordable social robotics rather than industrial tasks.
Unitree has released a promotional video titled “H2-X Kung Fu Legend Guardian.” The clip shows the humanoid performing high-impact martial arts movements, jumping from a platform labeled four meters high, landing, and recovering. It also depicts staged protection and rescue scenes, including intervening with a knife-wielding figure and lifting the front of a car so a dummy can be pulled free. Unitree states the footage is real and has not been sped up. The company lists a maximum endurance of approximately eight hours while standing. No detailed hardware specifications, pricing, or availability for the H2-X have been published. The video is a dynamic capability demonstration rather than a product announcement with technical data. The standard Unitree H2 is approximately 182 cm tall with 31 degrees of freedom; the H2-X relationship to that platform is not specified beyond the name.
High-impact demonstrations test joint strength, whole-body coordination, and impact recovery. The H2-X sequence includes kicks, punches that damage a car door, aerial flips, and a high drop onto mats. The protection and car-lift scenes are staged. Unitree has not published force measurements, success rates across repeated trials, or energy consumption during the stunts. The eight-hour standing endurance figure is a company claim. Dynamic operation under load would reduce that figure. The video has circulated widely and generated discussion about the physical power of current humanoid platforms. It does not address safety systems, autonomous decision-making, or real-world deployment constraints. The company includes a note to use the robot safely and in a friendly manner. The demonstration is visual evidence of dynamic motion capability.
Unitree has previously shown its robots performing parkour, flips, and high-speed locomotion. The H2-X video continues that pattern with higher-impact actions and a guardian narrative. The car-lift sequence requires significant torque at the arms and torso. Whether the motion is fully autonomous or partially teleoperated is not stated. No independent verification of the eight-hour endurance or the authenticity of every frame has been released. For researchers, the relevant questions are the control policies that generate the motions, the actuator limits that allow the impacts, and the recovery behaviors after falls. Those details are not included in the promotional clip. The video is useful as a qualitative illustration of the platform’s dynamic range. It is not a technical datasheet.
Unitree is a Chinese company known for commercial quadruped and humanoid platforms. The H2 series has been marketed for research and industrial use. The H2-X video adds a security-themed presentation. No contracts or deployments for a guardian role have been announced. The demonstration does not show the robot operating unsupervised in public spaces or interacting with real people outside staged scenes. Battery life, compute architecture, and sensor suite for the H2-X remain undisclosed. The video is the primary public evidence of the platform’s high-impact capabilities. Claims of real, unsped footage are company statements. Quantitative performance data have not been provided.
Unitree has released a video of the H2-X performing martial arts, high drops, and staged protection and rescue actions. The company states the footage is real and lists approximately eight hours of standing endurance. No detailed specifications or independent verification have been published. The video is a dynamic capability demonstration. The guardian narrative is staged. The clip shows the physical range of the platform under controlled conditions. Real-world autonomous security use has not been demonstrated. The demonstration is visual evidence of high-impact motion.
UK-based Humanoid has announced an expanded collaboration with NVIDIA to develop a high-performance robotic edge runtime for its next-generation robots. The companies are integrating NVIDIA Jetson Thor, NVIDIA Isaac OS, NVIDIA Holoscan Sensor Bridge, and the Holoscan SDK. Humanoid says the move to Jetson Thor has allowed it to consolidate two onboard computers into a single system while maintaining computing capacity, with potential additional headroom. Unified CPU and GPU memory on Jetson Thor is expected to reduce data movement and latency. Holoscan Sensor Bridge places camera data directly into GPU-accessible memory. Isaac OS provides a GPU-native runtime for coordinating perception, inference, and control. Multi-Gigabit Ethernet supplies up to 100 Gb of bandwidth for sensor and control signals. The company has used NVIDIA Isaac Lab and Isaac Sim since its early days for training and simulation. The announcement was made on October 21. The video is the company’s general platform overview.
Onboard compute is a constraint for humanoid robots that must process high-bandwidth sensor data and run AI models in real time. Moving from two computers to one reduces hardware complexity, power draw, and integration effort. Humanoid states that the new architecture simplifies how different workloads share resources. The collaboration does not include published benchmarks of inference latency, power consumption, or task success rates on the new stack. NVIDIA has released Jetson Thor modules and Isaac tools for general robotics development. Humanoid is one of several companies adopting the platform. The press release quotes CEO Artem Sokolov on the need for significant computing power and real-time integration of sensing, AI, and control. No deployment timeline or robot model name for the next generation is given. The work is framed as foundational architecture rather than a finished product release.
Humanoid positions itself as a UK AI and robotics company focused on commercially scalable and safe humanoid robots. Earlier work has included proofs of concept in industrial settings and the use of NVIDIA simulation tools. The expanded collaboration extends that relationship into the onboard runtime. Holoscan is intended to lower latency between sensors and models. Isaac OS is intended to coordinate multiple robotics workloads on the GPU. These are engineering choices rather than demonstrated performance gains. Independent measurements of the consolidated computer’s effect on robot behavior have not been released. The video shows the company’s robots and facilities but does not specifically demonstrate the new Jetson Thor configuration. The announcement is a technology partnership update. Operational results will depend on subsequent hardware and software integration.
NVIDIA has been expanding its robotics platform with Jetson Thor, Isaac GR00T, and related tools. Multiple European and global robotics companies are building on the stack. Humanoid’s announcement is consistent with that broader trend. The company says the technologies will make the platform easier to develop, test, and scale. No customer deployments or production volumes tied to the new compute architecture have been stated. The October 21 press release is the primary source. The video is relevant as company context but does not contain the technical details of the collaboration. For observers tracking compute choices in humanoid development, the consolidation to a single Jetson Thor system is the concrete engineering claim. Performance data remain unreleased.
Humanoid is expanding its collaboration with NVIDIA to build an onboard edge runtime using Jetson Thor, Isaac OS, Holoscan Sensor Bridge, and related tools. The company says Jetson Thor consolidates two computers into one while maintaining capacity. Unified memory and direct sensor-to-GPU paths are expected to reduce latency. The announcement was made on October 21. No independent benchmarks have been published. The video is a general company overview. The collaboration is an architecture and development partnership. Operational results have not yet been demonstrated. The work is intended to support the company’s next generation of robots.
Three Mazak CNC machines will be installed at REVEL’s Prague headquarters so the company can prototype components and develop robots that tend the machines.
REVEL Robotics has announced a partnership with Mazak that will place three CNC machines at its Prague headquarters. The Mazak team visited the facility to discuss using the machines to manufacture robot components while REVEL develops its humanoid robots to tend those same machines. The company says the arrangement will give its engineers more control over prototyping, testing, and iterating parts in-house. REVEL builds humanoid robots intended to preserve and multiply skilled human work in manufacturing and other sectors facing labor shortages. The Prague site is the company’s European engineering and R&D base. The partnership is presented as an early step toward robots that help produce more robots. No timeline for the machines’ installation or for robot tending capability has been stated. The video is an episode of the company’s Building REVEL series showing the visit and the components under discussion.
Bringing CNC capacity inside the headquarters is a practical manufacturing decision. REVEL currently relies on external suppliers for many parts. Longer lead times and limited customization options have been cited by the company as constraints. Installing Mazak machines is expected to shorten the loop between design and physical test. At the same time, the company is working on the control and perception systems its robots would need to load, unload, and interact with CNC equipment. That dual goal—faster in-house prototyping plus robots that can operate the machines—is the stated ambition of the collaboration. The video shows the Mazak visitors and the Prague workspace. It does not include footage of robots already tending machines. The engineering work to reach that point remains ahead.
REVEL’s approach centers on capturing skilled human motion and judgment, then deploying that capability on humanoid platforms. The company has previously discussed targets of scaling production and has open roles across engineering in Prague. Adding CNC machines is consistent with a strategy of controlling more of the hardware stack. Mazak is a major machine-tool manufacturer with a presence in Central Europe. The partnership gives REVEL access to industrial CNC platforms while giving Mazak a potential future application in robot-assisted machine tending. Neither company has published quantitative milestones for the collaboration. The public evidence is the announcement of the visit and the plan to install the three machines. The video documents the meeting and the current state of the Prague facility.
Machine tending is a known application for industrial robots, but humanoid form factors remain uncommon in that role. Most CNC cells use fixed or mobile industrial arms with custom end effectors and fixturing. A humanoid would need reliable grasping of varied parts, safe interaction with machine doors and controls, and recovery from errors without constant human intervention. REVEL has not claimed those capabilities exist today. The partnership is framed as a development path: manufacture parts with Mazak machines now, and develop the robots that can support that work later. The video is useful as a record of the planning discussion. It does not demonstrate autonomous machine tending. For observers tracking how humanoid companies approach manufacturing, the in-house CNC step is a concrete operational move.
REVEL was founded in 2025 and maintains offices in Palo Alto and Prague. The company has described its robots as tools for skilled work that is difficult to staff. The Mazak collaboration is the latest public update on its manufacturing plans. Three CNC machines are planned for the Prague headquarters. The company intends both to use those machines for prototyping and to develop robots capable of tending them. The video shows the Mazak team’s visit and the components the company expects to produce. Installation timing and robot performance on the machines have not been detailed. The partnership is an early-stage manufacturing and development agreement rather than a completed production system.
REVEL Robotics is partnering with Mazak to install three CNC machines at its Prague headquarters. The machines will be used to manufacture robot components in-house. The company is also developing its humanoid robots to tend CNC equipment. The video records a visit by the Mazak team and outlines the current plans. No robots are shown operating machines. The collaboration is a manufacturing and R&D step. Further engineering is required before the robots can support the machines. The announcement is the public status of the effort.
UniX AI has released video of its Panther wheeled dual-arm robot performing facility patrol tasks. The robot is shown moving through low-light outdoor areas, office floors, and parking garages while using multimodal perception, adaptive manipulation, and anomaly detection. Panther is powered by the company’s UniTac, UniCortex, and UniFlex systems. UniX AI describes the platform as capable of 24/7 autonomous patrols in unstructured environments. The robot features mass-produced 8-DoF bionic arms, adaptive grippers, and an omnidirectional four-wheel steering and drive chassis. Earlier this year the company announced real-home deployments of Panther for household tasks. The facility-patrol video extends the same platform to security and inspection scenarios. No independent verification of continuous unsupervised operation has been published. The clip is a company demonstration of the robot in mixed indoor and outdoor settings.
Facility patrol requires navigation in spaces that change, detection of anomalies, and occasional physical interaction with equipment or barriers. UniX AI’s materials list fire-equipment inspection, route planning, and multi-floor coverage among the intended uses. The video shows the robot moving and performing inspection-style actions. It does not include long-duration logs, false-positive rates, or comparisons with human patrols. The company has previously claimed monthly production volumes above 100 units for its wheeled platforms and has positioned Panther for commercial service, home, and industrial roles. The patrol application is one of several the company markets. The video is relevant to that claim. Performance under real security contracts remains unstated in the public materials.
Wheeled dual-arm robots have advantages in indoor and mixed environments where stairs are limited. The omnidirectional chassis and vertical reach of the upper body allow Panther to access floor-level and elevated objects without repositioning the base for every task. UniX AI’s stack separates perception and manipulation (UniTac/UniTouch), long-horizon planning (UniCortex), and cross-scenario generalization (UniFlex). The company says these systems support the patrol behaviors. The video is the latest visual evidence. It does not replace quantitative testing of detection reliability or recovery from unexpected obstacles. For facility operators evaluating robotic patrol, the relevant questions are battery life, weather sealing, and integration with existing security systems. Those details are not fully specified in the current demonstration.
UniX AI is a Suzhou-based company founded in 2024. It has raised funding and begun deliveries of wheeled humanoid platforms. Panther is its third-generation full-size wheeled dual-arm robot. The facility-patrol video shows the robot in environments that include low light and mixed surfaces. The company presents the system as ready for 24/7 autonomous use. The evidence is the demonstration footage and the technical stack description. Independent long-term operational data have not been released. The video illustrates the platform’s mobility and inspection actions in the shown settings. Broader claims of continuous unsupervised security coverage remain company statements.
UniX AI has shown its Panther robot performing facility patrol in indoor and outdoor environments. The platform uses UniTac, UniCortex, and UniFlex and features 8-DoF arms on a wheeled chassis. The video demonstrates navigation, perception, and inspection-style tasks. No independent metrics of continuous autonomous operation have been published. The demonstration is consistent with the company’s security and inspection positioning. Real-world contract performance has not been detailed. The clip is a company demonstration of the patrol capability.
Mission Canvas is an open framework that lets developers define map-based, long-horizon robot tasks by combining LiDAR navigation, Behavior Trees, and Vision-Language-Action models. Users create a map, place waypoints, attach a Behavior Tree to each destination, and set the order of execution. Navigation moves the robot between waypoints. Behavior Trees organize the actions at each stop. VLA models supply adaptable manipulation where rule-based steps are insufficient. The framework is presented as a tool for experimentation and research rather than a finished commercial product. Code, documentation, and tutorial videos are available. The system builds on earlier Action Canvas work that defined single-location tasks. Mission Canvas extends that approach across multiple locations. The video demonstrates the workflow of mapping a space, designing missions, and watching the robot execute the sequence.
Long-horizon tasks require the robot to move, act, recover from local failures, and continue. Pure VLA policies can handle flexible manipulation but often lack reliable multi-location sequencing and safety checks. Pure rule-based systems are predictable but brittle when the environment changes. Mission Canvas places both under a Behavior Tree structure so that navigation, deterministic actions, and learned policies can be mixed at each waypoint. The developer can add new capabilities, such as pedestrian detection, by extending the tree. The video shows the interface and a robot carrying out a multi-location sequence. It does not include large-scale reliability statistics or comparisons against other orchestration tools. The value claimed is the ability to compose existing skills into repeatable multi-area missions without rewriting low-level code for every new workflow.
Behavior Trees are a standard way to structure robot tasks because they support sequencing, fallbacks, and parallel actions in a way that is easier to inspect than large neural policies. Adding VLA inference as a leaf node lets the tree call a learned policy when the situation requires adaptability and fall back to rule-based steps when precision or safety is required. Mission Canvas implements that pattern on top of LiDAR-based navigation. The open-source release includes the code needed to reproduce the workflow. Researchers can modify the trees, swap VLA models, or add new perception modules. The video is a demonstration of the current interface and execution loop. It does not claim that the framework solves general long-horizon autonomy. It shows one practical way to connect navigation, rules, and learned actions on a mapped space.
The framework is associated with ROBOTIS development tools and has been discussed in the Open Robotics community. Action Canvas handled single-workstation tasks. Mission Canvas adds the spatial layer. Both are positioned for developers who already have robot skills and want a way to deploy them across a building or workspace. The video walks through map creation, waypoint placement, Behavior Tree design, and execution. No production deployment numbers or customer case studies are attached to the tool. It remains a research and development framework. For teams building mobile manipulation systems, the open code and the clear separation between navigation, rules, and VLA are the practical contributions. The demonstration illustrates the intended workflow.
Mission Canvas is an open framework for map-based, long-horizon robot tasks. It combines LiDAR navigation, Behavior Trees, and VLA models so developers can define multi-location missions. Users place waypoints, attach task trees, and run the sequence. The video shows the mapping, design, and execution steps. Code and documentation are available. The tool is intended for research and experimentation. No large-scale reliability data have been published. The framework is a composition layer for existing robot capabilities rather than a complete autonomy solution.
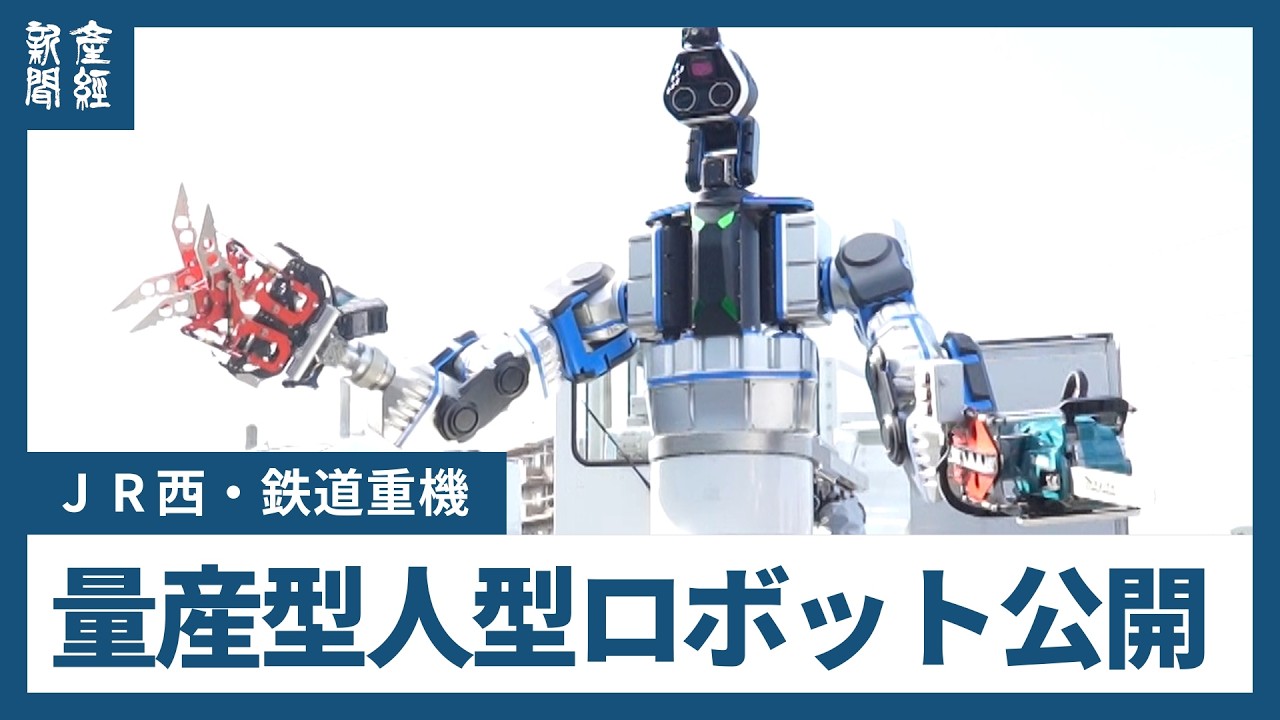
Single-arm heavy lifter and improved humanoid for overhead lines and tree cutting.
Read full story →West Japan Railway (JR West) has shown two new multi-function railway heavy machines developed with Jinki Ittai and Nippon Signal. The machines are meant to cut labor demand and reduce fall and electrocution risks on overhead-line and trackside work. A press demonstration in Suita, Osaka, showed the units in simulated tasks.
The single-arm heavy robot mounts on an aerial work platform and can grip up to 120 kg. It starts use in October in the Kinki region, assisting with heavy fittings on catenary supports so fewer workers climb. The production-type humanoid is a lighter, smaller update of the 2024 ZIZAI unit (roughly half the weight at about 300 kg, boom extended from 12 m to 15 m). It targets tree clearing along lines and is scheduled from November, mainly in the Chugoku region. JR West aims for roughly 30 percent fewer people on the jobs while keeping cycle times similar to manual work.
Railway maintenance in Japan faces chronic shortages and high accident risk on elevated lines. Putting robots on the boom and the platform is a practical response rather than a pure demo. The next measure is whether the claimed 30 percent reduction holds on revenue track.
Watch JR West’s press showing of the new machines.
Open the video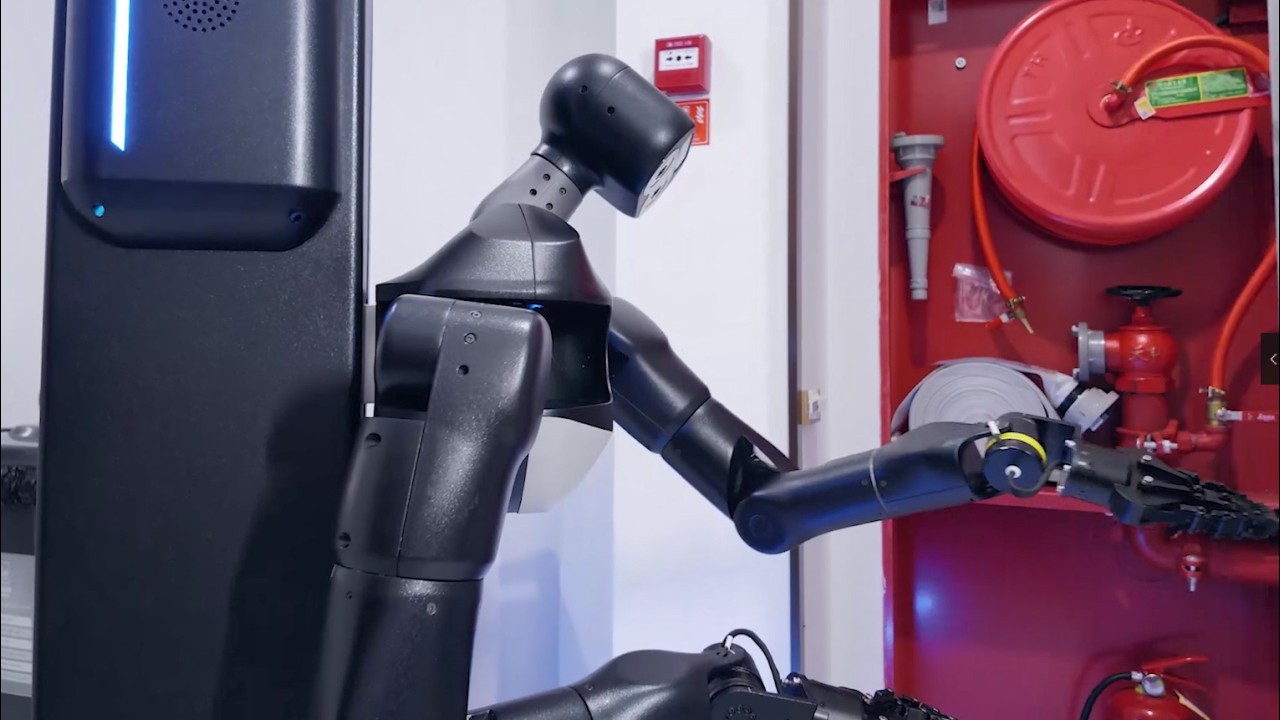
Multimodal perception and adaptive manipulation for 24/7 unstructured sites.
Read full story →UniX AI’s video presents the Panther as a facility patrol robot for unstructured environments where fixed cameras and scripted automation fall short. Powered by the company’s UniTac, UniCortex, and UniFlex stack, it is shown handling low-light outdoor areas, office floors, and parking garages with multimodal perception, adaptive manipulation, and real-time anomaly detection. The pitch is continuous inspect-detect-respond-report cycles.
Panther is a wheeled dual-arm humanoid platform (roughly 1.6–1.75 m, 34 DoF, omnidirectional chassis, dual 8-DoF arms). The company has previously highlighted home and commercial service uses; this clip focuses on security-style patrol in variable lighting and layouts. No independent long-duration patrol metrics or false-positive rates are published in the video. The claim is that the combination of sensing and manipulation lets it act in places traditional security robots cannot.
Facility security still relies heavily on fixed sensors and human rounds. A mobile platform that can both see and physically interact is a different product category. Whether Panther’s patrol mode is reliable outside marketing clips is the open question.
Watch the UniX AI Panther patrol video.
Open the video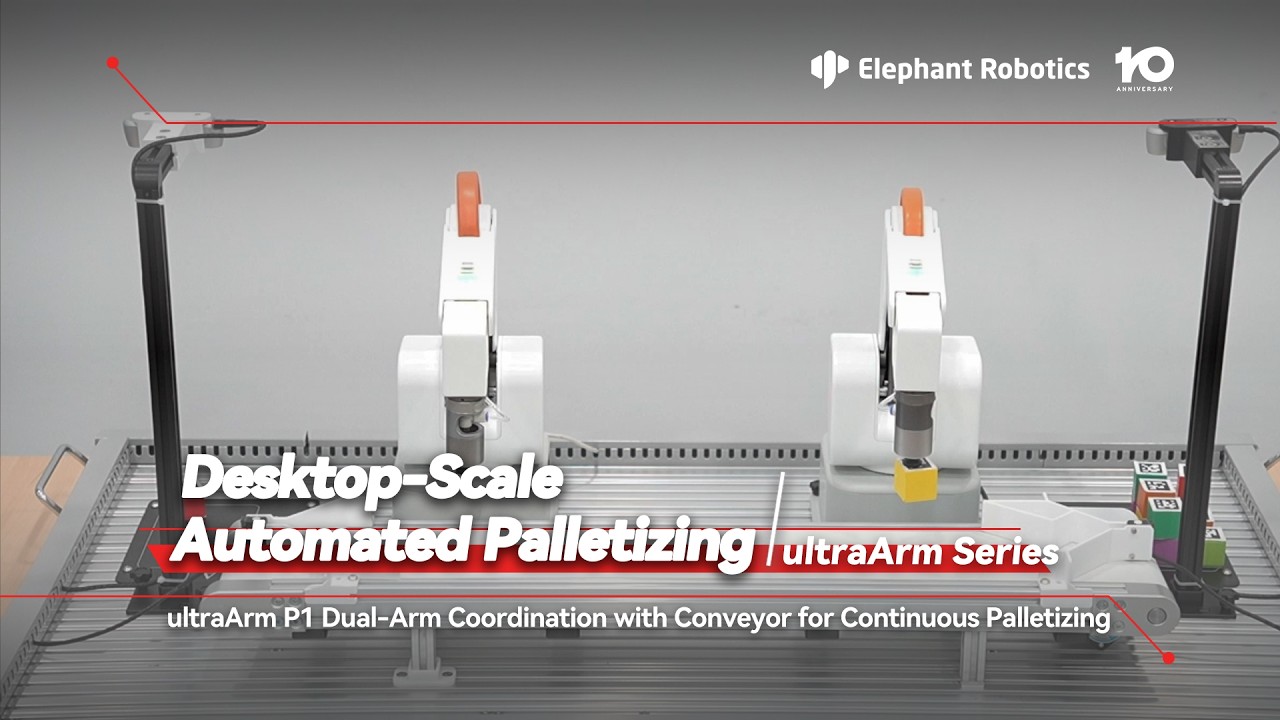
Dual-arm depalletizing, 3D vision picking, and long-run integration practice.
Read full story →Elephant Robotics’ video demonstrates the ultraArm P1 Smart Industrial Conveyor Belt Educational Kit. The system pairs compact 4-DoF arms with a conveyor, 3D vision, and sensors so students can practice a full industrial loop: depalletizing, conveying, and palletizing in both directions, plus vision-guided picking with hand-eye calibration and coordinate transforms.
The kit is aimed at schools, research labs, and training programs rather than production floors. Specs for the arm include roughly 360 mm reach, 650 g payload, and ±0.1 mm repeatability. The video highlights coordinated dual-arm operation, system integration, and runs lasting more than 15 hours to check stability of vision, motion, and multi-device coordination. It is a teaching tool that mirrors real automation sequences without the cost or scale of factory cells.
Automation talent is scarce. Compact, open kits that let students wire a complete pick-convey-place cell shorten the gap between textbook kinematics and a running line. The video is a product demonstration of that teaching loop.
Watch the ultraArm P1 educational kit in action.
Open the video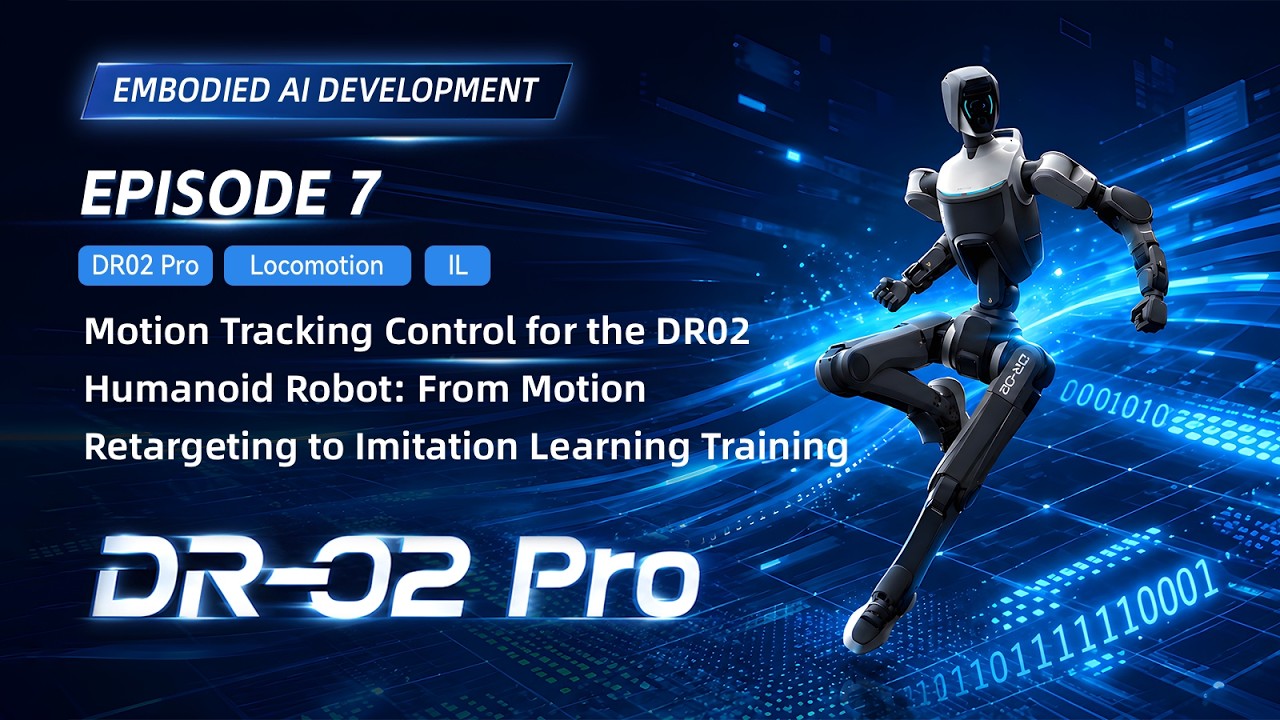
Full pipeline from motion retargeting to tracking policy and robot deployment.
Read full story →Deep Robotics’ tutorial video walks through the complete imitation-learning pipeline for the DR02 Pro humanoid. It covers motion retargeting, training of motion-tracking policies, code structure, and deployment of the trained model on the real robot. The goal is a reproducible path from source motion to on-robot execution using the company’s open-source repositories.
The workflow matches the public GitHub structure: retarget a human motion onto the DR02, prepare the tracking data, train a Mimic-style policy, export ONNX, and load it into the SDK for simulation then hardware. The video explains the basics of retargeting, key implementation details, and how to switch the trained model into the state machine. It is a developer tutorial, not a finished product skill pack; success still depends on the quality of the source motion and the training run.
Imitation learning is one of the faster ways to give humanoids new whole-body skills. An open, end-to-end tutorial for a specific robot lowers the barrier for labs and developers who already have DR02 hardware. The video shows the method; results still depend on data and compute.
Watch the DR02 Pro imitation-learning tutorial.
Open the video
11 DoF, 350 g, 0.5 s open/close, built for small humanoids and drop-tested.
Read full story →Agilink’s OmniHand 3 Lite is a compact dexterous hand sized for small and half-scale humanoids, mobile manipulators, and compact service robots. Dimensions are listed as 140 × 71 × 32.5 mm and weight at or under 350 g—roughly mouse-sized. It offers 11 degrees of freedom, a typical 0.5-second open/close, and is shown performing fist bumps, handshakes, thumbs-up, and heart gestures.
The hand is designed to survive a 1 m drop on all six sides without loss of function. Product pages describe a metal frame with silicone overmold, 4 active + 7 passive DoF so fingers conform to objects, and an open developer toolkit (optional wrist camera). Stable grasp is rated around 1 kg. It addresses the common problem that full-size dexterous hands exceed the wrist payload and volume of smaller platforms, forcing teams to use simple grippers.
Most attention goes to full-size hands for large humanoids. A production-oriented compact hand that still does multi-finger gestures and grasps expands the platforms that can leave pure two-finger grippers behind. The video shows the gestures and form factor; independent payload and cycle tests are not in the clip.
Watch the OmniHand 3 Lite demonstration.
Open the videoRP1 is an open-source bipedal humanoid with mechanical designs, actuators, firmware, and control tools released for researchers and developers.
RoboParty has released RP1, also called ROBOTO 01, as a full-stack open-source bipedal humanoid platform. The company unveiled the robot at IROS 2026 in late September and has since published mechanical CAD, bill of materials, assembly documentation, actuator designs, firmware, low-level drivers, simulation models, and SDKs. RP1 builds on ROBOTO ORIGIN (RPO), which RoboParty open-sourced in January 2026 and which has accumulated more than 2,500 GitHub stars. The company describes RP1 as a high-performance platform for researchers, educators, and embodied AI teams who want to modify hardware, train policies, and deploy on real robots. Peak joint torque is listed at up to 160 N·m from in-house ROMOMO actuator modules. Configurations include 24-DoF and 30-DoF versions. The face-down recovery sequence in the slowed video is one of the motion capabilities the company has shown.
RoboParty states that full-stack open source means more than mechanical files. The planned releases cover motion-control systems, simulation environments, training tools, and the PartyOS development foundation. Developers can inspect and modify layers from mechanical structure and actuator response through control policies. The company says RP1 has demonstrated continuous walking, recovery from disturbances, getting back up after a fall, and human motion tracking. The open toolchain is intended to support iteration across models, control, and hardware. Pricing has not been disclosed in the announcements. A mass-production program and further open-source details are planned for later in the fourth quarter. The developer community is described as more than 5,000 participants.
Open-source humanoid platforms remain uncommon at the full-stack level. Most commercial humanoids keep hardware designs and low-level control closed. RoboParty’s approach starts from the earlier RPO project, which released mechanical and electrical designs, and extends that model to a higher-performance platform with stronger actuators and a more complete software stack. The recovery demonstration shows the robot starting face-down and returning to a standing position without hands attached, so the body and lower-limb motion are visible. That sequence is a practical test of balance and whole-body control after a fall. The company presents it as one capability of the open platform rather than a finished product claim.
Researchers who want to train locomotion or manipulation policies need a robot they can modify and a simulation that matches the hardware. RoboParty’s releases of URDF, MJCF, and actuator details are intended to support that workflow. The 160 N·m peak torque figure is higher than many small research humanoids. Whether the platform reaches the reliability needed for continuous lab use will depend on the quality of the open-source documentation and the number of community builds that succeed. The IROS debut and the subsequent GitHub releases are the public evidence. The recovery video is a visual example of one motion the control stack can produce.
RoboParty was founded in 2025 and has focused on open-source humanoid development from the start. The team includes members from Tsinghua, Peking University, Stanford, Carnegie Mellon, and other institutions. The company positions RP1 as a shared foundation rather than a closed product. The open-source roadmap includes progressive release of additional software and hardware details. For labs that want to study fall recovery, sim-to-real transfer, or whole-body control without building a robot from scratch, the platform is one of the more complete open options currently available. The video shows the recovery motion; the GitHub repositories contain the designs and tools.
RoboParty has opened RP1 (ROBOTO 01) as a full-stack open-source humanoid platform. Mechanical designs, actuators, firmware, simulation models, and control tools are available. The robot has shown fall recovery, walking, and disturbance rejection. It builds on the earlier ROBOTO ORIGIN project. The slowed recovery video illustrates one of the motion capabilities. The platform is intended for researchers and developers who want to modify and extend a real humanoid rather than treat it as a black box. Further open-source releases and a production program are planned for later in the year.
Linkerbot has shown its L30 tendon-driven dexterous hand playing a rhythm game at high speed. The hand is a flagship model with a tendon-driven architecture that moves actuators out of the fingers, reducing distal mass. Published specifications list 17 active degrees of freedom plus passive joints, for a total around 21 joints, with fingertip force sensors, repeatability of ±0.20 mm, and joint speeds exceeding 400°/s on core motions. The hand weighs approximately 1.4 kg. Control is over CAN FD. The rhythm-game demonstration shows rapid, coordinated finger movements timed to on-screen prompts. Linkerbot has previously shown the L30 performing fine-motor tasks such as screw tightening and object manipulation. The game clip is a speed and coordination demonstration rather than a new product claim.
Tendon-driven hands can achieve higher finger speeds than designs that place motors in the fingers because the moving mass is lower. The L30 is marketed for research, industrial assembly, and tasks that require human-like dexterity. Company materials list fingertip forces in the 3.5–4 N range for individual fingers and higher grasp forces with multiple fingers. The rhythm-game video is one of several high-speed clips Linkerbot has released. It does not include independent timing measurements or a comparison against human players under controlled conditions. The visual result is a hand that keeps up with rapid note sequences. Whether the same control precision holds for longer, more variable tasks depends on the software and sensing used with the hand.
Dexterous hands remain a bottleneck for many humanoid and manipulation systems. A hand that can move quickly and return to precise positions is useful for assembly, tool use, and research into high-frequency control. Linkerbot’s L30 is one of several tendon-driven options available to labs and integrators. The rhythm-game demonstration is a clear visual of speed. It does not replace quantitative benchmarks on grasp success, force control, or durability under continuous industrial use. The hand is sold as a modular end effector that can be mounted on robot arms or humanoid platforms. The video shows the L30 in a controlled entertainment-style task.
Linkerbot is a Chinese company focused on dexterous hands. The L30 is positioned as its highest-performance tendon-driven model. Public specifications and demonstration videos are the main evidence available. The rhythm-game clip has circulated as an example of the hand’s speed. For researchers evaluating end effectors, the relevant questions are repeatability under load, thermal performance during continuous high-speed motion, and integration effort with existing controllers. Those details are not fully answered by a short game video. The demonstration is useful as a qualitative illustration of the platform’s response time.
Linkerbot’s L30 hand is shown playing a rhythm game at high speed. The hand uses a tendon-driven design with approximately 17 active degrees of freedom, fingertip sensing, and joint speeds above 400°/s. The video is a coordination and speed demonstration. The L30 is a commercial dexterous hand for research and industrial use. No independent performance metrics from the game sequence have been published. The clip illustrates the hand’s rapid finger control on a timed task.
NEURA Robotics has published further explanation of Neuron AI, the multimodal foundation model it introduced on October 14. The model uses a Perception-Language-Action architecture that combines 3D vision, tactile and force signals, audio, robot state, and language into a shared representation updated over time, with a memory layer for object permanence and causality. CEO David Reger and Business Unit Head Dr. Jens Buchner describe the approach in a new video. The company says vision alone is insufficient for many physical tasks; touch and sound confirm contact events that cameras miss. Neuron AI is trained on data from robots in NEURA Gyms, simulation, and human demonstrations in sensor-equipped suits. It runs across five NEURA robot embodiments and their grippers and hands. Customers can fine-tune skills via Neuraverse and deploy them to fleets. Inference is local. An 11-minute autonomous laundry sequence on the 4NE1 humanoid is scheduled for NVIDIA GTC Berlin.
The memory component is presented as necessary for physical action. A robot must remember that an object still exists after it leaves the camera frame and must track the consequences of its own prior actions. NEURA says the architecture was adapted specifically for these memory tasks. Training draws on three pillars: real robot data collected in the company’s gyms and environments, simulation that varies scenarios, and human motion captured with sensor suits. After base training across the five embodiments, the model is fine-tuned on a specific robot for individual skills. Time-to-Skill is the metric the company uses to measure how quickly a new task can be learned and performed reliably. No independent benchmarks comparing Neuron AI to other foundation models have been released. The laundry demonstration will be the first extended public test on hardware.
Multisensory fusion and memory address known limitations of vision-only models in unstructured settings. Tasks such as confirming a connector is seated, judging a weld seam by sound, or continuing a sequence after an object is occluded require information beyond the current camera frame. NEURA’s claim is that Neuron AI incorporates those signals by design. The evidence so far is the architectural description, the training sources, and the scheduled demonstration. The video with Reger and Buchner walks through the same points. Whether the model generalizes to customer environments and reduces time-to-skill as claimed will be tested when customers begin fine-tuning and when the laundry sequence runs in public. Until then, the model is a company system with a clear technical thesis.
NEURA has positioned Neuron AI as the intelligence layer across its robot family, including multiple generations of the 4NE1 humanoid and other bimanual platforms. The Neuraverse platform is the delivery mechanism for fine-tuned skills. The company has said it will scale NEURA Gyms globally to increase data and reduce training time for new skills. The October 14 announcement and the subsequent explanatory video are the public materials. The model is developed and trained in Metzingen, Germany. For potential customers, the open questions are the data requirements for fine-tuning, the reliability of transferred skills, and the cost of local inference on the robot. Those details are not fully specified in the current materials. The laundry task is the next scheduled public data point.
NEURA Robotics is providing additional detail on Neuron AI, its Perception-Language-Action foundation model. The model fuses 3D vision, touch, audio, robot state, and language with a memory layer, and runs across five embodiments. It is trained on robot, simulation, and human demonstration data. Customers fine-tune via Neuraverse. An 11-minute autonomous laundry sequence is planned for NVIDIA GTC Berlin. The new video explains the architecture and training approach. No independent performance numbers have been published. The model remains a company announcement with a scheduled hardware demonstration.
The company’s humanoid is being trialled on streets in the West Lake District for navigation, obstacle avoidance, violation reminders, and multilingual pedestrian interaction.
DEEP Robotics has been testing its DR02 humanoid robot on the streets of Hangzhou’s West Lake (Xihu) District. The company describes the work as real-world testing across urban scenarios, including autonomous navigation, dynamic obstacle avoidance, identification of traffic violations, voice and gesture alerts, and interaction with pedestrians in multiple languages. Early October trials took place at busy intersections such as Zheda Road and West Wenyi Road in Lingyin Subdistrict, and at sites including Xixi National Wetland Park. The robot is shown directing traffic, reminding riders to wear helmets or stay behind stop lines, announcing lights, and answering visitor questions. DEEP Robotics presents the tests as exploring support for smarter urban mobility rather than routine deployment.
The DR02 carries an IP66 rating for dust and water protection. The company used rainy conditions during the National Day holiday period to test outdoor operation. In company materials and video captions, the robot is described as supporting traffic officers with roadside patrol and monitoring, including in heavy rain. It can identify behaviours such as e-bike riders without helmets, overloaded bikes, pedestrians crossing lines, and vehicles stopping beyond lines, then issue spoken or gestured reminders. Enforcement decisions remain with human officers; the robot does not issue tickets or detain people. Multilingual voice interaction is tested for tourist guidance on routes and attractions. The number of robots deployed, exact operating hours, and degree of remote supervision have not been fully detailed in public releases.
Hangzhou has previously deployed traffic-management robots around the West Lake area. A separate squad of units began operations earlier in 2026 and has been used for direction, violation reminders, and public consultation. DEEP Robotics’ DR02 trials are a company field test of its own humanoid platform in similar environments. The video shows the robot navigating intersections, avoiding people and vehicles, and interacting with pedestrians. Company engineers have described the intended role as reducing repetitive advisory work so human staff can focus on emergencies and enforcement. Data from the trials is intended to refine the robot for additional public-service applications. No timeline for wider deployment has been announced.
Outdoor humanoid testing in rain, crowds, and moving traffic is a higher bar than controlled indoor demos. Navigation, obstacle avoidance, and reliable voice interaction under variable lighting and weather are the practical challenges. DEEP Robotics’ materials emphasise the IP66 rating and the ability to continue duty in wet conditions. The public evidence is the video and the company description of the early October tests. Independent measurements of uptime, accuracy of violation detection, or success rate of pedestrian interactions have not been published. The trials are framed as learning on real streets rather than a finished product for continuous unsupervised operation.
DEEP Robotics is a Hangzhou-based company known for legged robots used in inspection, rescue, and industrial settings. The DR02 humanoid trials in Xihu District are an expansion into public urban scenarios. The company says the work explores what humanoid robots can do from the lab to the streets. The video documents navigation, alerts, and interaction. The tests do not claim that the robot has replaced traffic officers or that it operates without oversight. They show a company evaluating its platform for potential support roles in traffic management and visitor guidance under real conditions.
DEEP Robotics is testing its DR02 humanoid in Hangzhou’s West Lake District for traffic support and pedestrian interaction. The robot is shown navigating, avoiding obstacles, issuing voice and gesture reminders, and answering questions in multiple languages. Trials occurred in early October at intersections and tourist sites, including in rain. The company presents the work as real-world testing for potential urban mobility support, not as a routine deployment. The video matches the described tasks. Broader operational data and any path to sustained use remain with the company and local authorities.
AheadForm is presenting its Elf-Xuan 2.0 humanoid at the World of Warcraft Infinite Party — Dalaran on Earth event in Shanghai. The company says it collaborated with World of Warcraft to give the robot a Skyborne-inspired appearance drawn from the new race in World of Warcraft: Forever. Elf-Xuan 2.0 features expressive facial movements, natural gaze, and coordinated body motion. The event runs October 16–18, 2026 at the National Exhibition and Convention Center (Hall 1.2H). AheadForm describes the robot as blurring the boundary between virtual characters and physical reality. The video shows the Skyborne-styled unit. The appearance is a promotional collaboration for the convention, not a claim of new general-purpose capabilities.
Elf-Xuan 2.0 is AheadForm’s lifelike bionic humanoid platform. The company has previously shown versions focused on facial expression and upper-body movement. Founder Yuhang Hu has described the work as bringing characters from games and virtual worlds into physical form for interaction and entertainment. The Shanghai event is a Blizzard and NetEase production marking 21 years of World of Warcraft in China, with a life-sized Dalaran recreation. AheadForm’s presence is a brand and character collaboration at that event. The robot is not described as performing autonomous tasks beyond the expressive demonstration. Specs, degrees of freedom, and price for Elf-Xuan 2.0 have been reported in secondary sources in broad ranges; the company materials for this event focus on the visual and interactive presentation.
Bionic humanoids designed for expressive interaction are a distinct category from industrial or warehouse platforms. AheadForm’s approach emphasises realistic faces, gaze, and motion so the robot can occupy entertainment and fan-event roles. The Skyborne collaboration places that capability inside a major game-convention setting. Attendees can meet the robot in person during the three-day event. The video is the company’s promotional clip for the appearance. No independent technical evaluation of the robot’s autonomy, reliability, or interaction quality at the event has been published. The demonstration is the physical embodiment of a virtual character for the duration of the show.
AheadForm is a Shanghai-based company focused on realistic humanoid heads and bodies for emotional expression and interaction. Its Elf-Xuan series has been shown at previous events. The World of Warcraft tie-in is a marketing collaboration that places the robot in a high-visibility fan setting. The company states that characters from games and films no longer have to exist only behind screens. The practical outcome is a styled humanoid present at the Shanghai convention. Whether the same platform moves into other commercial entertainment or interactive roles depends on further development and customer interest beyond this event.
AheadForm is displaying Elf-Xuan 2.0 with a Skyborne-inspired appearance at the World of Warcraft Infinite Party in Shanghai from October 16–18, 2026. The robot features expressive facial movements and coordinated motion. The collaboration is promotional for the event. The video shows the unit. It is a character embodiment demonstration rather than a new technical capability claim. The event is the public venue; the robot is the physical presence AheadForm is bringing to it.
Kinova has released a demonstration of two Gen3 robotic arms performing coordinated manipulation. The Gen3 is a lightweight, modular arm platform developed for research and professional applications. It supports grasping, vision-based manipulation, assembly, and robotics development work. Dual-arm setups allow researchers to explore coordinated movements and tasks that require two arms. The video shows the arms working together on a manipulation sequence. Kinova, based in Quebec, Canada, designs the Gen3 series for labs and industrial settings where portability, safety around people, and open software interfaces matter. The Gen3 is available in 6-DoF and 7-DoF configurations with options for integrated vision and various end effectors.
The Gen3 platform is widely used in research because of its ROS support, high-level and low-level control, and modular design. Dual-arm configurations appear in academic and industrial projects for tasks such as assembly, teleoperation, and collaborative manipulation. One documented use is an augmented-reality teleoperation system in which two Gen3 arms are controlled remotely inside a containment cell. The arms’ compact size and 7 degrees of freedom help with collision avoidance in constrained spaces. Kinova’s Kortex software and open APIs support custom development. The video is a company demonstration of dual-arm capability rather than a new product announcement. It illustrates coordinated motion that single-arm systems cannot perform without additional fixturing or sequencing.
Lightweight collaborative arms are common in research labs because they can be moved between experiments and operated near people with lower risk than large industrial robots. Dual-arm setups add the ability to hold one object while manipulating another, or to perform bimanual tasks such as folding, assembly, or tool use. The Gen3’s modular joints and optional vision modules make it suitable for vision-guided grasping and insertion tasks. Researchers use the platform with MoveIt, Gazebo, and custom controllers. The demonstration shows the arms executing a sequence; it does not claim autonomous high-level planning or long-horizon reliability. Performance depends on the software and sensing the user adds.
Kinova has positioned the Gen3 for education, research, and light industrial applications. Dual-arm work expands the range of experiments possible on the same hardware. Labs that already own single Gen3 arms can add a second unit for coordination studies. The video is a visual example of that configuration in action. No new specifications or software releases are announced. The interest for humanoid and manipulation research is the availability of a documented, commercially supported dual-arm setup that can be used for algorithm development and teleoperation studies. The arms themselves remain the same Gen3 platform; the demonstration is the coordinated use of two of them.
Kinova is showing two Gen3 robotic arms performing a coordinated manipulation task. The Gen3 is a modular research and professional arm used for grasping, vision-based work, and assembly studies. Dual-arm setups support exploration of bimanual tasks. The video is a company demonstration of the configuration. It does not introduce new hardware. Researchers use the platform for teleoperation, assembly, and algorithm development. The demonstration illustrates coordinated motion available on existing Gen3 hardware.
From detection to basket, perception and manipulation run without a human in the loop.
Read full story →From identifying the fruit to placing it into the basket, the robot in this clip completes the full apple-picking workflow autonomously in a real orchard. The system combines visual perception with robotic manipulation to detect, locate, grasp, and collect apples in an unstructured outdoor environment. It is not a lab table with a single fruit on a clean background. Branches, leaves, variable light, and natural clustering are all present.
The point of the demonstration is the closed loop rather than a single grasp. Perception has to find ripe fruit among foliage, estimate a reachable pose, drive the arm without damaging the apple or the tree, detach it cleanly, and deposit it in a basket. That sequence is harder than moving an arm through a scripted path. Outdoor lighting changes, fruit can be partially occluded, and the robot must decide when a grasp is good enough to proceed.
Orchard labor is seasonal, expensive, and hard to staff. A system that can finish the pick-to-basket loop outdoors is closer to a useful tool than a motion demo. The clip does not publish success rates or cycle times. It does show that perception and manipulation can be chained into one autonomous harvest step.
Watch the autonomous apple-picking demonstration.
Open the video
Rapid choreography, live status, and safety braking for groups of robots.
Read full story →Unitree has released a short introducing UniUni, its intelligent swarm control system. The video, posted October 16, shows the software enabling rapid, intelligent choreography of swarm robot movements and formations. It also covers real-time device status monitoring and safety braking. The closing line asks how many robots a viewer would like to see perform together.
This sits in a line of Unitree cluster work. Earlier in 2026 the company showed coordinated G1 performances that it described as relying on onboard sensing rather than external motion-capture for every move. UniUni is the named system for orchestrating those groups—planning formations, watching status, and stopping units when needed. The clip is a product introduction, not a published specification sheet with latency numbers or maximum fleet size.
Single-robot demos are common. Coordinating many units without constant remote puppeteering is harder. UniUni is Unitree’s public name for that control layer. Whether it scales beyond stage work is the next question the company will have to answer with numbers.
Watch Unitree’s UniUni swarm introduction.
Open the official video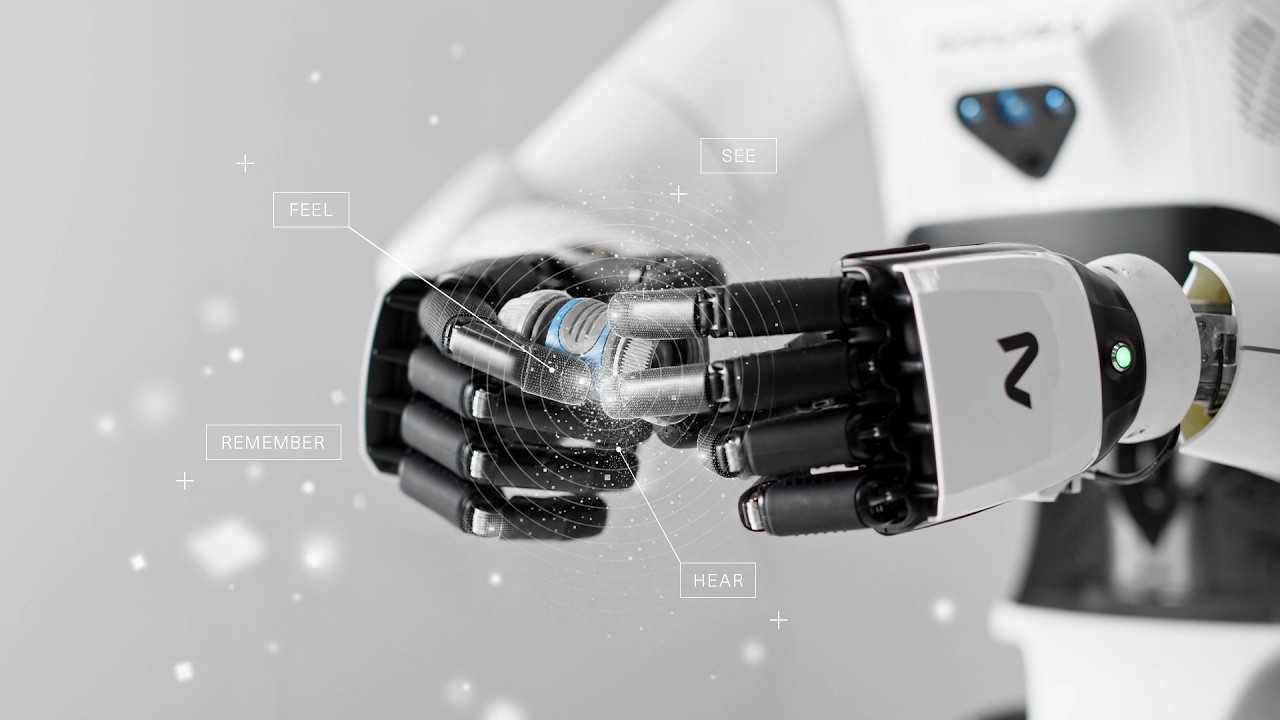
A PLA model that adds touch, sound, and memory to 3D vision and language.
Read full story →NEURA Robotics announced Neuron AI on October 14 as its in-house multimodal foundation model for physical AI, developed and trained in Metzingen, Germany. CEO David Reger and PLA lead Dr. Jens Buchner explain the system in the accompanying video. The company calls it a Perception-Language-Action (PLA) model that goes beyond camera-only vision-language-action approaches.
Neuron AI combines 3D images, tactile and force signals, audio, the robot’s own position and movement, and language into one shared picture of the situation, updated continuously. From that picture the robot decides the next action. A memory layer, trained on memory tasks, is meant to support object permanence—the idea that an object still exists when it leaves the camera’s view—and a basic sense of causality. Training draws from robots operating in NEURA Gyms, simulation, and people demonstrating motions in sensor-equipped suits. The model runs across five of NEURA’s robot embodiments and their grippers and hands. Customers can fine-tune it through Neuraverse and deploy the result to fleets. NEURA plans an autonomous laundry demonstration with its 4NE1 at NVIDIA GTC Berlin.
Most robot models still reason mainly from what the camera sees. NEURA is arguing that physical work needs the same cues people use—a click, a force spike, a remembered location. The “world’s leading and only” language is the company’s claim. The useful distinction is the explicit addition of touch, sound, and memory on top of vision and language.
Watch NEURA’s Neuron AI explanation.
Open the official video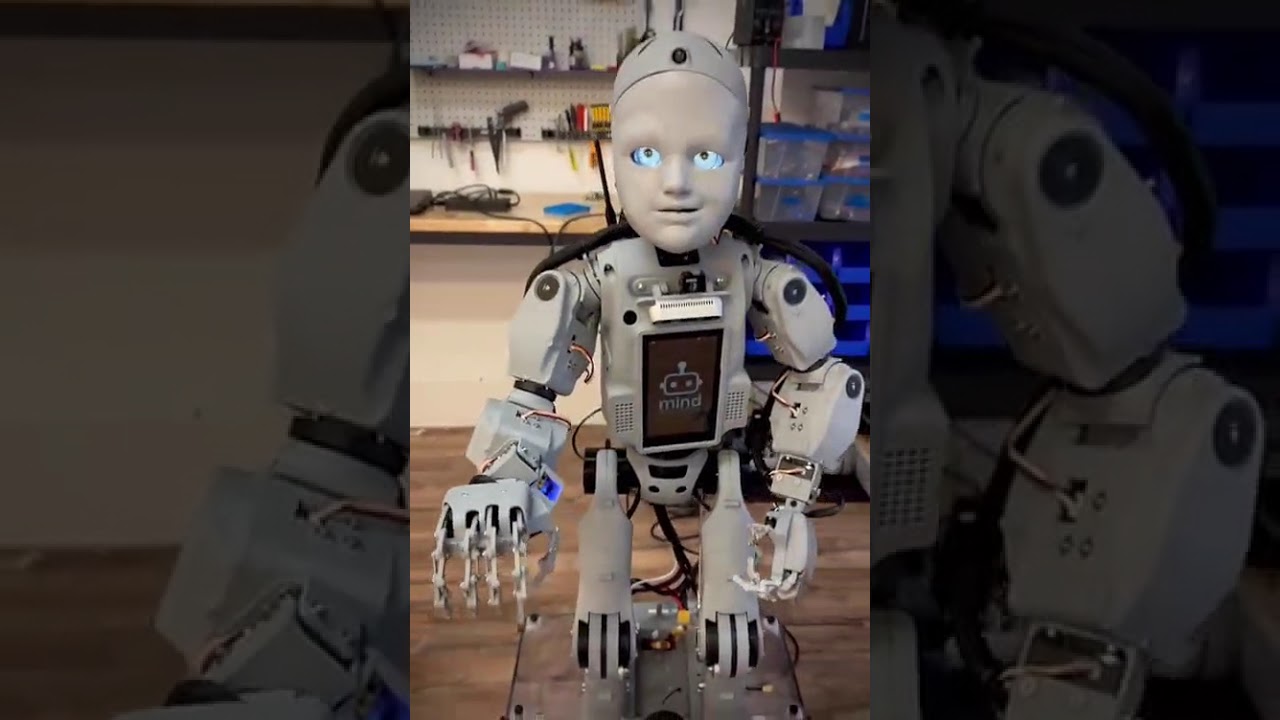
Mind Children’s social humanoid is built for connection, not factory work.
Read full story →A short from Mind Children captures the moment Codey, its child-sized social humanoid, initiated an unscripted fist bump in the middle of a conversation. The company presents the clip as an example of real-world social robotics rather than a rehearsed demo. Codey stands about three feet tall, rolls on wheels, and is designed for interaction instead of lifting or assembly.
Mind Children, co-founded by Chris Kudla and Ben Goertzel, has positioned Codey for classrooms, elder care, hospitals, and public venues. The target retail price has been described as under $10,000. The robot can hold conversations, maintain eye contact, and navigate on its own; physical chores such as fetching objects remain limited. Recent updates include work with SingularityNET’s OmegaClaw framework aimed at longer memory of past interactions, and new capabilities such as simple games. In mid-October the robot was shown at a technology event at Stanford, where the company again emphasized communication and relationship-building over labor tasks.
Most humanoid attention goes to factory work. Codey is aimed at the opposite problem—loneliness, classroom attention, and simple human presence. An unscripted fist bump is a small signal that the interaction loop can produce something spontaneous. It is not proof of reliable caregiving. It is the kind of moment the company says it is optimizing for.
Watch Codey’s fist-bump moment.
Open the video
In-house machining and same-roof assembly aim for faster iteration to walking hardware.
Read full story →Boston Dynamics’ October 14 video walks through the Atlas shop floor, from custom part to running robot. The company says the floor is built around precision, rapid assembly, and real-time collaboration. By machining parts in-house and keeping assembly and repair under one roof, it aims for the manufacturing velocity needed to turn complex designs into walking hardware at scale.
Coverage of the film notes that builds that once took multiple days are now roughly one day on the Waltham prototype operations floor. The stated ambition is to compress that further—toward one hour by 2027 and eventually minutes. Engineers and machinists can discuss a design change on the floor and see revised parts move into an assembled robot without long external lead times. Gear cutting and tight-tolerance work stay in-house so iteration loops stay short. The video is a look at process, not a published production rate or cost.
A humanoid that only exists as a carefully built prototype does not become a product. Boston Dynamics is arguing that control over machining, assembly, and repair in one place is how it will increase the rate at which complex designs become working robots. The next evidence is whether the one-day figure keeps falling.
Watch Boston Dynamics’ Atlas manufacturing film.
Open the official videoDigit 5 is planned to run 90 minutes and recharge in 9 minutes, supporting more than 20 hours of work in a day through short charge cycles.
Agility Robotics has selected Nyobolt as the ultra-fast charging battery technology partner for its Digit 5 humanoid. The companies announced on October 15 that the system is designed to deliver 90 minutes of runtime and recharge in 9 minutes, for a 10:1 run-to-charge ratio. That is an improvement from the 2:1 ratio Agility has attributed to Digit 4. Agility says the resulting duty cycle can support more than 20 hours of productive work in a 24-hour day, enough to cover more than two full shifts. Chief Business Officer Daniel Diez said Digit’s uptime is the business case for customers. Early-access units with the Nyobolt system are targeted for warehouse operators in the first half of 2027, with broader availability expected over the following six to nine months.
Nyobolt, based in Cambridge, UK, develops high-power battery technology for demanding industrial conditions. Co-founder and CEO Sai Shivareddy said the packs were chosen because Digit 5 needs more power from a smaller, lighter pack in environments where reliability is not optional. Agility has described Digit 5 as its first humanoid designed for cooperatively safe work at scale near people. The battery upgrade is one of several changes on the new model. Pack capacity, charging power, and quantified cycle-life data were not included in the announcement. The performance figures are company targets for the system, not measured results from deployed Digit 5 units.
The partnership addresses a practical constraint in humanoid fleets: downtime for charging. A 10:1 ratio leaves a high share of the day available for work if the robot can dock, charge, and return without long interruptions. Agility has existing commercial deployments of earlier Digit models at sites including Schaeffler, GXO, and Toyota facilities. Digit 5 is intended to expand that work into closer proximity to people and longer daily operation. The Nyobolt system is framed as one of the pieces that makes the higher utilization target reachable. Whether the 9-minute charge holds under real warehouse vibration, temperature, and duty cycles will be tested in the planned pilots.
Agility is completing its business combination with Churchill Capital Corp XI. The SEC has declared the S-4 registration statement effective. The deal values Agility at a $2.5 billion pre-money equity value and is expected to deliver more than $620 million in gross proceeds. The combined company is expected to trade on Nasdaq under the ticker AGLT by the end of the fourth quarter of 2026, subject to remaining conditions including a shareholder vote. The battery announcement arrives as Agility moves toward that public listing. Digit 5 and its charging performance will be part of the commercial story the company presents to public-market investors.
Humanoid fleets in warehouses and manufacturing need high utilization to improve economics. A robot that spends a large fraction of the day charging reduces the effective capacity of the fleet. Agility’s claim is that the Nyobolt system changes that ratio enough to support two-shift coverage from a single robot. The 90-minute runtime and 9-minute charge are the stated targets. Early-access pilots in the first half of 2027 will be the first real-world check of those numbers under continuous industrial use. The partnership is a supplier selection for Digit 5’s power system, not a claim that the full performance has already been demonstrated in customer facilities.
Agility Robotics has named Nyobolt as the battery technology partner for Digit 5’s planned 90-minute runtime and 9-minute recharge. The company says the resulting 10:1 ratio can support more than 20 hours of work in a day. Early access is targeted for the first half of 2027. The figures are company targets. The announcement coincides with Agility’s planned Nasdaq listing as AGLT following its business combination with Churchill Capital Corp XI. The video shows the charging approach; the operational test will be the pilots.
The Korea AI and Robot Industry Association announced on October 15, 2026 that Hyundai Motor, Qualcomm Technologies, and STATS ChipPAC Korea have joined the group. Hyundai Motor joins as a vice-chairman company. Qualcomm joins as a board member company. STATS ChipPAC Korea joins as a regular member. The association said it will use the companies’ expertise and networks to support policy development, proof-of-concept projects, international market expansion, and cross-industry collaboration. Standing vice chairman Bae Seok-tae said the new members strengthen the association’s ability to help South Korea lead in the global AI and robot market. The announcement comes ahead of RoboWorld 2026, scheduled for November 4–7 in South Korea.
Hyundai Motor has been a general member of the association since 2009. The elevation to vice-chairman status gives it a larger role in the association’s direction. Hyundai Motor Group has expanded its robotics footprint through the acquisition of Boston Dynamics and investments in AI and autonomous systems. Qualcomm’s participation brings semiconductor and edge-compute expertise relevant to robot platforms. STATS ChipPAC Korea is a semiconductor packaging firm; its membership adds advanced packaging capability to the association’s network. The association frames the additions as a way to break down barriers among automotive, semiconductor, AI, and robotics sectors.
The Korea AI and Robot Industry Association works on policy recommendations, field demonstrations, overseas market support, and cross-industry models. Adding large automotive and semiconductor companies is intended to broaden the industrial base available for those programs. Hyundai’s existing membership and the group’s broader robotics activities, including Boston Dynamics, give the association a direct link to a major Korean industrial player already investing in humanoids and physical AI. Qualcomm and STATS ChipPAC bring component and packaging perspectives that are relevant to the hardware side of robot development and production. The practical effect will depend on how the association uses the new members’ networks in specific projects.
South Korea has been expanding activity in physical AI and humanoid robotics, including regulatory sandbox pilots for factory deployments and investments by major groups. The association’s membership expansion is one institutional step in that broader activity. RoboWorld 2026 next month will be an early public venue where the new members’ involvement may become visible through exhibits, sessions, or joint announcements. The association’s website is korearobot.or.kr. The October 15 announcement is a membership update, not a product or technology launch. It signals continued consolidation of industrial participants around Korea’s AI and robotics policy and project framework.
Hyundai Motor, Qualcomm, and STATS ChipPAC Korea have joined the Korea AI and Robot Industry Association at different levels. Hyundai is a vice-chairman company, Qualcomm is a board member, and STATS ChipPAC Korea is a regular member. The association plans to draw on their expertise for policy work, demonstrations, and market expansion. The move comes ahead of RoboWorld 2026 in November. It is an industry-association membership announcement that reflects ongoing alignment between large Korean and international companies and the country’s AI and robotics sector. No specific joint projects were detailed in the announcement.
Google DeepMind researchers used Gemini 4 Argon in an internal test to watch a video of a human playing cornhole and generate the simulation and control needed for Apptronik’s Apollo 2 humanoid to sink seven consecutive shots on real hardware. The model mapped the human arm swing and release onto the robot’s joints, used the robot’s cameras to locate the board, built a MuJoCo physics simulation of the body and board, practiced the throw in simulation, and then transferred the result to the physical robot. On the real robot it adjusted release points based on where bags landed until seven shots went in. Google calls the workflow Video-to-Sim-to-Real and says it compresses weeks of manual modeling into a few hours. The demonstration was announced with Gemini 4 Argon on October 13.
Gemini 4 Argon is Google’s new frontier model, made available to developers and enterprises. In the cornhole test it was instructed to learn a physical skill outside its prior training distribution by watching ordinary video. The company reports that Argon scored 87 percent on its Embodied Reasoning benchmark, which tests understanding of physical and spatial problems in three-dimensional environments, and that it outperformed other frontier models on that test. The cornhole result is an internal demonstration of one throwing task. Google has not published details on board distance, total number of throws before the seven consecutive successes, or how the result generalizes to other objects, viewpoints, or contact dynamics. The video shows the sequence from human footage through simulation to the successful throws.
Apptronik’s Apollo is a humanoid platform that has been used in pilots with companies including Mercedes-Benz, GXO, and Jabil. The cornhole test is not a commercial deployment; it is a research demonstration of a training pipeline. The claimed advantage is the reduction in manual work required to build a usable simulation from video of a human performing a task. Once the simulation exists, the model can practice and then transfer to hardware, with further refinement from real-world feedback. Google has described similar pipelines on other tasks, including raising a robot’s success rate on a different manipulation task from 56 percent to 75 percent. Those figures are company-reported. Independent replication of the cornhole result has not been published.
Video-to-sim-to-real is one proposed way to expand the amount of training data available for physical AI. Ordinary videos of people performing tasks become potential sources of simulation and control targets. The practical limits are the accuracy of the inferred physics, the safety of transferring untested motions to hardware, and the need for real-world feedback when the simulation does not perfectly match the robot or the environment. The cornhole demo shows that, for this particular throwing task under controlled conditions, the pipeline produced a working result in hours rather than weeks of manual setup. It does not establish that the same approach will work for arbitrary industrial tasks or without human supervision during the real-world phase.
Google DeepMind has shown Gemini 4 Argon watching a video of cornhole, building a MuJoCo simulation, and enabling Apptronik’s Apollo 2 to sink seven consecutive shots on real hardware. The company says the Video-to-Sim-to-Real workflow reduces weeks of manual modeling to a few hours. The result is an internal demonstration of one skill. Argon’s 87 percent score on an embodied reasoning benchmark is a separate measure of the model’s performance on spatial and physical questions. The video documents the cornhole sequence; broader generalization and safety bounds remain open questions for future tests.
The company is open-sourcing the Python SDK and the onboard Asimov Edge software so developers can write applications that run on the open-source humanoid.
Menlo Research has open-sourced the Menlo SDK and Asimov Edge software for its Asimov 1 humanoid. The Python SDK connects application code to the robot’s movement, joint state, camera, and audio. Asimov Edge is the software that runs on the robot itself: it checks incoming commands and arbitrates control between an application, a gamepad, and other controllers. Developers can build on existing interfaces, extend the SDK, and use coding agents that understand it. Possible uses include replaying a motion, building a VR control interface, connecting a voice application, or running a trained policy on the hardware. Source is on GitHub; documentation is at docs.menlo.ai/sdk.
Asimov 1 is a 1.2-meter, 35-kilogram biped with 25 actuated degrees of freedom. Legs have six degrees of freedom each; arms have five; there is a waist yaw and a two-degree-of-freedom neck. The head carries a monocular camera and stereo microphones; the torso has a speaker and an IMU. Onboard compute is a Raspberry Pi 5 for media and networking plus a Radxa CM5 for motion control. Menlo has already open-sourced the mechanical CAD, electrical design, simulation models, and bill of materials. A DIY kit is listed around $20,000. The robot is positioned as a research and educational platform for whole-body control and locomotion.
The SDK is a client of Asimov Edge, so commands pass through the robot’s safety layer. Cockpit software and a paired gamepad outrank application commands. Connection modes include UDP on the robot’s network, a hybrid mode that adds LiveKit for camera and audio, and a full LiveKit mode. Developers can stand the robot, set velocity, damp, run trajectories, balance, and set joints. State reads return mode, joints, IMU, battery, and alerts. The package is on PyPI as menlo-sdk and requires Python 3.12 or newer.
Menlo Research is the company behind both Asimov and the earlier open-source AI project Jan. The team is distributed across Singapore, Vietnam, and the United States. Hardware is treated as an open reference design that manufacturing partners can build; software and intelligence remain the focus. Asimov 1 launched earlier in 2026. The open-source approach now extends from CAD and BOM to the control software developers write against. That combination—buildable hardware plus a documented, open SDK—is the practical claim.
What the open source does not yet do is turn the robot into a finished application platform. Full-body teleoperation is still listed as in development. The locomotion policy ships in the firmware; direct motor control and telemetry are available through the Edge software or the SDK. A developer who wants to collect data, test a policy, or write a simple control loop can do so. A developer who wants a production-grade unsupervised skill is further along the path. The open SDK lowers the barrier. It does not replace the need for a working robot and a safe workspace.
Menlo has made the control software for Asimov 1 available in the same open way as the hardware designs. Developers can write Python that stands the robot, walks it, reads its sensors, and uses its camera and audio, with the onboard Edge software still checking commands. The GitHub repositories and documentation are public. The DIY kit remains the route to hardware. The announcement is the software side of the open platform. Whether teams ship useful applications will depend on how many robots reach labs and how quickly the examples mature.
NEURA Robotics introduced Neuron AI on October 14, 2026. The company describes it as a multimodal foundation model for Physical AI and calls it the brain of the physical world. The architecture is Perception-Language-Action, or PLA. It combines 3D vision, touch and force data, audio, robot state, and language, then aligns them over time with a memory component so the robot can act on information that cameras alone do not capture and can retain context when objects leave view. The model is developed and trained in-house in Metzingen, Germany. Founder and CEO David Reger said an intelligent robot needs a brain that brings its senses together and remembers what happened. Independent benchmarks have not been published.
Neuron AI is trained on real-world robot data collected in NEURA’s own gyms, simulation-amplified data, and human demonstrations. The company says one model runs across five of its robot embodiments and their grippers and hands. Customers can fine-tune the model for their own tasks and deploy skills across fleets through the Neuraverse platform. Time-to-Skill is presented as the central measure of progress. Inference is described as local and real-time on the robot. A public demonstration is planned for NVIDIA GTC Berlin, where NEURA’s 4NE1 humanoid is scheduled to complete an eleven-minute laundry sequence fully autonomously. That sequence will be the first extended public test of the model on hardware.
The practical distinction NEURA draws is between models that primarily see the world through cameras and a model that also uses touch, sound, and memory of prior actions. Examples include confirming a lock has opened by its click and resistance, or gripping an object that is no longer in view. Object permanence—remembering that an object still exists after it leaves the camera frame—is presented as a requirement for physical tasks that cameras cannot solve alone. Whether those capabilities hold under real workplace variability is the open question. The company has not released quantitative comparisons. The architecture description and the planned laundry demo are the public evidence.
NEURA is a German robotics company that has positioned itself in the humanoid and cognitive robotics space. Its product family includes the 4NE1 humanoid across generations, wheeled variants, and other bimanual platforms. The Neuron AI launch is framed as the intelligence layer that can sit on top of those bodies and be fine-tuned by customers rather than rebuilt for each new task. For a buyer, the relevant questions are how long fine-tuning takes, what data the customer must supply, and how the model behaves when the task drifts from the training distribution. Those numbers are not in the announcement. The model is the offering; the laundry sequence is the scheduled public check.
Memory and multi-sensory fusion are harder problems than vision alone, and they are also the problems that limit many current robot systems in unstructured settings. A robot that can only act on what is currently in frame will fail when a tool is set down out of view or when contact must be judged by force rather than by sight. NEURA’s claim is that Neuron AI addresses those cases by design. The evidence offered so far is the architectural description, the training sources, and the upcoming demonstration. Until the laundry task or other independent tests are public, the model remains a company announcement with a clear technical thesis and a scheduled first long-horizon public run.
NEURA Robotics has released Neuron AI as its multimodal foundation model for physical robots. The model is designed to fuse 3D vision, touch, audio, robot state, and language with memory, and to run across multiple NEURA embodiments. Customers are expected to fine-tune skills and deploy them via Neuraverse. The first extended public test is an eleven-minute autonomous laundry sequence on the 4NE1 humanoid at NVIDIA GTC Berlin. The announcement is the model and the thesis; the demonstration will be the next data point. No independent performance numbers have been published yet.
Autowash is using KUKA industrial robots at its Colorado locations to perform touchless car washes. The system relies on KR CYBERTECH robots, 3D vision, and software that scans each vehicle and generates a customized path for washing and drying. Four cameras create a 3D model of the car; the planning software then produces a unique wash plan for that vehicle’s shape and attachments. The company says the approach delivers a faster, damage-free wash while reducing water and energy use. First commercial robotic bays are operating at the Lakeside location in Wheat Ridge. Autowash plans to roll the system out across more of its roughly 26–27 sites. The application is unusual for industrial arms that more commonly appear in factories.
Autowash was founded by Dennis and Erin Dreeszen and began with a single touchless location around 2013. The chain has grown to more than two dozen sites in Colorado. The founders have described the robotic system as a way to keep the wash completely touchless while improving consistency and resource use. In company materials they report washes in about four minutes versus a prior eight-minute cycle, water use around 20 gallons per car, and reductions in electricity compared with conventional touchless equipment. Those figures are company claims based on their own installations. Independent third-party measurements have not been published.
The technical approach is straightforward once the 3D scan exists. The robots carry custom tool heads with spray nozzles and air knives. Because the path is generated from the actual vehicle model rather than from a fixed template, the system can accommodate different body styles and attachments without a separate program for each. KUKA’s KR CYBERTECH series provides the reach and payload for the bay. The software layer handles the scan-to-path generation. The result is a wash that stays clear of the vehicle’s surfaces while still covering the body. That is the practical advantage over a fixed gantry or brush system designed around an average car.
Industrial robots are rarely the first choice for a consumer car wash. They cost more than conventional equipment, require a controlled bay, and need integration work that most wash operators do not perform in-house. Autowash’s decision to develop the system with KUKA and then deploy it commercially suggests the company sees a path to better margins or higher throughput once the capital is amortized. The chain already operates at a scale where a repeatable automated bay can be rolled out. The Lakeside site is the proof of concept in revenue service. Subsequent sites will test whether the same configuration can be replicated without custom engineering for every location.
The limits are the usual ones for any robotic cell that touches the physical world. A 3D scan can miss a trailer hitch or a damaged body panel. High-pressure water and air still require the nozzles to stay at a safe distance. Weather, customer behavior, and maintenance of the arms and vision system will all affect uptime. Autowash has not published failure rates or a full cost comparison against its previous equipment. What it has published is the architecture—scan, plan, execute with industrial arms—and the early commercial deployment. For the broader robotics industry the interest is the application itself: industrial robots performing a high-volume, consumer-facing service outside a factory.
Autowash is deploying KUKA KR CYBERTECH robots with 3D vision to generate per-vehicle wash and dry paths at its Colorado touchless car washes. The first commercial bays are running at the Lakeside site in Wheat Ridge, with plans to expand across the chain. The company reports faster cycles and lower water and energy use relative to its prior systems. Those are company figures from the installations. The system is an industrial-robot solution for a service that has historically used fixed machinery. The video shows the arms and the scan-to-path process; the business test is whether the same setup can be replicated profitably at the remaining sites.
The book argues that humanoids will scale as infrastructure, not as a consumer app, and that the missing piece is the ecosystem around the robot.
Wiley published The Humanoid Economy on October 13, 2026. The full title is The Humanoid Economy: What Physical AI Means for Investment, Industry, and the Future of Work. The author is Modar Alaoui, founder and general partner of ALM Ventures and founder and chair of the Humanoids Summit. The hardcover is 240 pages, ISBN 978-1-394-45364-1. An audiobook narrated by Brandon Pollock is listed. A simplified Chinese edition is licensed to CITIC Press, with a 2027 release. The book is for investors, business leaders, robotics founders, and policymakers who want a map of the system around the robot, not a product review of any one machine.
Alaoui’s argument is that the robot is not the economy. The economy is the set of things that have to exist around it before a buyer can put one on a floor and leave it there. Capital, manufacturing, infrastructure, safety standards, public policy, labor markets, and human acceptance are the chapters. The book treats humanoids as an industrial technology that will scale more like a telephone network than a consumer app. That is the line he has used in the publication materials. It is a claim about pace and infrastructure, not a forecast of unit sales. A demo that walks and a plant that runs a shift are different problems, and the book is about the second one.
Alaoui is an investor and a convener, not a robot maker. ALM Ventures is a Silicon Valley firm focused on humanoids, physical AI, and spatial intelligence. The Humanoids Summit has editions in Silicon Valley, Tokyo, Seoul, and London. He is also founder and chair of the Bay Area Robotics Association and creator of International Humanoids Day. Those roles put him in the rooms where capital, founders, and operators meet. The book draws on that position. It is an insider’s account of how the field is trying to move from demonstrations to commercial scale, written by someone who has been building the rooms rather than the bodies.
Across seven chapters the book traces why the humanoid form fits environments already built for people, how AI maturity and labor shortages lined up, what it takes to engineer and deploy a system, and how venture capital, policy, safety standards, and summits combined to build an ecosystem. Market projections of multi-trillion-dollar scale by mid-century, including figures up to $5 trillion by 2050, appear in the publisher materials. Those are projections, not results. The useful part of the book is the map: what has to be true before a humanoid is infrastructure rather than a stage act. Endorsements from robotics leaders, including Hiroshi Ishiguro and Werner Kraus of Fraunhofer IPA, are listed on the publisher pages.
Publication events followed the release. A book signing and fireside chat in San Francisco on October 13, and another at MassRobotics in Boston on October 15. The site is thehumanoideconomy.com. For a field that still measures itself in clips, a 240-page hardcover from a major publisher is a different artifact. It does not prove that humanoids will reach commercial scale. It sets out the conditions Alaoui thinks have to be met, and the audience he thinks needs to hear them. Investors and policymakers are the readers. A plant manager looking for a price and a failure rate will not find one here.
The Humanoid Economy is out from Wiley. The argument is that the next phase of the field is the ecosystem, not the next demo. Alaoui’s position as an investor and summit chair is the vantage. The book is the map he is offering. Whether the map is right is a question for the next two years of deployments, not for the publication week. The clip is the author on the thesis. The book is the longer version.
DEEP Robotics has put a Lynx wheeled-legged quadruped on station at the Fuyang Grain Storage Area in China. The company says the robot is carrying out all-weather inspections and autonomous patrols. The machine combines wheels with four legs. On a flat yard it rolls. On steps or rough ground it uses the legs. That hybrid is the point of the design. A pure wheeled robot stalls at a curb. A pure quadruped is slower on a long flat patrol. The grain yard has both. The film shows the robot moving through the site. It is a deployment claim, not an independent audit of how many hours it has already run.
Lynx is part of a family. The industrial M20 weighs about 33 kg, carries a 15 kg payload, climbs steps up to 80 cm, and is rated IP66. It runs in temperatures from about -20 °C to 55 °C. The sport model is lighter, around 30 kg, with a lower payload and IP54. The company has used the same hybrid idea in other outdoor work: grape transport in Turpan heat, tea-leaf runs in Zhejiang, desert crossings. Grain storage is a different job. The value is a patrol that can go out in weather a person would rather skip, and that can handle a step or a rough path without a second machine.
Grain storage is a safety and maintenance problem as much as a logistics one. Temperature, moisture, pests, and access matter. Traditional wheeled robots need a prepared surface. Conventional quadrupeds can cross rough ground but give up speed on the long aisles of a yard. The wheeled-leg design is meant to keep both. DEEP Robotics has described the Fuyang work as all-weather inspection and autonomous patrol. Those are company claims. The film is the public evidence. A buyer who wants a shift length, a failure rate, or a cost per patrol will not find them in the clip. What the clip shows is a robot that can move through the site in more than one mode.
DEEP Robotics is a Hangzhou company focused on embodied AI and legged systems. The Lynx line is its answer to industrial outdoor work. The M20 was positioned as a mid-sized wheeled-legged robot for complex terrain and hazardous environments. Hot-swap batteries, SLAM, and dual-spectrum cameras for anomaly detection are part of the industrial pitch. Grain storage fits the pattern: a large outdoor site, weather, and a need for repeated patrols rather than a one-off demo. The company has put similar machines into vineyards, orchards, and deserts. A grain yard is the next setting on that list.
The limit is the same as any outdoor robot. A film of a machine moving through a yard does not say how long it runs between charges, how it handles a blocked path, or what happens when the weather is worse than the day of the shoot. DEEP Robotics has not published a shift log or a cost comparison with a human patrol for this site. The useful fact is narrower and real: a wheeled-legged robot is being used for inspection and patrol at a grain storage area, not only in a lab or a desert highlight. That is a practical application. It is not a proof that the category is finished.
DEEP Robotics has deployed a Lynx at the Fuyang Grain Storage Area for all-weather inspection and autonomous patrol, according to the company and the film. The hybrid design is the reason it can do both a long flat run and a step. The clip is the robot on the site. The numbers that would turn this into a buy decision are not in the video. The deployment itself is the news.
Officials from the Michigan Economic Development Corporation and the Michigan Department of Transportation visited Korean robotics companies Genix Robotics and T-Robotics on October 12–13, 2026. The Korea AI and Robot Industry Association was part of the meetings. The focus, according to the association, was business cooperation, technology exchange, investment opportunities, and expanding Korean robotics companies’ presence in North America, particularly in logistics automation and autonomous mobile robots. The visits are a continuation of Michigan’s longer effort to draw Korean manufacturing and technology investment into the state.
Michigan has been active in Korea. Governor Gretchen Whitmer led an investment mission to South Korea and Taiwan in September 2026, with the MEDC involved. That trip covered shipbuilding, semiconductors, robotics, drones, and future mobility. Korean companies already operating or expanding in Michigan include POEN, BRILS, HL Mechatronics, and Hansae Mobility, which announced a $93 million expansion and 102 jobs during the September trip. The October 12–13 visits to Genix and T-Robotics are a narrower robotics conversation inside that larger pattern. MEDC and MDOT on the same trip suggests both economic development and infrastructure or mobility interests are in the room.
T-Robotics has been building on its existing vacuum robot and AMR work. In late September it was selected as lead on a national project for AI-based mobile humanoid technology for display manufacturing, running through 2030 with government funding. Genix Robotics is a Korean robotics firm that has appeared in industry coverage around regulatory and market moves. The association’s account of the Michigan visits centers on logistics automation and AMRs, not on a signed deal. Meetings of this kind are how a company starts a conversation about a North American presence. They are not a plant announcement.
The practical interest for Michigan is logistics and manufacturing automation. The state has a dense auto supply chain, engineering talent, and a history of Korean investment. Korean robotics companies looking for a North American base have reasons to look there: customers, a manufacturing workforce, and an economic development agency that has already run missions and closed projects. The October visits put Genix and T-Robotics in front of MEDC and MDOT, with the Korea AI and Robot Industry Association facilitating. What comes next is a proposal, a pilot, or nothing. The meetings are the first public step.
The limit is that these are visits, not contracts. The association has described the focus as cooperation, technology exchange, investment, and North American expansion in logistics and AMRs. No investment figure, job count, or site has been announced from these two days. That is normal for an early meeting. The useful fact is that Michigan’s economic development and transportation agencies spent two days with two Korean robotics companies, alongside the industry association. It fits the pattern of the September mission and the existing Korean footprint in the state.
MEDC and MDOT visited Genix Robotics and T-Robotics on October 12–13, with the Korea AI and Robot Industry Association. The stated focus is cooperation, technology exchange, investment, and a larger Korean robotics presence in North America, especially logistics automation and AMRs. The meetings are the news. A deal, if one follows, would be a later story. Source: Korea AI and Robot Industry Association, korearobot.or.kr.
A Unitree G1 learns to restock canned goods at a Danish føtex supermarket, as HIVE works toward autonomous overnight shelf replenishment.
HIVE Robots is training a Unitree on a supermarket aisle in Denmark, and the job in this clip is cans. At a føtex near Copenhagen, a G1 is being guided through the motions of picking a tin, lining it with the row, and setting it so the next one still fits. This is a supervised training session, not a finished shift. A can is a specific problem: rigid, round, and meant to sit flush. A shelf of tins fails the eye if one of them sits proud. HIVE is a Danish robotics software and services company based in Kongens Lyngby. It provides the software, remote pilots, and robot service by the hour. føtex, part of Salling Group, is the store. Footage credit: HIVE Robots.
HIVE and føtex announced a multi-year partnership on March 11, 2026, to pilot humanoid robots for overnight shelf replenishment. The company said the first pilot was meant to start before summer. Training sessions with human operators have been under way since June, with operators guiding the movements. Independent overnight replenishment is targeted for early 2027. That remains a target, not a demonstrated capability. The current work is supervised, and the robot is still slower than a person. HIVE markets the service as available. The film shows a guided session. A can that has to sit flush is a useful case, because the failure is visible the moment the robot lets go.
Product variety is the actual job. A night list is not one SKU. It is tins, then a soft pack, then a bottle, then a box that will crush if the grip is wrong. A model that only knows one product will fail on the next. HIVE’s store app lets staff pick which products get filled, each with a photo and a shelf location, and send that list at close. Potential future tasks include expiry checks, empty facings, and items in the wrong place. Those are not in this clip. What is in the clip is the hand learning a can, under supervision, which is the step that has to happen before a morning crew can trust more than one facing.
Height is the other limit, and HIVE has said so in its own posts. The company has called its first retail robot, a Unitree G1 it names Danni, a “reliable colleague” on the night shift, and has said its only weakness is that it cannot reach the top shelves. In the same post, HIVE said a taller Unitree H2, Frankie, is expected to start in November. That is a company post, not a completed deployment. HIVE lists retail robots around 140 and 180 centimeters so the same software can cover a low facing and a high one. The machine in this short is the shorter G1. A can on a bottom shelf is in reach. A can on the top shelf is a different body.
Behind the can is the rest of the stack. Heimdall is HIVE’s teleoperation and data platform. A trained remote robot pilot can take the controls when the robot needs a hand, while operational data can support further training. Whole-body control is HIVE’s, so the robot can bend for a low shelf and reach a high one. The company says its models are trained on GPUs in Denmark and that store data is kept on European infrastructure. Charlotte Blou Sand is co-founder and chief executive. Jakob Sand is co-founder. For now the pilot is overnight, when the store is closed to customers. Expanding into busy shopping hours would introduce additional safety and regulatory questions. The can clip does not change that. It is one product in the training.
HIVE is doing the unglamorous version of a humanoid, one product at a time, with a person still able to take the controls. The partnership is in place, but the work shown remains supervised. Early 2027 is still the horizon they have put on independence. A taller body the company has said is expected in November would change the reach, not the fact that the work is still guided. The commercial shape is unchanged: the store does not buy a fleet. It pays an hourly rate, and HIVE handles the machine. A staffed night, delivered as an hourly service with store data kept on European infrastructure, is the business model. This short is the can, and it is still training.
MindOn has put a number on the speed claim it made at the end of September. In an October 12 video, nearly an hour long, a dual-arm station folds shirts under Mind-1. The company says the run reached 142 garments, about one every 25 seconds, and labels the footage 1.0x speed and fully autonomous. A person throws the next shirt onto the table after each fold. The folding is what the company calls autonomous. The feed is a human. That is a company claim for a human-fed station, not a laundry that runs itself. The arithmetic is consistent with the number MindOn published. It does not independently confirm the video, the autonomy label, or any ranking.
Mind-1 is a model, not a body. MindOn introduced it on September 30 as physical AI aimed at human-speed task cycle times, and showed it on a dual-arm robot, a wheeled dual-arm, and a humanoid. Parcel handling, shirt folding, and a humanoid collecting laundry were the scenes, labeled the same way: real time, fully autonomous. The company said packaging and parcel sorting came in faster than a person in its own tests, and folding at 25 seconds against a human 15. Those figures are MindOn’s. They are cycle times on chosen tasks, not an independent time study, and they do not include retries or a person standing beside the table.
The hour-long film is the useful follow-up, because a two-minute demo cannot show whether the pace holds. A counter on screen climbs toward the company’s 142. The description talks about sustained operation, throughput, and reliability as the requirements for real work. MindOn has called the result the industry’s fastest robotic clothes folding. That ranking is a company claim. It would need a comparable test: same garments, same start, same fold quality, same help from a person. In the materials reviewed, that side-by-side comparison was not published. What the company has published is a long, labeled clip of one station, with a person feeding each shirt.
Speed is harder than it looks in a highlight reel. Slow teleoperation data teaches a slow policy, because the model learns the tempo of the demonstrations as well as the motions. At an end-effector speed of 3 m/s, 10 milliseconds of latency corresponds to about 3 cm of movement—enough to affect a precise grasp. Consecutive guesses that disagree make the arm correct itself, which at speed becomes a shake. MindOn says Mind-1 was trained on people working at natural speed, that inference latency dropped, and that a whole-body controller holds the trajectory. Those are design claims on the company blog. The film is the public check the company is offering: does the fold keep happening for an hour, at a counted pace, on the shirts someone keeps throwing onto the table.
A folding station is a narrow slice of laundry. Someone still has to bring the shirt, judge the fold, and move the pile. Other groups are working the handoffs around the fold, wash to dry to shelf, which is a different problem from cycle time at the table. MindOn’s number is the fold itself. A humanoid collecting laundry in a room, shown in the September film, is a different job from two arms at a green table. The model is meant to travel between those bodies. The October video tests it on one of them, for long enough to count, and leaves the rest of the workflow to the person standing next to the station.
Mind-1 is MindOn’s bid to make a robot finish work at a useful pace, not just finish it. The October 12 film is the company’s claim of 142 folds in an hour on a dual-arm station, with a person feeding each shirt. The autonomy label covers the fold, as MindOn frames it. The throughput is the company’s number. A shop that wants the number should ask what happens when the shirts change, when the fold quality is checked, and when nobody is standing at the table. Completing a task was the old bar. Doing it for an hour, at a counted pace, is the new one. This film is that count, and it is still a claim.
Put two Microducks in a room and they start to sing. The small biped from Pollen Robotics, the Bordeaux team that joined Hugging Face in April 2025, syncs with its neighbors over Bluetooth and joins a piece that is being made as it goes. The company’s clip says there is no score and no conductor, and that two, three, or four ducks are enough for a choir to break out. That is the product working as designed: an affordable robot with open-source software that does something visible the moment a second one walks in. Pollen’s published open-source offering covers its software and training stack. The product materials reviewed do not list complete hardware design files. The film is the choir.
Microduck is 25 centimeters tall and weighs under 800 grams. It has 15 motors, an articulated beak for grasping objects, a front camera, LiDAR, and two inertial measurement units. Those figures are from Pollen’s press kit. Pollen Robotics says it can walk, sit, crouch, roller-skate with the appropriate attachments, and recover from many common falls. Each unit generates a voice the first time it wakes and keeps that voice. It does not talk. It quacks and sings. Pre-order price is $399 before taxes and shipping, with first deliveries targeted before Christmas 2026. Seven trained moves ship in the box. The rest is for the owner to add.
The choir is the interesting bit of the software. Ducks find each other over Bluetooth, lock to a shared beat, and take parts. In the open code, the lowest duck takes the bass, a roster is shared, and the piece is chosen for that performance, then another after a breath. The marketing line is no score and no conductor. The mechanism is a beat beacon and a seating rule, which is how a small group stays in time without a person waving a hand. Mouth and head move with the part, so the choir is visible as well as audible. Two ducks are enough. A third joins what it finds. That is the demo, and it is also a small lesson in multi-robot timing.
This is Hugging Face’s second consumer robot, after Reachy Mini, the desktop companion that stays put. Microduck is the one that moves. Pollen’s point is physical AI you can put on a table and retrain: reinforcement learning in simulation, then on the duck, with the open software stack. Races, a kickabout, and a choir are the multi-robot demos, a way to try group behavior without a lab full of hardware. A $399 biped will not stock a shelf or fold a shirt. It will let a student see what a policy looks like when it falls and gets back up. That is a different product from a humanoid, and it should be read as one.
The limit is the size, and it is the point. A duck that sings with its neighbor is a demonstration of sync, identity, and a shared clock, packed into a body light enough to post. It is not a humanoid, and it should not be read as a step on the way to one. The open stack is the serious part: a public software runtime, a public training path, and a robot priced so a classroom can own two. The choir is how that stack shows itself without a slide. A buyer who wants a night aisle or a folding station is in the wrong room. A buyer who wants an affordable robot with open-source software is in the right one.
Microducks sing together because they can hear each other over Bluetooth and agree on a beat. Pollen and Hugging Face are selling that as a $399 robot with open-source software, first deliveries targeted before Christmas, with its own voice and a beak. The clip is the choir. The product is a small body you can retrain. There is no score on the film. There is a beacon in the code. Both are true. Open source, as published, covers the software and training stack. It is a duck that starts a song when another duck walks in.
A Danish robotics company is testing a Unitree G1 for overnight shelf replenishment at a føtex near Copenhagen. Operators still guide its movements.

HIVE Robots is putting a humanoid on a supermarket aisle in Denmark, and the job is the dull one. At a føtex store near Copenhagen, a Unitree G1 is being trained to restock shelves after the doors close, including pasta in the clip on this page. The small motions are the hard ones: find the pack, get a grip, place it so the next one still fits. HIVE is a Danish robotics software and services company based in Kongens Lyngby. It provides the software, remote pilots, and robot service by the hour. føtex, part of Salling Group, is providing a real supermarket environment for testing the technology outside a laboratory.
HIVE and føtex announced their multi-year partnership on March 11, 2026. Training began in June, with human operators guiding the robot as it learns to handle different products and shelf configurations. The stated ambition is independent overnight shelf replenishment by early 2027. That remains a target, not a demonstrated capability. The current work is supervised, and the robot is still slower than a person. The film is that training session, not a shift a store can already book. HIVE markets the service as available. The footage shows a supervised trial.
The labor math is why a grocer would bother with a robot that is still learning to hold a box. føtex has said staff spend 40 to 50 percent of their time filling shelves, which is the repetitive half of a retail shift and the half customers never see. HIVE’s offer is to take the night work so the morning crew walks into a stocked aisle and spends the open hours on customers. The commercial shape is robot-as-a-service: the store does not buy a fleet, a maintenance bench, or a robotics team. It pays an hourly rate, and HIVE handles the machine. A store app lets staff select products for replenishment, each with a photo and shelf location, and send the task list for the night shift. Potential future tasks include checking expiry dates, identifying empty shelf spaces, and spotting misplaced products.
Behind the shelf work is Heimdall, HIVE’s teleoperation and data platform. A trained remote robot pilot can take the controls when the robot needs assistance, while operational data can support further training. HIVE also develops whole-body control software to help its robots bend toward lower shelves and reach higher ones. The company says its models are trained on GPUs in Denmark and that store data is kept on European infrastructure. HIVE lists retail robots around 140 and 180 centimeters tall. The machine shown in the clip is a Unitree G1.
Charlotte Blou Sand is co-founder and chief executive. Jakob Sand is co-founder. In June, Jakob Welner, formerly on the Atlas controls team at Boston Dynamics, joined as chief robotics architect, which is the hire that tells you the shelf work is being treated as a controls problem and not a demo. HIVE has also partnered with Danfoss on five-finger grasping for factory work, and it showed a restocking demo on a stand at NRF in Paris. For now, the føtex pilot focuses on overnight work when the store is closed to customers. Expanding into busy shopping hours would introduce additional safety and regulatory questions. HIVE’s current approach relies on human teleoperators who can step in when the robot needs a hand.
HIVE is doing the unglamorous version of a humanoid: a Unitree body, a Danish grocer, a night aisle, and a person still able to take the controls while the model learns the shelf. The partnership with føtex is real, and early 2027 is the date they have put on independence. The clip is that training. A staffed night shift, delivered as an hourly service with store data kept on European infrastructure, is the business model HIVE is developing around the technology.

CES 2027 is not a single hall that opens on a Wednesday. The week starts on Monday, January 4, with media day at Mandalay Bay and CES Unveiled, the preview where companies put a product in front of press two days before the floor opens to the industry. Tuesday, January 5, is the second media day. Conference programming starts that day, and C Space, the media and entertainment campus at ARIA, opens with it. The exhibit floor itself runs Wednesday, January 6, through Saturday, January 9, across the Las Vegas Convention Center, Venetian Expo, and a set of official venues that CES counts as three campuses: LVCC, the Venetian campus, and C Space. A badge that only thinks about the convention center is a badge that will miss half the week.
Hours on the floor are not the same every day, which is the detail that wrecks a late booking. Wednesday opens at 10 a.m. and closes at 6 p.m. Thursday and Friday run 9 a.m. to 6 p.m. Saturday closes at 4 p.m. A robotics team that lands on Saturday morning has already missed the keynote morning, the Unveiled briefings, and most of the meetings that get booked off the Wednesday aisle while people are still fresh. The useful map is the week, not the badge: Unveiled on the 4th, conference on the 5th, floor and stages from the 6th. The film on this page is a highlight from the last CES floor, robots beside other hardware. It is a picture of the mix. It is not the 2027 calendar.
The stages already named are mobility and computing, not a humanoid keynote, and that is worth knowing before anyone promises a robot moment. On January 6, the State of the Industry address is set for 8:30 a.m. in the Palazzo Ballroom at the Venetian. Stellantis chief executive Antonio Filosa follows, on connected vehicles and software across the group’s brands, with the talk tied to a West Hall exhibit so the audience can walk from the ballroom to the car. Waymo co-chief executive Tekedra Mawakana is listed the same day at 1 p.m. in that ballroom. Lenovo is taking its Tech World keynote to Sphere. None of these is a robot launch. They are the rooms the rest of the industry will be walking out of, which is where a humanoid meeting either gets booked or does not.
Foundry is the program closest to this beat. After a two-day debut in 2026, the AI and quantum destination returns to Fontainebleau for three days, January 6–8, with talks, demos, and the kind of hallway that software and hardware people actually use when they are not performing for a booth camera. Eureka Park remains the startup zone, the place a small humanoid team can still be found without a West Hall budget. CES Innovation Awards honorees are due in November, with embargoed products shown from January 4, which is another reason the media day matters more than the Saturday close. A short film of the last floor is a fair picture of how those zones feel in person. It does not tell you which room to be in at 8:30 on the 6th.
For a humanoid company, the week splits cleanly, and the split is the story. Unveiled is where a new hand or a new body gets a first write-up, before the floor noise starts. The exhibit floor is where a buyer walks the aisle and asks for a meeting that is not a stage demo with a marked path. Foundry is where the model people are, the ones who will ask what the policy was trained on. C Space is a different crowd, media and entertainment, useful for a bionic face and less useful for a payload chart. A team that only staffs a booth from Wednesday noon will meet the people who already had their briefing on Monday and have moved on. The last January showed how crowded the robot corner can get. The calendar above is how to be in the right room before that happens.
CES 2027 runs January 6–9 on the floor, with the real week opening January 4 at Mandalay Bay. Keynotes already set are Stellantis and Waymo on the 6th, plus Lenovo at Sphere. Foundry fills Fontainebleau for three days. Eureka Park is still the startup hall. The film is last year’s mix of robotics, hardware, and the Physical AI pitch. The program is the reason to book the earlier flight, and to know which campus you are actually walking into.

AheadForm brought Elf-Xuan 2.0 to Inclusion 2026 in Shanghai, and the point of the machine is the face. The company’s own clip, posted in September, holds on the eyes and the small movements around the mouth long enough that a viewer has to remind themselves it is a robot. AheadForm calls it a bionic humanoid, lifelike design and natural expression set on embodied AI. It is a showpiece, not a factory body, and the film is honest about that. Nobody in the frame is handing it a bin, a tool, or a shift sheet. The product is the moment a person across the room forgets, briefly, what they are looking at.
Inclusion, on the Bund, is an AI conference rather than a robotics fair, which is why a singing android fits the bill better than a palletizing demo would. Reports from the week said Elf-Xuan 2.0 performed a song written by its own system, with gesture and expression timed to the vocal, on a stage rather than in a booth corner. Coverage described synthetic skin and a face driven by many small actuators, the usual route to a microexpression that does not look like a mask sliding across a skull. Those are descriptions of a stage act, written by people who watched it. They are not a spec sheet, and AheadForm has not published degrees of freedom, payload, battery life, or runtime with the clip.
The company behind the face raised about $15.7 million in July 2026, in a round reported by the trade press rather than in a filing a buyer can read. That is enough to keep a small bionic team in parts, silicone, and stage time. It is not a humanoid factory round, and it should not be read as one. AheadForm’s public trail is the look: elves, singers, machines that hold a gaze and are filmed for the gaze. The Inclusion appearance is the clearest version of that bet, a body designed so the first reaction is recognition rather than a count of joints or a question about the hourly rate.
There is a real split in the humanoid market here, and the clip sits on one side of it without apology. Industrial machines are judged on a shift, a hand, a failure rate, and a price a plant manager can defend. Bionic machines are judged on whether a person across a table forgets, for a second, what they are looking at, and whether they stay to watch the next gesture. Both can be serious engineering. They are not the same product, and a buyer who confuses them will be disappointed by both. Elf-Xuan 2.0 is not applying for a night aisle in a Danish grocer or a line in a factory. It is applying for the room where people stay and watch.
The limit is the same as any stage robot, and it is the limit that keeps the rating at zero. A song, a look back, and a smooth turn of the head do not say what the machine does at 7 a.m., whether the face still tracks after an hour under conference lighting, or what it costs to keep the skin looking like that. AheadForm has not claimed a deployment, a wage, a lobby installation, or a second unit doing the same act the next night. The value of the September film is narrower and real: a Chinese bionic maker put a convincing face on a conference stage, and the audience treated it as a performer. That is the product working as designed.
Elf-Xuan 2.0 is AheadForm’s answer to the uncanny valley, shown at Inclusion 2026 in Shanghai and filmed so the eyes do the work. The clip is the company letting the face do the talking, which is a choice, not an omission. It is a bionic showpiece, funded like a startup, not an industrial humanoid, and it should be read as one. The aisle in Denmark and the line in a factory are different businesses. This one is the face.
The 60th CES runs January 6–9 in Las Vegas. Passes and hotels are already on sale.
Registration for CES 2027 is open. The show runs Wednesday, January 6, through Saturday, January 9, 2027, in Las Vegas, with media days on January 4 and 5. This is the 60th CES. The first was held in New York in June 1967. Hotels through the official agent, onPeak, are open as well. A standard pass is $149 through November 30 and $349 from December 1 through the show. Cancellations made in writing by December 9 are refundable, less a $50 fee. After that date, a no-show still owes the price of the badge.
For robotics, January is the week the floor fills with machines that spent the year in labs and pilot cells. The last CES put humanoids next to household helpers, warehouse arms, and a stage demo of Atlas. A public recap of that floor shows the range the organizers now treat as ordinary: humanoid bodies, intelligent machines, and the broader pitch of Physical AI, software tied to perception, motion, autonomy, and control in a real room rather than a slide. CES 2027 will be judged on whether those demos have moved since January, not on whether the aisle is crowded again.
CES is already selling the next show as the place where AI meets the physical world. Lenovo is bringing its Tech World keynote to Sphere. CES Unveiled, the media preview, is set for January 4 at Mandalay Bay, two days before the doors open to the floor. Foundry, the AI and quantum program, is listed for January 6–8 at Fontainebleau. None of that is a robot announcement. It is the calendar that robot companies plan launches around, because the buyers, the press, and the competitors are in the same halls for four days and will not all be there again until the next January.
Who shows up matters more than the badge price. Boston Dynamics used a recent CES stage for Atlas. Chinese humanoid makers have treated the show as an export window. Component firms, hand makers, and software houses fill the gaps between the big booths, which is often where the useful meeting is. A pass gets the exhibit floor, the keynotes, Great Minds sessions, and a slice of the conference. It does not get a private demo or a place in a closed-door briefing. Teams that want a meeting in the first week of January are booking now, while hotel blocks and booth conversations are still loose.
The useful filter for this beat is simple, and it has not changed. A humanoid that walks a marked path on a show floor is last year’s story. A humanoid with a named factory job, a hand that can be ordered, or a software stack another company can run on its own body is the one worth the walk across the hall. CES will have both, side by side, and the recap film from the last floor is a fair picture of how that mix looks in person. Registration being open is the news today. The floor in January will sort the rest.
CES 2027 is January 6–9 in Las Vegas, and the door is open. Passes start at $149 until the end of November, then jump. For humanoid robotics and Physical AI, it is the first big public week of the year, and the companies that intend to be on that floor are already working the list. The film on this page is what the last January looked like. The badge is for the next one.

DEEP Robotics has been running its DR02 humanoid on the streets of Hangzhou’s Xihu, or West Lake, district. In early October the company put a batch of the robots at busy intersections and at Xixi National Wetland Park, in visitor crowds and in sustained rain. The public clip shows navigation, obstacle avoidance, spoken reminders, and exchanges with people passing the corner. DEEP Robotics calls it a test of support for traffic work and tourist guidance. It has not called it a unit already on the city’s roster, and the film should be read that way.
At Zheda Road and West Wenyi Road in Lingyin Subdistrict, the robots stood at crossings in the wet. The company says they can spot common problems — a rider without a helmet, an overloaded e-bike, a pedestrian over the line, a vehicle past the stop bar — and answer with a voice prompt or a gesture rather than a ticket. In the rain clip, DR02 asks a rider to move back behind the line, calls a green light, and reminds people about helmets. IP66 protection on the whole machine is the hardware claim tied to working in that weather. No shift length, and no failure rate, was published with the film.
The other half of the trial is the scenic area, which is a different job from the intersection. West Lake and Xixi draw heavy domestic and foreign traffic in early October, and the repetitive questions — which path, which bus, what is closed today — eat the time of staff who are also meant to handle the thing that goes wrong. DEEP Robotics says DR02 took those questions in more than one language, and gave safety reminders along with route and transport answers. That is a service-window test. It is also the part a humanoid is easiest to film: a robot talking to a tourist, rather than a robot holding a post for a full morning beside moving traffic.
What the company has not said is as useful as what it has. It described a batch, not a number. It did not say how long each robot ran, whether a person was driving it from off camera, or how often the navigation held without a reset when a scooter cut the corner. A press note carried on the wires is still the company’s account of its own trial. Coverage since has treated the work as a street demonstration of a claimed all-weather design, and has been careful not to promote a test into a deployment the city has not announced.
The step from the lab to a wet intersection is still the right one to watch, which is why the clip earns the slot. A humanoid that can stand in rain, see a helmet missing, and say so in the pedestrian’s language is doing a job city staff already do, on a corner they already stand on. Whether it can do that job for a morning, beside moving traffic, without a handler in a van around the block, is the next question, and it is not answered by a one-minute film. DEEP Robotics says it will keep tuning DR02 for public-service work from the data these days produced. No timetable came with that line.
DR02 spent early October on Hangzhou roads and in a crowded park, in the rain, talking to people and pointing at traffic. DEEP Robotics is testing a helper for officers and for guides at the scenic edge of the same district. The film is that test, shot in the places the release names. A shift on the city’s payroll is not what was announced, and it should not be read into the clip.

Boston Dynamics has named Rohit Prasad chief executive, effective October 7, 2026. Prasad was senior vice president and head scientist for Alexa and artificial general intelligence at Amazon, the person associated with taking that assistant from a research bet to a product used at household scale. Hyundai Motor Group, which owns the company, said it wanted someone who had turned AI work into products people actually ship, not a research program that stayed in the lab. He follows Robert Playter, who left in February, and interim chief Amanda McMaster, who had been holding the seat.
The job in front of him is commercial Atlas, and the company has been making that case in public all year. Boston Dynamics argues that it already knows how to sell a robot: Spot and Stretch opened markets other firms are still explaining, and Atlas is the same play with a humanoid body. Learning in real environments, a design that can be built in volume rather than assembled as a prototype, and what the company calls physical intelligence are the three lines in its own film. Prasad’s hire is Hyundai putting an AI operator on top of a case the robotics team was already making.
The factory math is already public, and it is Hyundai’s number rather than a startup’s hope. In January, Hyundai said it aimed to build a plant able to make 30,000 robots a year by 2028, and to start putting them across its own sites that year. Later notes put Atlas at the Georgia metaplant from 2028, beginning with welding and logistics and moving toward component assembly by 2030. Boston Dynamics has also said the 2026 Atlas run is committed, including to Hyundai’s Robotics Metaplant Application Center and to Google DeepMind, with other customers planned for early 2027. That is a full year, spoken for, before the new plant exists.
The hand arrived just before the CEO, and it belongs in the same paragraph as the appointment. On October 1, Boston Dynamics showed a new electric-Atlas hand: four fingers, 13 degrees of freedom, no pinky, with encapsulated direct-drive actuators meant to be repeated on a line. The company tied it to mass manufacturing and to sim-to-real learning, not to a lab prototype that cannot be built twice. A humanoid sold into a car plant lives or dies on that hand, on whether it can take the tool the line already uses. Prasad inherits a body, a hand designed to be made, and a parent company that has already named the volume.
None of this is a shipped fleet, and the piece should not slide from a target to a delivery. Hyundai’s 30,000 is a factory target for 2028, and the site of that U.S. plant was still to be announced when the CEO news landed. Spot and Stretch are the commercial record, the robots already in customer hands. Atlas is the bet that the same company can do it again with a biped, under an executive who scaled Alexa from a demo to a business. The October 7 appointment is the organizational half of that bet. The hand shown six days earlier is the mechanical half.
Boston Dynamics has a new chief executive from Amazon’s AI ranks, a parent planning 30,000 robots a year by 2028, and a four-finger Atlas hand built to be made, not just shown on a stage. The film on this page is the company’s own argument for why that combination should win. The race Prasad was hired to run is the one from demonstration to a line Hyundai can actually fill.
ARC put motion-suit fighters on Unitree G1 robots at *SCAPE.
Read full story →ARC staged what it calls Singapore’s first full-sized humanoid fight night on October 7 at *SCAPE. More than 380 people watched. Professional fighters in motion-capture suits piloted Unitree G1 and EngineAI T800 robots in real time. Katena’s control system mapped each pilot’s body onto the machine. This was not an autonomous bout.
Teams Iron Fang and Steel Shadow each fielded a roughly 35 kg G1 and a 75 kg, 1.73 m T800. Muay Thai, MMA, boxing, and kung fu fighters took turns. ARC says Lukas Leasure, on Iron Fang’s G1, dropped low and knocked the opposing robot down. The clip is that G1 exchange under suit control.
The spectacle is easy to misread as a machine that can fight. The news is the control loop: a trained person, a motion suit, and a humanoid light enough to take a fall in front of a crowd.
Watch the G1 exchange from the Singapore card.
Open the video
Coverings now have to cushion a bump and report a touch.
Read full story →A bare actuator shell is a poor roommate. Skin work now splits in two. One side is a covering: fabric or silicone that sheds heat, kills static, and softens a bump. The other is a sensor: a sheet that reports force so a hand knows it has made contact.
On October 8 the US patent office published a Tesla filing for a soft, compliant tactile array that can wrap a thumb, palm, or finger and act as skin. The filing, US 2026/0310299 A1, does not name Optimus. It does say the sensors can cover fingertips, palms, and other portions of a humanoid. The short is a look at a covering. The news is that skin is now a parts problem, not only a demo finish.
A humanoid that works near people needs a surface that fails softly and a hand that can feel a slip. Skin is where those two requirements meet.
Watch the skin short.
Open the video
The athletic commission told REK an unsanctioned cage bout is illegal.
Read full story →The California State Athletic Commission has sent a cease-and-desist letter to REK, the startup that staged a September 18 cage bout in San Francisco between influencer Frankie LaPenna and a roughly six-foot humanoid with a Terminator-style head. Chief executive Cix Liv posted the letter on September 30. The commission called the bout unsanctioned.
The order tells Liv and REK to stop holding, promoting, or advertising any boxing or mixed-martial-arts contest involving any human in California without commission approval, and without a license under Business and Professions Code section 18640. The robot was piloted, not autonomous. The letter covers the human in the cage, not robot-versus-robot cards. REK was still listing a San Francisco robot event for October 9.
Robot fight nights have been treated as content. California has treated one of them as an unsanctioned combat sport. That is the first regulatory line drawn under this format.
Watch the bout that drew the letter.
Open the video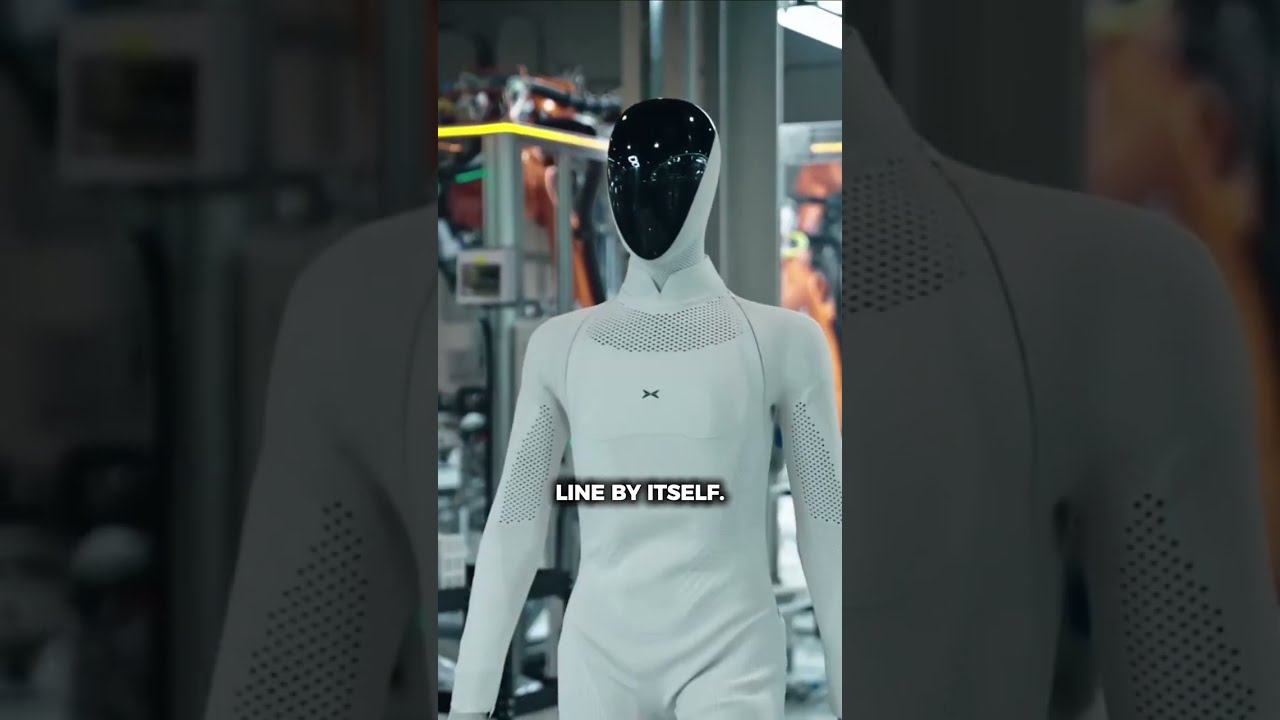
The company says the first robot finished automated assembly and left on its own.
Read full story →XPeng said in early September that its humanoid production line had started, and that the first IRON finished automated final assembly and walked off under its own power. The company calls it the first high-level general-purpose humanoid built on an automated line. That “first” is XPeng’s claim. The short is the walk-off.
IRON is listed with 76 degrees of freedom, 21 in each hand, a flexible lattice shell, and three Turing chips for up to 2,250 TOPS. XPeng says more than 80 percent of core processes on the line are automated, that scaled production is targeted by the end of 2026, and that commercial deliveries in China and overseas are planned for 2027. Capacity and price were not disclosed.
Humanoid companies are now being judged on whether a robot can leave a line without a handler. IRON’s clip is that claim. Shipments are the next one.
Watch IRON leave the line.
Open the video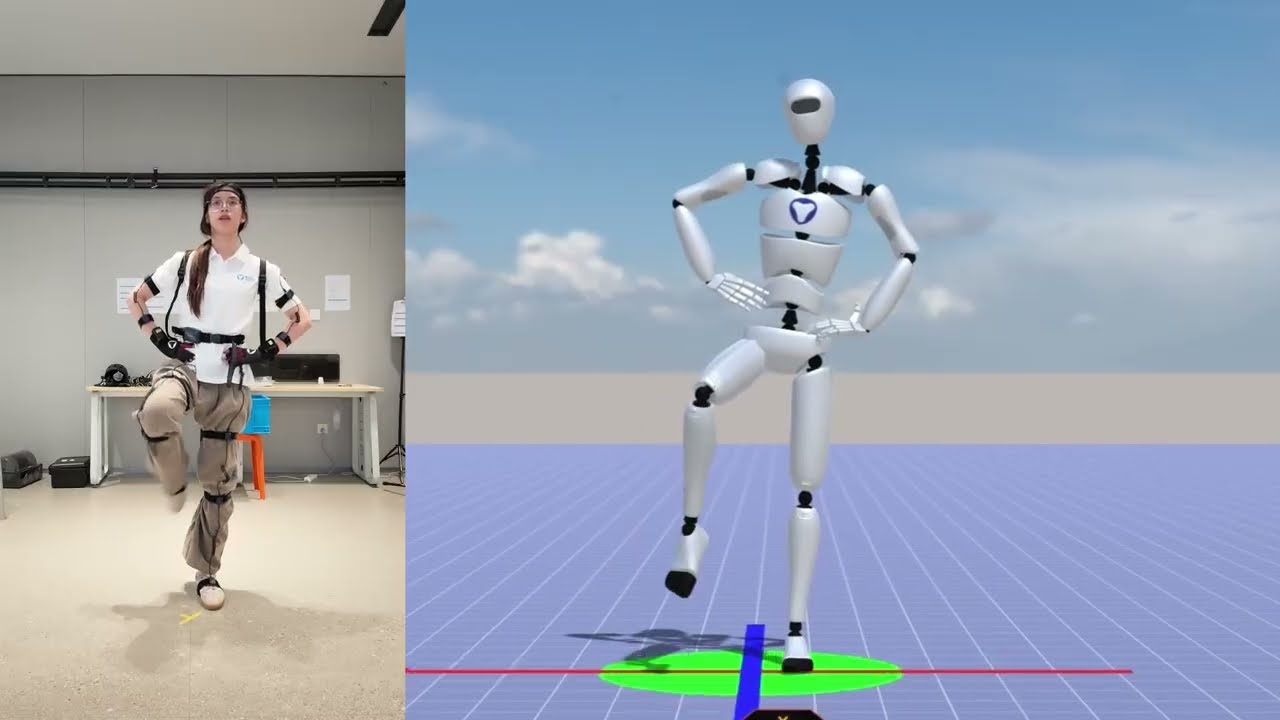
A full-body capture rig aimed at humanoid walking and finger data.
Read full story →Virdyn’s film is a full-body inertial suit plus hand gloves, sold as one capture rig for humanoid gait and dexterous-hand training. The company says the flagship setup carries 31 nodes across torso, limbs, palms, and fingertips, and that a short calibration is enough to drive a robot in real time.
The pitch covers gait data, fine grasps, haptic vibration in the gloves, and software bridges to Windows, Linux, and ROS, with C++, Python, and MATLAB. Those are vendor claims in the video. No independent latency or drift figure is attached. The useful fact is the package: body and hands in one recording, which is what imitation-learning teams actually need.
Humanoid policies are starved of paired body-and-hand demonstrations. A 31-node suit is a data tool. The clip shows the tool. It does not show that the data is good enough to train a factory gait.
Watch Virdyn’s motion-capture film.
Open the videoPhantom MK1 is pitched at factories and defense. A June range clip is the company showing the second half of that pitch.

Foundation wants Phantom MK1 to do two jobs with one body. The San Francisco company, also known as Foundation Future Industries, was started in 2024 by Sankaet Pathak, with former Marine Mike LeBlanc among the co-founders. The robot is a full-size humanoid, reported around 175 centimeters and 80 kilograms, with a payload near 20 kilograms. Foundation talks about it as a machine for unstructured sites, the kind of floor or yard that was not rebuilt for a robot. The commercial offer is a service contract, not a robot in a crate.
The factory side is the nearer sale. Foundation has described manufacturing and logistics as the work it is building for first: moving heavy pieces, covering shifts that are hard to staff, and doing it without a new line layout. Defense sits on the same platform. Reporting this year put U.S. service research contracts in the tens of millions, and said two Phantom units went to Ukraine for evaluation rather than as an autonomous combat detachment. Public accounts still put a person on the lethal decision. Contract totals are not consistent from one write-up to the next.
In June the company posted a short from Las Vegas in which Phantom operates a light mortar on a range, and pointed viewers to a longer film on what that implies. Foundation has said most of the work so far is logistics, and that handling equipment built for people is the longer proof it wants to show. The clip is a supervised demonstration from the company that builds the robot. It is not a field manual, a completed program, or a count of robots in service. Price is still undisclosed, and listings treat Phantom as pre-commercial.
Under the footage, the product is fairly plain. Camera-first sensing, teleoperation when the robot does not know the next move, cycloidal actuators, and an upper body built to take a human tool. A 2025 nightclub appearance and later industrial and defense footage are the public trail. None of it is an uptime study. The ambitious part is the production talk: tens of thousands of units by 2027, from a base that is still counted in dozens. That is a plan sitting on modest private funding, separate from the government work.
The interesting tension is the buyer. A plant manager and a service branch do not want the same day from a robot, but Foundation is betting they can share the hardware. A humanoid that can use doors, vehicles, and tools already in the world is the argument for keeping one design. Whether that argument survives a real shift, or a real evaluation, is the part the June clip cannot answer. Funding notes differ, from an early round near $11 million to later private totals around $21 million.
Phantom is Foundation’s bid to put the same humanoid in a factory and in a defense yard, sold as a service. The June short is the company showing the defense half of that bet on a range in Las Vegas. The industrial work is still the nearer business, and the fleet is still a target rather than a delivery.
The humanoid supply chain does not start with the face. It starts with the harmonic reducer, the roller screw, and the motor packed into a joint small enough to hide in a limb. At Guohua Intelligent in Qingdao, that path runs from those parts to integrated joints and then to bodies, some finished, some still open to the wiring. Reach farther with the same load and the shoulder wants more torque. Run it harder and heat becomes the limit. The finished walk only looks easy.
Guohua was founded in Qingdao in 2021 by Wang Guang to make those parts. The catalog runs from harmonic reducers and planetary roller screws to rotary and linear modules, then to arms and complete platforms. The company says it has more than a hundred reducer models. After a 2025 round that included Xiaomi’s manufacturing fund, it described a new base sized for 100,000 reducers, 20,000 screws, 5,000 joint modules, and 1,000 bodies a year. An earlier park plan used a higher joint number. Either way, the bet is volume in the part everyone else is short of.
High-end reducers were an import business for a long time. Chinese humanoid programs still buy a large share of gearboxes, screws, and encoders from a short list, and a late gearbox stops a body line even when the software is ready. Guohua’s case is that designing the reducer, the screw, and the joint together cuts that wait. A developer can take a module, an arm, or a whole platform. Payload, reach, and duty cycle decide which one. A heavier hand is a different joint, not a setting in the controller.
On the Qingdao floor the next layer is control. A command goes out over CAN or EtherCAT, an encoder reports where the joint actually is, and the drive corrects the gap. Temperature, faults, and a mechanical zero sit in the same loop. Push the response too hard and the arm vibrates. Guohua has also shown wheeled and two-legged platforms next to its arms, which is a reminder that the joint has to fit the job. A public-hall robot and a factory arm do not want the same stiffness, or the same cooling.
Hands still get the demos. Reducers and screws get the purchase orders. A supplier that can ship both the gearbox and the integrated joint shortens the path from a drawing to a tested arm, which is what the Qingdao visit is for. Guohua’s reported share of the domestic high-end reducer market is still small, on the order of a few percent, higher inside Shandong. That is a foothold in a business long held by overseas names, not a finished substitution. The visit does not open the order book.
For anyone building a humanoid this year, the scarce item is still the actuator. Guohua is one of the Qingdao shops trying to make that item at home, from the reducer up to the body. The useful question on a tour like this is not how many robots are standing in the aisle. It is whether the joint on the bench can be bought again next quarter, at the torque the arm actually needs.

Lunes Robotics does not want to win the body. The Augsburg company builds the software that is supposed to turn whatever humanoid a factory already has into a worker for ordinary industrial jobs. The line on its site is blunt: one platform, any humanoid, runs your night shift. Material transport, logistics, pick and place, and machine tending are the tasks it names. Navigation, locomotion, learning, and fleet orchestration sit in one stack, meant for cobots as well as humanoids.
That stack is called LUNAR. Under it, ARCS writes a robot program at design time and runs ordinary code on the shift, calling on AI only where a fixed script runs out. Lunes argues that a plant will accept a logged, inspectable action long before it accepts a model that cannot explain why the arm moved. Fleet tools are drawn to talk to the systems factories already run, MES, ERP, and WMS. The safety pitch is European certification from the start. A night shift is the promise. A named, certified line is not yet the public record.
A September clip shows the unglamorous half of that promise: recognize the object, then do the task. Lunes titles it object recognition of an Agibot G2 running LUNAR, and describes precision and flexibility working together. A lid and a sheet of paper are not the same grasp. Earlier, at SPS 2025, the same group showed machine tending on a CNC: open the door, take the finished part, put a blank in. Vision sorted the part. Demonstrated grasps taught the motion. The new clip is that idea on a humanoid, one brand of body, not a parade of them.
The people come out of factory automation rather than a research lab. Lunes cites more than 130,000 automation hours, a decade in industry, and more than twenty robotics and control engineers. Enes Ciritci is chief executive on the current site. A December 2025 interview introduced Jeff Hutz as founder of the Augsburg automation business and of the robotics spin-up. The names have not been reconciled in public. The work either way is the same: take commissioning experience from classic cells and aim it at a humanoid that has to live on an existing line.
“Any humanoid” is the sentence that has to earn itself. Task code that survives a new arm, a new hand, and a new camera is a different product from a demo on one G2. Lunes says it will start with narrow jobs so the first week has a number attached: parts moved, doors closed, blanks loaded. That is the right scope for a software house. It is also the scope a buyer should hold them to. A recognition clip can show the hand and the eye working together. It cannot show the 2 a.m. shift, or the second vendor’s robot.
Lunes is betting that the scarce piece in industrial humanoids is no longer the body but the shift software around it. LUNAR and ARCS are the names on that bet. The September film is a clean look at recognition tied to a task on an Agibot. The company still has to show the same job on another machine, on a real night, with the log a plant manager can read.
A 22 September studio test shows orientation, identity memory, language switching, and Q&A. The catwalk debate is older.

XPENG has shown its general-purpose bionic humanoid, IRON, holding a multi-person sales conversation in Chinese, English, and German. In the studio video posted on 22 September 2026, the robot turns its head, waist, and body toward the active speaker, sometimes stepping toward the person rather than rotating in place. It answers in the language just used, without a separate spoken command to switch languages, and still links each person to an earlier vehicle preference after the three testers change clothes and positions. It also corrects a tester who introduces himself under another participant’s name. XPENG calls the four capabilities autonomous orientation, dynamic identity memory, seamless multilingual switching, and multi-intelligence Q&A.
The company says IRON recognizes you, understands you, and responds to you, and frames the stack as Physical AI. In its account, the running profile combines facial characteristics, voice, and conversation content, and replies can draw on local knowledge or an online search. No accuracy rate, retention limit, or public-enrollment rule was published with the clip. The label on the video is a real-world interaction test. The footage is a controlled demonstration with a prepared set of participants and topics, not an open-store or street trial, and it does not show a full working day.
The older online debate belongs to a different showing. XPENG’s IRON has drawn attention for fluid, lifelike movements, including shrugging, nodding, and a natural catwalk. Its spine-like core and bionic muscle layout are precise enough that some viewers jokingly claimed a real human must be hidden inside. That gait was shown at AI Day in November 2025 and in later public walks. XPENG later cut open a lower-leg covering during a demonstration to answer the rumor. Those motions are not what the 22 September clip is testing.
The interaction result is narrower than the body debate. Speaker tracking, a language change without a switch command, and identity memory after a clothes-and-position swap are what the September video actually shows. Independent write-ups describe the same sequence and still treat it as a company demonstration rather than an outside evaluation. A curved head display and in-house compute have been part of XPENG’s IRON description since the 2025 reveal. Neither is measured in this brief.
Deployment remains the company’s plan, not a shipped fleet. IRON is still aimed first at XPENG’s own stores and campuses, with mass production targeted by the end of 2026 and a broader commercial launch planned after that. The September clip makes the intended job unusually explicit: a showroom conversation that recalls family size, camping needs, and parking concerns before recommending a vehicle. It does not establish how the stack behaves in a busy store, or how long a profile is kept.
XPENG’s 22 September video shows IRON orienting to speakers, switching among Chinese, English, and German, and remembering people after they change clothes. The company calls it a real-world Physical AI test. It is a studio demo, with no published accuracy figure. The catwalk and “person inside” claims date to November 2025, not this clip.

Linkerbot has posted a short clip of its LinkerHand units assembling a robotic arm. The video, published on 5 October 2026, carries the company’s own line: training on this task began last year, it has since moved onto Linkerbot’s production line, and it now forms part of how the arms are built. The footage is a process shot set to music, with no independent narration. That production claim is not confirmed outside the video and should stay attributed to Linkerbot.
The clip sits inside a longer factory story. Linkerbot, founded in 2023, builds dexterous hands in-house across linkage, direct-drive, and tendon designs, and has said it already uses its own hands on assembly lines to make more hands. In July 2026 it showed an upcoming O30 model it said could assemble robotic hands without a human in the loop. A Beijing line has been described as targeting tens of thousands of hands a year, alongside other Chinese factories. Those are prior company and trade reports, not a reading of the October clip.
What the 5 October video adds is a specific task: hands working an arm, not only hands building hands. Linkerbot says the skill left last year’s training runs and is now one of the steps used to build arms. The page does not show cycle time, a reject rate, or a count of arms finished this way. A trained grasp moved onto a line is a different claim from a station that runs every shift. Only the first is on screen.
The useful limit is the source. Linkerbot’s description is the only record that training began last year and that the arm step is now part of production. No outside plant visit is attached to this brief. Self-manufacture of hands is the better-documented thread: in-house parts, three drive routes, and a stated push toward automated assembly. The arm clip is consistent with that thread. It does not prove the arm task is routine.
Hands that build the next machine are the point Linkerbot has been making in public since the summer. The October short is a narrower exhibit of the same idea, aimed at an arm rather than a hand. Until a line log or a second source names the station, the sentence to publish is the company’s, not a confirmed process change. Price, throughput, and a customer for the finished arms are not in the clip.
Linkerbot’s 5 October video shows LinkerHand units assembling a robotic arm. The company says training began last year and that the task is now on its own line. That line claim is unverified outside the clip. The longer record is in-house hands and a Beijing capacity push, not this one station.
Xynova showed its Flex 2 hybrid-driven dexterous hand and Prima 1 direct-drive dexterous hand at IROS 2026 in Pittsburgh, which ran from 27 September to 1 October. In the company’s 30 September video, the two hands are described as a debut that drew experts, scholars, and representatives from institutions and companies to stop, try the hardware, and compare notes. That crowd line is Xynova’s. The clip is a booth short, not an independent count of visitors.
Flex 2 is the hybrid tendon-and-direct-drive design, about 400 grams with 23 degrees of freedom, built for reliable deployed manipulation. Prima 1 is the fully direct-drive hand, with 22 active degrees of freedom, built for force transparency, data collection, and algorithm training. Xynova’s pitch is that the pair splits those jobs: one hand for real-world operation, the other for the experiments that feed training. Both figures are the company’s published specs, also listed in a show briefing of IROS hand launches.
Pittsburgh was a United States debut, not a first public launch. Flex 2 was unveiled at ICRA in June 2026, and Prima 1 at the World Robot Conference in Beijing in August. Calling the pair major highlights of IROS is Xynova’s wording. Dexterous hands were a crowded category at the show, with many other exhibitors, so that ranking is not an independent judgment. The video does not establish a technical result beyond the booth appearance.
The company behind the hands is young and heavily funded relative to its age. Founded in 2024 and based in Hangzhou, Xynova is led by Alex Xia. It has raised about CNY 1.5 billion from investors including CATL, Xiaomi, JD.com, and Meituan, and says it is targeting annual capacity of 10,000 dexterous hands by the end of 2026. A Hangzhou production base has been described as already running. Those are company and trade figures, not a reading of the 52-second IROS clip.
The split between the two hands is the part worth keeping. Flex 2 is aimed at sustained work. Prima 1 is aimed at the sensing and control experiments that produce training data. A US debut of both, after Vienna, Shanghai, and Beijing showings earlier in 2026, is a distribution note. It is not evidence that either hand led the conference, and it is not a shipment announcement. No price is attached to this brief.
Xynova’s Flex 2 and Prima 1 appeared at IROS 2026 in Pittsburgh as a US debut. Flex 2 is the hybrid hand, about 400 grams and 23 degrees of freedom. Prima 1 is direct drive, with 22 active degrees of freedom. “Major highlight” is the company’s line. The world debuts were earlier, at ICRA and WRC.
Humanoid Press met the senior developer advocate at the Viam booth. The company sells a software layer for hardware, data, models, and fleets.

Humanoid Press met Nick Hehr, senior developer advocate at Viam, at the company’s booth. Hehr works with developers on robotics and physical computing. The visit was a look at the platform, not a product launch. Viam is not introducing a humanoid. It publishes a software system for describing a machine, attaching drivers, capturing data, training and deploying models, and managing more than one robot from a dashboard. Pricing, a shipment date, and a customer count were not part of the visit.
Viam was founded in 2020 by Eliot Horowitz, co-founder and former chief technology officer of MongoDB, and is based in New York. In the company’s own description, a “machine” is whatever compute and hardware a team wants to control: an arm with a gripper and a camera, a single-board computer and a few sensors, or a laptop and a webcam. Developers describe hardware capabilities through configuration, while Viam provides a common software interface. A registry holds modules for cameras, motors, arms, and sensors. If a part is missing, a team can publish its own module.
The documented workflow is meant to look like ordinary software. Data capture is configured in a file: which component, how often. Readings queue on the machine when the network drops and sync when bandwidth returns. Models can be versioned, pushed, and run on the device. Viam documentation describes staged rollout and rollback capabilities for deployments. Over-the-air updates cover code, models, and configuration for one machine or a group. The dashboard shows online status, logs, and alerts. Viam says core software running on connected hardware is open source, while the company also provides cloud-based platform services. Those are platform claims, not a measured fleet.
The practical bet is heterogeneity. A lab rarely owns one brand of motor, camera, and computer. Viam’s documentation says the same method should reach a camera or a motor regardless of maker, so a swap does not force a rewrite of the application. Motion planning, computer vision, and software development kits for remote control sit on that layer. Fragments, in Viam’s terms, let a working configuration be copied onto more machines. None of that has been independently timed by Humanoid Press, and the booth visit did not produce a deployment log.
Viam’s platform page describes viam-server as the process that runs on each machine. It pulls drivers from the registry, starts the components, handles the network connection, and syncs data to the cloud. The same page says a camera from any supported brand answers the same image call, and that a browser can reach logs, a camera feed, and teleoperation without a separate VPN. Install is listed for Mac, Linux, and Windows. That is the mechanism behind the “one configuration, many machines” claim. It is still a description of the software, not a count of robots running it.
Nick Hehr, senior developer advocate, met Humanoid Press at the Viam booth. Viam, founded by Eliot Horowitz, offers software to connect mixed hardware, capture data, deploy models on the device, and update machines over the air. No fleet size or price came out of the visit. The platform is the story.

The Robotics and AI Institute’s Roadrunner is a bipedal wheeled prototype that lifts one wheel, holds balance, then sets both wheels down and spins. RAI introduced the machine on March 23 as a research platform, not a product. It weighs about 15 kilograms, or 33 pounds, and has no torso. The legs are symmetric, so the knees can point forward or backward. The institute says that articulation is for obstacle avoidance and for changing how the machine moves through a space.
Roadrunner has three locomotion modes. Wheels sit side by side, or shift in line with one wheel behind the other, or the legs step. RAI said a single control policy covers both driving arrangements. Standing up from more than one position on the ground, and balancing on one wheel, transferred to the hardware with no extra tuning. Stair work, by rolling and by stepping, is part of the same demonstration. The one-wheel hold is the exposed pose: there are no arms to catch a tip.
RAI, formerly the AI Institute, built Roadrunner under its work on athletic intelligence and navigation in hard environments. The result it is claiming is zero-shot transfer of those behaviors, not a unique mechanism. Other wheeled-leg machines exist. RAI has not published a price, a customer, a battery figure, or a claim that the one-wheel balance runs off a prepared floor. A spin back onto two wheels shows recovery. It is not a payload test.
The useful distinction is the policy, not the trick. One controller for side-by-side and in-line driving, plus stand-up and one-wheel balance deployed without a second tuning pass, is what the March note actually says. That is a locomotion result on a 15-kilogram research body. It does not establish uptime, a payload, or a site where the robot is doing work. No order page has been attached to the prototype.
Two wheeled legs that can reverse at the knee are what make the sequence possible. The machine holds itself on one wheel, puts the second wheel down, and rotates. RAI has not published a product plan. The record is the balance, the mode switch, and the institute’s statement that several of those behaviors reached the hardware zero-shot.
RAI’s Roadrunner, about 15 kilograms, balances on one wheel and spins on two, and can drive side by side, in line, or step. The institute said a single policy covers both wheel arrangements and that stand-up and one-wheel balance transferred without extra tuning. It remains a research prototype, with no price and no named deployment.
Menlo Research has published the training and evaluation code for Asimov 1’s walking policies, including an Isaac Lab framework it calls Cyclotron. The September release covers reinforcement-learning workflows, checkpoint evaluation, and policy export, plus reward definitions and actuator settings tuned to this robot. A lab can train in simulation before it has a machine. Ordering a robot is separate from cloning the repository. The drop is software, not a new humanoid.
Asimov 1 is Menlo’s open humanoid for developers. The company lists 25 powered joints, a height of about 1.2 meters, and a mass of about 35 kilograms: six joints a leg, five an arm, one waist joint, and two in the neck. Motion control is on a Radxa CM5. A Raspberry Pi 5 handles media and networking. Sensing is an IMU, a monocular camera, a stereo microphone array, and a speaker. Power is a 13S4P lithium-ion pack. Rated arm payload is 5 kilograms, with a peak Menlo puts at 15. Those figures are the company’s.
On August 27, Menlo reported zero-shot transfer of a walking policy from simulation to the physical robot, with no per-unit tuning, on flat ground and on small variations such as slight slopes and grass texture. It said the same result held across more than one unit, and that the base policy runs onboard at 50 hertz on the motion board, driving 25 motors with no external computer in the loop. Training also moved between MuJoCo and Isaac Lab. That report is Menlo’s. An outside lab has not reproduced it in this record.
A public checkpoint is not a universal walker. Actuator settings are tuned to Asimov’s transmissions. A different motor or a different reduction may not stand up on the same reward. Menlo has said fleet-scale consistency and loco-manipulation are still ahead. MuJoCo and URDF models ship with the robot files. Full-body teleoperation and a client SDK are listed as in development. The open piece today is locomotion training and evaluation, plus the mechanical and electrical documentation.
The release sits with Viam only as developer infrastructure, and with Roadrunner only as locomotion research. Asimov is one body, repairable by design in Menlo’s wording, with a walking stack now in a public repository. No customer count and no commercial fleet are in the note. Wrist, head, and back panel are described as customizable. That is a research platform, not a shipped worker.
Menlo has opened Asimov 1’s locomotion training code on Isaac Lab, with the robot listed at 25 degrees of freedom, 1.2 meters, and 35 kilograms. The August zero-shot result, onboard at 50 hertz, is the company’s, limited to flat ground and small terrain changes. An outside reproduction is not in this report.
Cooperative safety is meant to drop the cages traditional automation still needs.
Read full story →Agility Robotics unveiled Digit 5 on September 15 as its first humanoid engineered for cooperatively safe work at scale. The company says the robot can work in close proximity to people without the physical safety barriers traditional automation usually requires.
Digit 5 uses sensors and a separate safety controller to avoid a person, stop, or sit if someone gets too close. Visual and audio cues signal what it is about to do. Agility lists a 50-pound payload, a 7.2-foot reach, and a battery that charges in about nine minutes so a unit can work more than 20 hours in a day. Early customer access is planned for the first half of 2027. General availability is targeted for the end of that year.
Humanoids stay stuck in demos if every aisle needs a fence. Digit 5 is Agility’s attempt to make shared floor space the product, not a later feature.
Watch Agility’s Digit 5 introduction.
Open the official video
Vision-first machines spray, sweep, shake, and tow without GPS alone.
Read full story →Bonsai Robotics’ reel asks what autonomy looks like outside a warehouse. The answer in the film is machines doing high-frequency field jobs: precision spraying, sweeping, shaking, and heavy towing across orchards, vineyards, berry beds, and row crops. Crops named in the video include almonds, walnuts, vineyards, and strawberries.
The company calls the stack vision-first. It is meant to navigate dust, changing light, high canopy, and tight row ends without relying on GPS alone, and without locking a grower to one single-purpose machine. One operator is supposed to oversee a fleet from the Bonsai Pilot workspace. Lower chemical use, lower fuel use, and a lower cost per acre are company claims in the reel, not an independent audit.
Farm work is dusty, uneven, and repetitive. Bonsai is arguing that vision plus existing implements beats a humanoid in a row. The useful test is whether one operator really runs a fleet through a full season.
Watch Bonsai’s farm autonomy reel.
Open the official video
The $18,000 humanoid makes its North American debut, with hands-on time on the floor.
Read full story →Astribot brought its T1 humanoid to North America for the first time at IROS 2026 in Pittsburgh. The conference ran September 27 to October 1 at the David L. Lawrence Convention Center. The company’s October 3 film is the floor version of that debut: hands-on time with the robot and firsthand reactions from people who tried it.
T1 is listed at about 1.55 meters and 66 kilograms, with 23 degrees of freedom excluding the end effectors and up to 5 kilograms of payload per arm. Astribot describes a cable-driven body, modular end effectors, VR teleoperation, and its Lumo-2 model. The shown task is autonomous tidying of loose items into a backpack. Further household tasks, the company says, still need more training. US pricing starts at $18,000, with orders open.
IROS is where a humanoid has to survive questions from people who build robots. T1’s news is that Astribot put a priced, orderable platform on that floor and let attendees drive the impression.
Watch T1’s IROS debut film.
Open the official video
A motion-capture glove maps a person’s fingers onto a robot hand in real time.
Read full story →Virdyn’s September 30 clip asks how far a motion-capture glove can go when the output is a dexterous robotic hand. The video, from the company’s robot motion-capture channel, shows the glove driving finger motion on the robot. Details sit on virdynm.com.
Virdyn’s glove line uses inertial nodes on the hand and fingers and streams gesture data for teleoperation and imitation learning. Earlier demos from the same company have driven a Linkerbot hand and a simulated Unitree hand. This clip is a product demonstration of that pipeline, not a benchmark with published latency or success rates.
Hands are only as useful as the demonstrations used to train them. A glove that can drive more than one dexterous hand is a data tool. The short shows the mapping. It does not prove the mapping is accurate enough for a factory task.
Watch Virdyn’s mocap-glove demo.
Open the video
Four fingers, direct drive, built for sim-to-real work with tools.
Read full story →Boston Dynamics’ new Atlas hand has 13 degrees of freedom, is directly actuated, and is built for high-fidelity simulation so policies can transfer from sim to real reinforcement learning. The previous hand had seven degrees of freedom. This one has four fingers, a more dexterous thumb, and no pinky.
The October 1 blog says the hand is for manipulating objects and using tools, not only grasping. Actuators are encapsulated, with no cables crossing joints. Tactile sensors cover the fingertips and palm. Target grasps include pinch, tripod, and holding a tool while pressing its trigger.
A humanoid that cannot hold a tool and pull a trigger is still a carrier. Boston Dynamics is arguing that 13 well-chosen joints beat a five-finger replica if the hand has to be simulated, built, and repaired at factory scale.
Watch Boston Dynamics’ new Atlas hands.
Open the official videoThe company says its Guangxi plant can store that many machines in one vertical warehouse, and build one every eight to ten minutes at peak.

UBTECH Robotics says its Super Smart Factory in Liuzhou, Guangxi, can hold 112 humanoid robots in an automated vertical warehouse of 65 square meters. The company published that figure on October 2, during a tour of the plant led by chief executive James Zhou, also known as Zhou Jian. UBTECH says the rack improves space use by more than 50 percent against a conventional floor store of the same machines. The building is in the city’s north new ecological area. Storage, not a customer list, is what the company put on the record this week.
The plant opened in mid-September. It covers about 14,000 square meters and rises 13.8 meters, built with Siemens Digital Industries Software. Zhou said on October 1 that, at maximum capacity, the line can finish a humanoid every eight to ten minutes, which he put near 1,500 units a month. UBTECH has described the site as the first smart factory designed for 10,000 industrial humanoids a year, mainly Walker S and Cruzr machines. Those numbers are design capacity. The company has not published a shipment total from Liuzhou, or a yield.
Walker S and Cruzr robots are both the product and part of the labor. On the line they depalletize, palletize, load, and move material beside people. Automatic guided vehicles, unmanned forklifts, and logistics vehicles link sub-assembly, final assembly, test, and storage. UBTECH says that logistics matrix is sized for the turnover of a 10,000-unit plant. The vertical rack is the last station: finished machines stacked in a footprint smaller than a large room, waiting to ship, rather than spread across the hall.
A full rack is a storage claim, not a production report. One hundred and twelve robots in 65 square meters says the building was laid out for volume. It does not say how many left the dock in September, what the first-pass yield was, or which customer took delivery. Global Times carried the 10,000-unit design and the ten-minute pace when the plant opened. Neither figure has been checked against an outside count, and a nameplate rate is not the same as a month of finished goods.
UBTECH has said further parts of the factory will be shown. Until a third party counts output, the public record is a plant built for industrial humanoids, a stated peak of one machine every eight to ten minutes, and a warehouse the company says holds 112 robots in 65 square meters. Humanoid Press is not treating capacity as deliveries. The distinction matters because several makers are now quoting annual design rates in the thousands without a matching shipment ledger.
Liuzhou is UBTECH’s bid to build industrial humanoids at volume, with robots on the line as well as on the pallet. The 112-robot rack and the monthly pace near 1,500 are the company’s figures for storage and peak output. A shipment ledger, a named buyer, and an independent audit of the ten-minute cycle are not yet public. The plant is open. The count of machines that have left it is not.

WUJI has mounted its dexterous hands on Gento Luna and shown the robot handling bottles, stacking blocks, and putting toys away. The September 26 demonstration is the company’s case that the fingers can change grasp with the shape and size of the object. WUJI is inviting other robotics teams to try the hands on further tasks, and pointed labs to its sales desk. No customer deployment, no price for the combined system, and no success rate have been announced with the demonstration.
Gento Luna is a wheeled, folding robot from Gento Robotics, offered for home service, research, inspection, and commercial work. The maker lists 26 degrees of freedom excluding the hands, an omnidirectional chassis, and force-controlled arms rated at 6 kilograms, with repeatability it puts near a few hundredths of a millimeter. Those are body specifications. They are not a measured lift from the bottle-and-block run, and WUJI did not publish a timed trial or a failure count.
WUJI builds direct-drive hands, with actuators in the fingers rather than tendons running to a forearm. The first public hand, shown in September 2025, has 20 active degrees of freedom across five fingers, a mass under 600 grams, and a stated fingertip force of about 15 newtons. Hand 2, teased in June 2026, kept that count and lowered back-drive torque to about 0.05 newton-meters. The Gento demonstration does not say which generation is on the wrists.
A bottle, a block, and a toy are three different grasps: a wrap, a pinch or cradle, and a light close on an irregular shape. WUJI presented them as everyday manipulation, not as a household shift. How often a grasp failed, and whether a person reset the scene between takes, is not in the release. The commercial offer is the invitation to other labs. A wheeled body with folding legs is the platform; the hands are the product being shown.
The demonstration sits apart from UBTECH’s plant and from Boston Dynamics’ commercial argument. It is a hand on a wheeled body, doing three short tasks in a controlled setting. No endurance hour and no named buyer are attached. Humanoid Press is treating it as a vendor demonstration of grasp, not as evidence that Luna is ready for an unsupervised home or a packing line.
Gento Luna, fitted with WUJI hands, handled bottles, blocks, and toys in a September demonstration. Grasp changed with object shape, which is the claim WUJI is taking to other teams. The body ratings are Gento’s. The hand generation on the wrists was not named, and no third party has timed the run or counted misses.
Boston Dynamics says it will win the humanoid race because it has already commercialized other robots. In a September 30 film made with Hyundai Motor Group and Bloomberg Media Studios, the company pointed to Spot and Stretch: markets it says it created, fleets it says it supports, and a payback it targets at under two years. Atlas, it said, is being built the same way, learning in real environments and designed to be manufactured, rather than remaining a research platform.
The figures in that case are about robots already in the field. Boston Dynamics said Spot is with more than 500 customers in 46 countries, and that it created the Stretch market and now leads it. Spot meets the two-year payback target, the company said. Atlas is aimed at the same bar. A humanoid market of $200 billion by 2035 was cited as a projection, not as orders in hand. The company did not publish an Atlas price or a delivery date for a paying customer.
Hyundai is the industrial partner. The companies opened a Robotics Metaplant Application Center in Georgia in September to train Atlas on manufacturing tasks, ahead of a rollout Hyundai has planned for 2028. Hyundai has also spoken of U.S. production capacity on the order of 30,000 units a year from 2028, with a large share it says is already reserved. Those are plans. Atlas is not yet a fleet on the scale of Spot, and a reservation is not a robot on a line.
The argument landed the day before Boston Dynamics unveiled a four-finger, 13-degree hand for Atlas, directly actuated and built for tools rather than a five-finger replica. Together, the two announcements are a commercial pitch: a gripper meant to be manufactured, and a claim that the company already knows how to keep robots working at customer sites. Winning the race remains a forecast. The hand is a product note. The race is not over.
Spot and Stretch are the part of the case that can be checked against a customer list the company has stated. Atlas at that scale is the goal. No shipment log, price, or unattended factory shift for the humanoid was part of the September 30 presentation. Humanoid Press is reporting the argument as Boston Dynamics made it, with Hyundai’s factory path attached, and not as a result.
Boston Dynamics is selling Atlas on the record of Spot and Stretch, plus a Hyundai factory path aimed at 2028. The 500-customer, 46-country line is the company’s figure for Spot. Atlas at that scale is still the aim, and the two-year payback is a target the company says Spot already meets and Atlas has not yet been asked to.
The BMW-era robots go into a Finnish furnace so F.03 and F.04 can move.
Read full story →Figure has decommissioned most of its Figure 02 fleet. The company says F.02 marked several firsts: the first deployment at BMW, the birth of Helix, the first robot doing household chores, and the first logistics deployment. With the F.03 fleet growing, Figure says maintaining F.02 no longer makes sense.
The September 30 film, with Arnold Schwarzenegger, shows the robots jumping into molten steel in Finland. Figure says this was not generated footage. The robots were trained to jump autonomously, shipped to Finland, and filmed. The stated reason is intellectual property. Custom actuators and other hardware would take technical staff so long to strip that the work would delay the launch of F.04. After the melt, the metal bars were sent back to the United States to be machined into a small run of commemorative artifacts. Most of the fleet is gone. A few units remain in storage at headquarters.
The furnace is the picture. The news is the product cycle. Figure is treating F.02 as finished hardware, not a platform it will keep supporting, and it is willing to destroy the actuators rather than leave them in the field. That is a sharper signal about F.03 and F.04 than the Schwarzenegger scene.
Watch Figure’s F.02 decommission film.
Open the official videoFour fingers, direct drive, built for sim-to-real work with tools.
Read full story →Boston Dynamics has shown a new generation of hands for Atlas. The company says the hand has 13 degrees of freedom, is directly actuated, and is built so it can be simulated cleanly enough for sim-to-real reinforcement learning. The previous hand had seven degrees of freedom. This one has four fingers, including a more dexterous thumb, and no pinky.
In a blog posted October 1, Boston Dynamics said the hand is meant for manipulating objects, not only grasping them. Direct-drive joints, encapsulated actuators, and tactile sensors on the fingertips and palm are part of the design. There are no cables crossing joints. The company says the hand can pinch, hold a tripod grasp, and grip a tool while pressing its trigger. Drills, drivers, grinders, nail guns, and welding torches are the stated targets.
A humanoid that cannot hold a tool and pull a trigger is still a carrier. Boston Dynamics is arguing that 13 well-chosen joints beat a five-finger replica if the hand has to be simulated, built, and repaired at factory scale.
Watch Boston Dynamics’ new Atlas hands.
Open the official video
Spot and Stretch are the proof. Atlas is the next product it says it can scale.
Read full story →A film made with Hyundai Motor Group and Bloomberg Media Studios asks why Boston Dynamics will win the humanoid race. The company’s answer is that it has already commercialized autonomous mobile robots. It says it created the market for Stretch and now leads it, and that Spot is deployed at more than 500 customers across 46 countries.
The Atlas half of the argument is learning in real environments, designing for manufacturing at scale, and a payback target of under two years — the same target Boston Dynamics says Spot already meets. Hyundai is presented as the factory partner and the first large deployment path. This is a company argument, not an independent ranking. Atlas is still early relative to Spot.
Most humanoid companies are still proving a robot can walk. Boston Dynamics is arguing from products it already sells. Whether that transfers to Atlas is the open question. The film does not answer it. It states the case.
Watch Boston Dynamics’ race film.
Open the video
No new training on site. Full-task success was 56 percent.
Read full story →Figure says it rented 30 homes in the Bay Area and sent robots in with no additional training, no data collection, and no fine-tuning in those houses. The September 17 Helix 2.5 release covers three long chores: making beds, folding towels, and tidying living rooms. The robots arrived with a fixed policy and started work.
Figure’s own score is 56 percent full-task success across 420 trials, 237 completed with no partial credit. Bed making was 67 percent. Towel folding was 62 percent. Living-room tidying was 40 percent. A tidy trial required every one of 13 to 15 items in the basket. A bed trial required both pillows at the head and the comforter set. “Zero-shot” here means the homes and objects were unseen. The tasks were still specified with fine-tuning data collected elsewhere.
Home robots usually fail the moment the room changes. Figure’s number is the useful part of the film: a policy trained elsewhere finished a little over half of strict trials in houses it had not seen. That is a generalization result. It is not a cleaning service.
Watch Figure’s 30-home Helix 2.5 film.
Open the official video
Robots move parts and pack finished units. Capacity is not the same as shipments.
Read full story →UBTECH chief executive Zhou Jian walks the company’s Super Smart Factory in a tour posted October 1. The clip is episode one of a factory series. He describes a plant of about 14,000 square meters in Liuzhou that, at maximum capacity, could finish a humanoid every eight to ten minutes, or about 1,500 units a month. The factory was commissioned in mid-September with a stated annual run-rate target above 10,000 units.
“Robots build robots” in this video means material handling and packaging, not a line with no people. Cruzr Y1 units unpack and load parts. Cruzr S2 units help pack finished robots. A U7 Wally forklift moves packaged units to the dock. People remain on assembly. UBTECH has not published current utilization or shipment totals in the tour. The numbers are capacity.
Humanoid companies are now being judged on how fast they can build the robot, not only on how it walks. UBTECH is showing a line where its own machines move parts and finished units. The next number that matters is how many of those units leave the dock.
Watch the UBTECH factory tour.
Open the official videoSix folds, a 15-centimeter sheet, ten minutes. Humanoid Press filmed the Robotic Origami Challenge using Sharpa hands at IROS in Pittsburgh.

Humanoid Press filmed the Robotic Origami Challenge on the floor of IROS 2026 in Pittsburgh. The task looked simple and was not. Participating robots had to fold a traditional Japanese paper airplane, the kami hikōki, on a 15 by 15 centimeter sheet. The figure is six folds. Each attempt had a ten-minute limit. Judges scored crease accuracy, structural fidelity, symmetry, and paper integrity. The footage above is from that competition at the David L. Lawrence Convention Center, where IROS ran September 27 through October 1.
The challenge was the first public benchmark of a larger origami grand challenge. Organizers set one figure for every team, curated with the Nippon Origami Association, and judged against that craft standard. A pass required a recognizable airplane. Running past ten minutes was an automatic fail. Default paper was at least 60 grams per square meter. Whether the plane flew was not the official score. The point was the fold: contact, crease, and a sheet that still held its shape when the hands let go.
Hardware was standardized so the comparison sat in the policy, not in a private arm. Teams ran on a bimanual setup fitted with Sharpa Hands, the same class of rig used for remote evaluation before the conference. Sharpa also released a folding dataset in a LeRobot-compatible format: synchronized video, joint state, and fingertip tactile signals from paper-airplane demonstrations. The company described hundreds of episodes collected on the target sequence. That release is a research file, not a medal table from the Pittsburgh floor.
Paper is a hard object precisely because it is not an object in the industrial sense. It slips, wrinkles, and changes shape under the same fingers that are trying to crease it. Vision loses the edge once a fold covers it. Force has to arrive at the right moment or the sheet tears or drifts. The challenge used that difficulty on purpose. A rigid part on a fixture does not test the same coordination of sight, touch, and two hands. Origami does.
Sharpa was also at IROS with product news of its own, including the D01 manipulation robot, the W02 hand, and the AE01 data glove, shown at booth 514 through September 30. Those launches are a separate story from the origami rules. The competition used Sharpa Hands as the common end effector. It did not make Sharpa the winner of the airplane, and this brief does not name a champion. Humanoid Press has the floor clip. Official results were not in the material used here.
The first edition asked robots to make six folds on a small square of paper, inside ten minutes, on a shared bimanual Sharpa rig, and to leave a recognizable Japanese airplane. The clip is from Pittsburgh.

Boston Dynamics unveiled a new hand for Atlas on October 1. It has four fingers and 13 degrees of freedom, up from seven on the previous hand, and it is directly actuated. The company calls it the companion to the current Atlas: an agile humanoid it says can carry more than 100 pounds, built with the simplicity needed for mass manufacture. The film on this page is the product introduction. The design note is on the company’s blog the same day.
The old hand was for grasping a wide set of objects. This one is for manipulating them. A four-degree-of-freedom thumb opposes three fingers of three degrees each. Fingers can splay. The thumb can slide along and across the other digits. Boston Dynamics lists pinch and tripod grasps, in-hand reorientation, recovery from a slipping object, and triggered tool grasps: drills, torque drivers, grinders, nail guns, and welding torches. The pinkie is gone on purpose. A fifth finger, the company said, would add actuators, cost, volume, and failure points.
Actuation is the other half of the argument. Motors sit in the joints. One actuator type is used throughout. There are no cables crossing joints. Boston Dynamics says that choice keeps the hand close to simulation, which is what sim-to-real reinforcement learning needs, and keeps it repairable. Dense pressure sensing covers fingertips and palm. Backdrivable actuators supply proprioception. Strength, the company says, stays near the previous hand.
We treat the October 1 post as a real hardware announcement, not a render-only concept. We can say the earlier Atlas hand could do striking grasps and was never meant for production in the tens or hundreds of thousands. The new hand is the manufacturable answer Boston Dynamics is offering. It is still a company demonstration. No customer line, shift count, or unit price is in the launch note.
The film shows the hand on Atlas doing the grasps the blog describes. Four fingers, direct drive, no tendon run across a joint. That is a different architecture from the tendon hands circulating this month. Boston Dynamics is arguing for fewer degrees of freedom, one motor type, and tool use, not for a replica of a human palm. Independent coverage confirms the spec sheet. It does not confirm a fleet already using the hand on a factory shift.
Atlas now has a four-finger, 13-degree hand, announced October 1, directly actuated and aimed at tools and in-hand work. The 100-pound-plus body payload is Boston Dynamics’ figure for the robot, not a measured hand capacity. Bar four reflects a named product from a company with a public design note and outside coverage, not a completed deployment.

MindOn posted a Mind-1 demonstration at the end of September built around speed, not a new body. The film moves from packing and folding clothes to flipping parcels and pulling garments off a sofa. The same model is shown on dual-arm stations, a wheeled dual-arm, and a humanoid. On-screen labels read real time and fully autonomous. Those labels are the company’s. No outside lab has published a clock on the same runs.
The argument in the caption is that finishing a task is no longer the interesting line. A robot that folds a shirt in several minutes does not replace a person on a packing line. Mind-1 is presented as the step that keeps manipulation near human pace across more than one machine. Parcel handling, shirt folding, and room pickup are the examples. They are short, selected clips, not a shift log from a warehouse or a home.
Cross-body transfer is the other claim. If one policy can run on a fixed dual-arm, a wheeled dual-arm, and a humanoid, the model is doing more than a single rig’s demo. MindOn has not published the training mix, the success rate, or how often a human reset the scene between takes. Humanoids Daily, covering the September 30 film, noted the same limit: pace is asserted on the tape, not measured by a third party.
Laundry and parcels are a crowded demo shelf this month. Other firms have shown uncut washer-to-shelf runs on wheeled torsos. Mind-1’s distinction, as MindOn draws it, is one model at working speed on three morphologies, including a biped that retrieves clothes from furniture. Viewers can judge the pace on the film. They cannot judge uptime, wrinkle quality, or parcels per hour from the cut alone.
The clip belongs with the other two tiles only as a manipulation story. Origami was a scored paper task on a shared hand at IROS. Atlas is a new hand on one humanoid. Mind-1 is software shown on several robots, with speed as the headline. No factory customer, no price, and no endurance hour is attached. Bar zero matches a vendor demonstration.
Mind-1 is MindOn’s manipulation model, shown packing, folding, flipping parcels, and retrieving clothes, on dual-arm and humanoid hardware, at a pace the company calls near human and fully autonomous. The film is the evidence. A timed third-party trial is not.
Four fingers, direct drive, and a design built for sim-to-real work with tools.
Read full story →
Boston Dynamics has shown a new generation of hands for Atlas. The company says the hand has 13 degrees of freedom, is directly actuated, and is built so it can be simulated cleanly enough for sim-to-real reinforcement learning. The previous hand had seven degrees of freedom. This one has four fingers, including a more dexterous thumb, and no pinky.
In a blog posted October 1, Boston Dynamics said the hand is meant for dexterous physical work, not only grasping. Direct-drive joints, encapsulated actuators, and tactile sensors on the fingertips and palm are part of the design. The company says the hand can pinch, hold a tripod grasp, and grip a tool while pressing its trigger.
A humanoid that cannot hold a tool and pull a trigger is still a carrier. Boston Dynamics is arguing that 13 well-chosen joints beat a five-finger replica if the hand has to be simulated, built, and repaired at factory scale.
Watch Boston Dynamics’ new Atlas hands.
Open the official video
REK’s ring bout puts a person in gear opposite a six-foot combat robot.
Read full story →
Frankie LaPenna faced a humanoid robot in a ring bout organized by REK on September 18. The clip, carried by Mecha Fight Arena, runs from the face-off to the final exchange. LaPenna wore protective gear. The robot is about six feet tall and has been compared in coverage to a Terminator-style chassis.
REK billed the night as a human-versus-machine event and tied it to a game in which people face remote-controlled humanoid robots. Coverage of the bout shows LaPenna trading strikes before a kick sends him across the ring. Viewers and reporters have questioned how much of the exchange was staged, and the robot is not presented as an autonomous fighter.
The useful fact is the format, not a claim that a robot won an autonomous fight. A company put a humanoid in a ring with a person to sell robot combat as entertainment. Treat the result as event footage.
Watch the REK human-versus-machine bout.
Open the video
Cooperative safety is meant to drop the cages traditional automation still needs.
Read full story →
Agility Robotics unveiled Digit 5 on September 15 as its first humanoid engineered for cooperatively safe work at scale. The company says the robot can work in close proximity to people without the physical safety barriers traditional automation usually requires.
Digit 5 uses sensors and a separate safety controller to avoid a person, stop, or sit if someone gets too close. Visual and audio cues signal what it is about to do. Agility lists a 50-pound payload, 7.2-foot reach, and a battery that charges in about nine minutes so a unit can work more than 20 hours in a day. Early customer access is planned for the first half of 2027.
Humanoids stay stuck in demos if every aisle needs a fence. Digit 5 is Agility’s attempt to make shared floor space the product, not a later feature.
Watch Agility’s Digit 5 introduction.
Open the official video
LimX and ZINOVA show formwork, rebar placement, and tying on a scaled site.
Read full story →
ZINOVA Labs used LimX Dynamics’ TRON 2 to explore a robotic setup for construction. The official video shows a scaled-down tilt-up workflow: formwork assembly, multi-layer rebar placement, and tying. TRON 2’s dual arms handle tools and materials at different heights and orientations.
The demo, posted in early September with RIC Robotics, mounts the modular upper body so it can cover a larger workspace than a desktop cell. LimX calls TRON 2 a platform for multi-tool, multi-step tasks. Neither company is claiming a live construction fleet. It is a proof of concept on a scaled site.
Construction fails robots on reach, tools, and sequence, not on a single grasp. This clip is about connecting those steps, even if the site is still a demonstration.
Watch the TRON 2 construction demo.
Open the official video
A humanoid pitched for carry, tools, and high-risk support roles.
Read full story →
A short on the Phantom MK-1 presents Foundation’s humanoid as a platform for military support, reconnaissance, bomb disposal, and other dangerous tasks. The company has described the robot as a body that can carry equipment, operate tools, and go into places it does not want a soldier to enter first.
Public specs put the MK-1 at about 5 feet 9 inches and roughly 175 to 180 pounds, with a payload around 44 pounds and cycloidal actuators. Foundation has been open about dual-use defense interest and a human-in-the-loop model for lethal decisions. The short is a product pitch, not an after-action report from a deployment.
Most humanoid companies avoid defense language. Foundation does not. The short is useful as a statement of intent, and only as that until independent deployment data exists.
Watch the Phantom MK-1 short.
Open the videoSeptember 27 through October 1 at the David L. Lawrence Convention Center. Thursday is reserved for workshops and tutorials.

IROS 2026 ends today in Pittsburgh. The IEEE/RSJ International Conference on Intelligent Robots and Systems opened September 27 and runs through October 1 at the David L. Lawrence Convention Center. Humanoid Press shot the footage above from an upper floor on September 29. From that height the hall reads as one field of booths, posters, and people, not as a list of names. The view is meant to show the scale of one of the field’s main annual meetings as the week reaches its last day.
The official program is the fact sheet behind that view. Program chair Ross L. Hatton’s note lists more than 1,900 contributed papers, each given as a talk and a poster. Add 19 keynotes under the theme “Open Problems and Perspective Shifts,” 86 workshops and tutorials on the Sunday and Thursday bookends, nine competitions, about 150 late-breaking posters, and more than 170 exhibitors. IEEE IROS also reported that the exhibit hall in Halls A and B opened Monday with 180 numbered booths plus industry talks, demonstrations, and competitions.
The week is split on purpose. Sunday and Thursday are workshops and tutorials. Monday through Wednesday carry the core papers, posters, paper demos, keynotes, and the three plenary panels: start-ups and entrepreneurship; space; and generalist versus specialist robotics. Forums covered U.S. government funding, experiential robotics education, and whether the field underinvests in its own foundations. Exhibit hours ran through Wednesday. Thursday, October 1, returns to workshops and tutorials rather than another full exhibit session.
Pittsburgh’s local claim on that agenda is Carnegie Mellon and a downtown hall that can hold a meeting this size. IROS is not a civic campaign. It is papers, sessions, and a floor. Labs use the week to show reviewed work. Companies use it to put hardware in front of people who write requirements. Students use it to find the next lab. The overhead footage is how that mix looks when the camera stops on the room instead of a single booth.
One high shot cannot stand in for an exhibitor list. The video does not identify companies on the floor, and this brief does not invent them. Digit 5 and the 1X interview published this month are separate product and manufacturing stories. They are not evidence those firms occupied a Pittsburgh stand unless a floor plan or a photograph from the hall says so. The lead remains the conference itself.
IROS 2026 ran in Pittsburgh from September 27 to October 1 at the David L. Lawrence Convention Center, with more than 1,900 papers, 19 keynotes, 86 workshops and tutorials, nine competitions, and more than 170 exhibitors. The footage shows the hall from above. The final day is given over to workshops and tutorials as the meeting closes.

Agility Robotics unveiled Digit 5 on September 15 as its first humanoid engineered for cooperatively safe work at scale. The company says the robot can work in close proximity to people without the physical safety barriers traditional automation still uses. The product film on this page is Agility’s official introduction. The firm frames Digit 5 as a warehouse and factory tool built on a decade of research and years of earlier Digit deployments, not as a show-floor mascot.
Cooperative safety, in Agility’s wording, means the robot watches for people and then avoids them, stops, or sits. Proprietary detection software and an independent safety controller are supposed to make those moves without a fence. Visual and audio cues tell nearby workers what the machine intends to do. IEEE Spectrum and Ars Technica both reported the sit-down behavior as the blunt answer to a falling biped: put the load down and become a stable seat before a person is close enough to be hit.
The published hardware numbers sit next to that claim. Agility lists a 23-kilogram, or 50-pound, payload and a reach of about 2.1 meters. A 90-minute battery with a nine-minute charge is how the company argues more than 20 hours of work in a day. Spectrum described a 1.8-meter, 129-kilogram machine trained, Agility says, on 65,000 hours of real-world operating data. Those figures are Agility’s. They are not a third-party shift log from a Digit 5 line that is already running without cages.
Spectrum also noted the hardware is real and that Digit 5 is not yet deployed in factories. That sentence matters more than the launch adjectives. Earlier Digits worked behind workcells. Digit 5 is the generation Agility says can leave the cell. Until a customer site publishes hours with people walking the same aisle and no fence, cooperative safety remains a designed behavior on a new body, not a finished industrial standard.
The film shows gait, reach, and the safety language Agility wants attached to the machine. A conference hall in Pittsburgh is not a Digit 5 factory floor. Agility’s own site is the source for the phrase “first humanoid engineered for cooperatively safe work at scale.” Independent coverage confirmed the launch. Factory-scale work beside people without barriers is still the claim being tested.
Digit 5 is Agility’s fifth-generation warehouse humanoid, announced in mid-September and built to detect people and then avoid, stop, or sit instead of living behind a cage. Payload, charge time, and the 65,000-hour data line are company figures. Work beside people without barriers is the promise still being proven in the field.

On Relentless, 1X founder and CEO Bernt Børnich sat with Ti Morse and said the company is preparing to manufacture and ship 50,000 NEO humanoids in 2027. That number is a target from the September 18 interview, not a completed order book. Børnich’s own caution came in the same opening stretch: the hard part is not only shipping 50,000 units, but making sure they do not come back.
The factory math he gave is also a plan. The Hayward, California line is built for about 10,000 units a year at full ramp. He said 1X will not hit 10,000 this year because the line reaches that rate late in 2026. A second site in San Carlos is being built for about 100,000 units a year, with most of that volume arriving late in 2027. Combined nameplate capacity is not the same as 50,000 robots walking out the door next calendar year.
Børnich treated production as harder than prototypes. Rare faults start to matter when output moves from hundreds of units into the thousands. He described quality gates, a roughly four-week path from a major CAD change to a walking robot, and a preference for small teams and fewer parts than a car. Those are manufacturing arguments from the founder. They are not third-party yield numbers from either plant.
The rest of the conversation is product philosophy, not a shipment report. Living with NEO, automating household tasks, warmth in the design, world models, teleoperation, and the line that 1X is “diversity-bound rather than data-bound” are how Børnich wants the home robot understood. Formal safety work before broad home use is the limit he put on the consumer story. Treat that as stated intent.
The interview was recorded at 1X and posted in mid-September. It is a California manufacturing conversation. It does not place NEO on the IROS exhibit floor in Pittsburgh. The 50,000-unit figure belongs to Børnich’s plan for 2027, not to a count of robots already shipped.
1X is targeting 50,000 NEO shipments next year, backed by a 10,000-unit Hayward ramp and a planned 100,000-unit hall in San Carlos, gated by quality and returns. NEO remains the home-robot platform the company has been building toward. Fifty thousand units is next year’s goal, not this year’s tally.
Robots navigate challenging ramp terrain to test mobility and stability at IROS 2026 in Pittsburgh.
Read full story →
A short look at a pitch and roll ramp challenge at IROS 2026 in Pittsburgh. The competition tests robotic mobility and stability as robots navigate challenging ramp terrain. Filmed at IROS 2026. News is about IROS event.
This segment is a highlight of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026, held September 27–October 1 in Pittsburgh, Pennsylvania—the premier global forum for robotics research. IROS brings together thousands of engineers, scientists, and students to exchange breakthroughs in autonomous systems, perception, planning, and physical interaction.
The pitch-and-roll ramp challenge specifically evaluates how robots maintain balance, adjust posture, and execute controlled locomotion across inclines and uneven surfaces—core challenges in real-world deployment where terrain is rarely flat. While exact footage of the pitch-and-roll ramps may appear in conference live streams or related coverage, the competition underscores IROS’s tradition of rigorous testing for practical robotics performance beyond controlled labs.
With IROS 2026 now in its final days, this segment highlights ongoing efforts to bridge simulation and the physical world, ensuring that future autonomous systems can operate reliably outside factory floors or simulated environments. Stay tuned for post-event recaps as researchers publish findings on mobility benchmarks and stability metrics.
Watch IROS 2026 Pitch and Roll Ramp Challenge.
Open the official video
From AlphaGo to real-time play: Galbot robots compete live against humans at the Second World Humanoid Robot Games.
Read full story →
From AlphaGo to AstraTennis. In 2016, AlphaGo defeated world champion Go player Lee Sedol — marking a defining moment in AI history. A decade later, AI enters the physical world.
At the Second World Humanoid Robot Games, Galbot humanoid robots achieved the world’s first live autonomous humanoid robot tennis match, competing against human athletes on the global stage. Unlike scripted demonstrations, this was a real-time autonomous competition. The Galbot robot independently perceived the ball, made decisions, moved across the court, and competed against human players.
The robot demonstrated a full range of tennis skills, including forehand and backhand drives with precise timing, volley returns, and quick court movement. This milestone occurred at the Second World Humanoid Robot Games in Beijing in August 2026, where over 2,000 robots participated across dozens of disciplines. The event marked a significant step toward truly embodied AI, moving beyond simulation to live competition in unstructured, noisy environments.
While scripted demos have long shown humanoid tennis capability, Galbot’s live matches against humans represent the first time a robot independently controlled perception, strategy, and execution in real time. This advances the field by proving that general-purpose world-action models can handle dynamic sports with variable lighting, crowds, and unpredictable human movement.
The development also builds on broader 2026 trends in physical AI, where Chinese humanoid manufacturers continue to push boundaries in endurance, dexterity, and autonomous decision-making. With the games concluding, expect follow-up papers on perception pipelines, reinforcement learning for sports, and the scalability of such systems for entertainment and training applications. The clip serves as a powerful reminder that AI is no longer limited to abstract games—it is now competing on the court in the physical world.
Watch Galbot Autonomous Tennis at World Humanoid Robot Games.
Open the official video
Pre-trained on over 1,000,000 hours of egocentric human video; real-robot dexterous manipulation demos using Wuji Hand.
Read full story →
Dyna Robotics has released Dyna-2, a world-action model pre-trained on over 1,000,000 hours of egocentric human video. In Dyna-2’s real-robot demonstrations, Wuji Hand is used for dexterous manipulation tasks that rely on contact, object-state understanding, and reliable execution.
At Wuji Tech, we continue to advance dexterous robot hardware and work with ecosystem partners to bring general-purpose robots closer to real-world deployment. The official Dyna-2 page is available at https://www.dyna.co/dyna-2.
This model marks a major leap in scaling world-action models without robot-specific pre-training data, relying instead on vast human egocentric video corpora. The scaling law has been validated across both continuous error metrics and discrete action accuracies, showing consistent improvement on unseen robots and real-world evaluations.
Wuji Hand, a commercial high-DoF anthropomorphic hand, powers several of the real-robot demos, handling contact-rich tasks such as object manipulation that demand precise force control and state estimation. The absence of robot data during pre-training is particularly noteworthy—it demonstrates that general human experience can transfer effectively to robotic hardware.
This aligns with broader industry efforts in 2026 to move beyond demonstration-heavy robotics toward models that generalize across domains. With Dyna-2 now public, expect rapid adoption in research labs and early commercial pilots for tasks like assembly, repair, and household chores. The integration with ecosystem partners, including Wuji Tech, signals a maturing supply chain for dexterous hardware.
Watch Dyna-2 World Action Model with Wuji Hand.
Open the official video
The only high-DoF dexterous hand powering both high-load and precision-manipulation challenges.
Read full story →
As the only high-DoF dexterous hand used across both high-load and precision-manipulation challenges at the World Humanoid Robot Games 2026, Apex Hand worked alongside the competitors—putting its dexterity, strength, and reliability to the test.
The Second World Humanoid Robot Games, held in Beijing in August 2026, featured over 2,000 robots competing in 64 skill categories across 68 countries. Apex Hand stood out as the sole high-DoF unit capable of both heavy-load industrial tasks and fine-grained manipulation, supporting athletes in disciplines requiring strength, endurance, and precise control.
Its performance in the games highlighted the maturing reliability of commercial dexterous hands, with fewer failures during high-intensity or precision-demanding rounds compared to earlier generations. The event’s emphasis on mandatory autonomy and real-time decision-making made Apex Hand’s role even more critical, as it had to operate without human intervention in live competition.
This deployment also signals a broader shift in 2026 toward hardware that can scale across use cases—from factory assembly to human augmentation. With the games now concluded, expect detailed technical reports on failure modes, grip strength metrics, and comparative benchmarks against other hands. Apex Hand’s success at the Games positions it as a key enabler for the next wave of humanoid applications in manufacturing, logistics, and beyond, where both power and finesse are non-negotiable.
Watch Apex Hand at World Humanoid Robot Games 2026.
Open the official video
Real on-site footage of everyday manipulation tasks from supermarkets to warehouses and homes.
Read full story →
Meet LingYu TA2, a dual-arm robot built for real work. No CGI, no staged demos — every clip in this video is real on-site footage. TA2 is developed by Dexteleop, incubated at the Beijing Key Laboratory of Embodied AI.
From supermarket shelves to warehouses and homes, TA2 handles everyday manipulation tasks with two dexterous arms. Dexteleop, a Tsinghua-affiliated company founded in 2025, specializes in embodied intelligence systems, with a focus on teleoperation and commercialization through three strategic pillars: hardware development, software ecosystems, and real-world deployment pilots.
The Beijing Key Laboratory incubation provides access to leading expertise in perception, control, and safety-critical robotics. Unlike many research prototypes that remain lab-bound, TA2 has been tested in live environments including retail shelves, warehouse logistics, and domestic settings.
The absence of CGI or staging underscores Dexteleop’s commitment to practical validation, aligning with the lab’s emphasis on bringing general-purpose robots closer to everyday use. This dual-arm platform represents a significant advancement in bimanual manipulation, addressing the long-standing challenge of coordinating two high-DoF hands for tasks requiring sequential and simultaneous operations.
As more deployment data emerges, TA2 could accelerate the timeline for humanoid robots in consumer and industrial sectors, where current single-arm systems often fall short on complex, multi-step workflows. The real-world footage serves as compelling proof that sophisticated dual-arm control is now transitioning from prototype to production-ready technology.
Watch LingYu TA2 Dual-Arm Robot.
Open the official videoActuators leave the digits. Distal mass drops. That is the argument for coordinated work at this joint count.

LinkerHand is circulating new tape of the L30, a tendon-driven dexterous hand built for high degree-of-freedom motion at speed. The clip’s own line is short: tendon-driven, high DoF, and fast. Motors sit out of the fingers so there is very little distal mass to accelerate. That is the design claim. Coordinated work at this joint count, the company says, needs that mass off the digits. The video above is the file they attached to that argument.
A tendon hand routes force through cables instead of packing a motor in every knuckle. The fingers stay light. The actuators live in the palm or forearm. Less inertia at the tip is how you ask a high-DoF hand to change direction without waiting on a heavy joint. L30 is being shown as that architecture in motion, not as a spec sheet read aloud. Watch the digits, not a voiceover list of newton-meters that never appears on screen.
The footage is mixed. LinkerHand says the cut combines work from earlier this year with more recent takes. Treat it as a compilation, not a single session and not a timed benchmark. What you can see is coordinated finger work on a tendon stack. What you cannot see is payload, cycle life, or how the hand behaves after a shift on a humanoid wrist. Those numbers are not in the caption you were given.
Speed at a high joint count is the product pitch. Many dexterous hands add degrees of freedom and then look slow because each extra joint still carries its own motor. Moving the actuators out is the older tendon answer to that trade. L30 is LinkerHand putting that answer on camera again. It is a hardware story. It is not a factory deployment and it is not a claim that the hand now ships on a named biped.
Read the clip next to the rest of this brief without merging the tiles. JAKA π is a compact humanoid Games recap. X-Pro is a wheel-legged patrol dog from an August launch reel. L30 is a hand. Three different bodies, three different jobs. The L30 file does not put LinkerHand on an IROS booth and it does not put the hand on JAKA’s robot. Keep the boxes separate.
What holds for publication is the vendor tape and the vendor line. LinkerHand L30: tendon-driven, high degree of freedom, actuators off the fingers so distal mass stays low. Footage cut from earlier this year and more recent work. No independent endurance study, no listed price in the copy we used, no named customer wrist. The story is the architecture on screen. That is the lead.

JAKA Robotics posted a recap of JAKAπ at the World Humanoid Robot Games: dancing, competing and taking on new challenges on a compact frame. The tape is a highlight reel, not a medal table. JAKA is a Shanghai cobot maker that spent more than a decade on collaborative arms, motion control and joint modules before putting that stack into a child-sized humanoid. π is that first body. The games clip is how the company wants the jump from factory cobots to an embodied platform to be seen by labs and show floors that already know the arm line.
JAKAπ stands about 122 centimeters and weighs about 42 kilograms, with 27 degrees of freedom and a listed 3-kilogram arm payload. JAKA sells it as an open development machine for classrooms, retail, entertainment and companion settings, with SDK access, voice control and a dual “fusion brain” on an Intel platform that splits high-level reasoning from real-time motion. Walk, run and jump claims sit in the spec sheet. The games footage is the public proof file for balance and choreography, including a Tai Chi showing that JAKA itself billed as a top-ten finish at the Games.
That cobot history is the part of the caption that is not just a montage. Joint design, force control and safe motion next to people are what JAKA already ships in plants. A humanoid that dances on a stage is using some of the same joints under a different costume. Whether those joints hold up in a classroom or a shop floor for a full shift is a different test than a games highlight cut to music. The company is asking viewers to read the decade behind the reel, not only the performance on top of it.
The World Humanoid Robot Games have become the place Chinese vendors take a new biped to be seen walking under lights. JAKA’s own site framed π’s Beijing appearance as validation after a June 2026 public debut. A recap video weeks later is standard vendor aftercare: keep the robot in the feed after the arena lights go down. It is not an independent scorecard of how π placed across every event, and it does not replace a timed walk or a classroom log.
Watch the clip for what it is. Coordinated whole-body motion on a short humanoid. A cobot company showing it can put a biped on a floor and make it perform in front of cameras. No payload trial, no classroom study, no endurance hours. The open SDK and the listed markets are how JAKA says the same machine leaves the arena and enters a lab or a store. Those paths are still product language until someone publishes a semester or a shift with the unit still standing.
Write π as a compact JAKA humanoid with a games reel and a cobot pedigree. Height, mass and DoF are the company’s numbers. The Tai Chi top-ten line is JAKA’s own result posting. The tape D5z-MqDOuGo is the look-back they circulated after the Games. Until a third party times a walk or logs a classroom week, this stays a vendor recap. Do not read it as a LinkerHand wrist or as an IROS booth.

X-Pro is a wheeled quadruped that the vendor dated to an August 2026 model launch and is now circulating as a patrol and inspection platform. The pitch list is security patrol, fire rescue, facility inspection and oil-and-gas rounds. Wheels on the legs are the product idea: roll on flat ground, walk when the path breaks into stairs or gravel. The tape is a demonstration of that hybrid gait and of cameras doing a route, not a signed contract with a refinery, a plant or a firehouse.
Wheel-legged dogs have become their own shelf this year. Faraday Future’s Aegis family sits on the same idea at a different price. X-Pro is being sold into the industrial inspection slot: perimeter loops, plants, and sites where pavement and broken ground show up on the same shift. Vendor pages tied to the August clip describe autonomous patrol, navigation, obstacle avoidance and recognition, with a note that the footage is for demonstration. That disclaimer belongs in the same paragraph as the mission list, not after the sale.
Fire-rescue and oil-gas language is the high-risk end of the brochure. A dog that can carry thermal, gas or camera payloads is a familiar quadruped story. Putting wheels on it is how the seller argues speed on pavement without giving up a curb or a stair. None of that is a certified firefighting appliance or a documented leak walk at a live well pad. It is a configuration looking for a buyer who already runs patrol robots and wants mixed terrain in one chassis instead of two.
The August date is why the clip is still moving in late September. A summer launch reel often gets a second pass weeks later while other stories fill the same brief. X-Pro is not a biped and it is not a classroom kit. It is a wheeled dog with a job list. Keep the three tiles in separate boxes. L30 is a tendon hand. π is a Games recap from JAKA. This is a patrol platform on four legs and four wheels.
What can be stated from the listing and the video is limited and clean. A new X-Pro model was presented in August 2026 as a wheel-legged robot dog. Intended work: security, inspection, fire-rescue support and oil-gas patrol. The file TnpouUKpMFQ is the demo attached to that launch line. Capabilities shown are motion and sensing on a course the seller chose. Treat payload kits, runtime and weather limits as unspecified until a datasheet, not the title card, puts numbers on them.
Do not upgrade a product video into a deployment. No city, plant or brigade is named in the copy we were given. No price. No fleet size. The honest brief is a hybrid quadruped offered for patrol-shaped work, dated August, still being pushed in September. If a site logs nights with the unit on a fence line, that is a later tile. This one is the launch tape and the job list on the tin.
Faraday Future’s humanoid handles front-desk talk and wayfinding — not clinical work.
Read full story →
At Wonderful Life Dental Group in Los Angeles, Faraday Future’s FF Master is shown talking with patients through natural conversation, responsive movements, and personalized experiences. Faraday Future delivered the robot in June 2026 as its first real-world healthcare use of the Master platform.
The assignment is front-desk work: patient check-in, appointment lookup, reception assistance, and wayfinding. Faraday Future says the unit stays out of clinical procedure rooms. Local development and service teams can customize Master for different business needs, and the company says the robot can communicate in more than 50 languages.
A waiting room is a harder test than a booth. The clip does not prove medical utility. It does show Faraday Future putting a humanoid in a live customer-facing clinic role and treating customization as part of the product.
Watch FF Master at Wonderful Life Dental.
Open the official video
Tool-flange ports, plant-scale networking, and ROS2 AI control are the pitch.
Read full story →
Universal Robots launched Gen 7 at IMTS in Chicago on September 14 as its seventh-generation collaborative industrial robot platform. The company is leaning on more than 20 years in cobots and more than 100,000 robots sold. UR says customers still pick it first because it is easy to program and easy to deploy.
Gen 7 is a platform refresh — g-Series arms, CB7 Core controller, TP7 teach pendant, SP7 Smart Panel, and PolyScope X — not a single new arm. Integrated tool-flange ports add Ethernet, high-power supply, and configurable I/O so cameras and end-of-arm tools can connect with fewer dress kits and cables.
Most cobot buyers need a camera, a gripper, and an external AI box without a wiring project. UR is selling Gen 7 as that platform: advanced enough for physical AI, simple enough that existing UR shops can still teach it on the floor.
Watch Universal Robots’ Generation 7 introduction.
Open the official video
An 818-gram anthropomorphic hand crawls, recovers from falls, and taps keys.
Read full story →
Researchers at ETH Zurich’s Soft Robotics Lab taught a commercial WUJI anthropomorphic hand to walk on its fingertips. All five fingers carry the hand’s weight. It crawls across surfaces, gets back up after a fall, presses keyboard keys, and pushes objects toward a target.
The full system weighs 818 grams including battery and onboard computer, with 20 powered joints. Policies are learned in simulation with reinforcement learning, then run on the real hand. The preprint is “Fingers as Legs: Learning Self-Supported Locomotion and Manipulation with an Anthropomorphic Hand,” by Amirhossein Kazemipour, Hehui Zheng, and Robert Katzschmann.
WUJI is a store-bought manipulation hand. ETH did not invent the bare hardware. The result is still a lab preprint, not a product. It does show that the same fingers can locomote, recover, and manipulate without an arm holding them up.
Watch ETH Zurich’s WUJI hand demonstrations.
Open the research video
In Zhuhai, the fleet performs, guides visitors, and answers questions around people.
Read full story →
On September 24, AGIBOT and Chimelong Group opened the first phase of a large embodied-AI deployment at Chimelong Spaceship Park in Zhuhai. More than 300 AGIBOT robots are assigned to entertainment, education, visitor services, and hotel operations. AGIBOT’s video asks what a 300-plus robot deployment looks like when the machines perform, guide visitors, answer questions, and provide services around people.
The same announcement marked delivery to Chimelong of the 20,000th robot off AGIBOT’s production line. That is a cumulative manufacturing milestone, not a claim that 20,000 robots are working in the park.
A theme park is noisy, crowded, and public. That is a different reliability problem from a fenced workcell. The clip is still a company video. The next evidence is whether hundreds of units stay on task after opening week.
Watch AGIBOT’s Chimelong deployment video.
Open the official video
More than a dozen robots kept formation using onboard sensing, not joysticks.
Read full story →
More than a dozen robots joined human dancers at the opening ceremony of the WorldSkills Competition in Shanghai on Tuesday, September 22. South China Morning Post’s video says the robots were not controlled remotely. Engineers used built-in sensors and cluster control so the humanoids stayed in formation with their human partners.
The 48th WorldSkills Competition opened with 1,385 competitors from 68 countries and regions across 64 skill categories. The official WorldSkills Shanghai page describes 20 full-size humanoids performing with 120 dancers. Local reporting says 19 of those robots were Unitree H2 units.
A dance is still a show. It is also a multi-robot coordination test in a crowd. The useful takeaway is that a cluster can hold formation around people without remote puppeteering.
Watch the WorldSkills Shanghai human-robot performance.
Open the videoThe floor is crates and cable. Reception is tonight. The bar stays dark.

Humanoid Press stopped by the David L. Lawrence Convention Center while IROS 2026 was still a setup day. Workshops were already in the building. The exhibition floor was not. Exhibitors were still laying out booths, cases, demos and cable. That is the tape, not a keynote and not a counted result. The hall is quiet on purpose. A welcome reception is listed for Sunday evening in Hall A. Main exhibit hours open Monday. Treat this short as a before picture. The after picture starts tonight.
The calendar around the clip is not in dispute. IEEE/RSJ IROS 2026 runs 27 September through 1 October in Pittsburgh. Sunday is workshop and tutorial day. Official exhibit install runs through Sunday afternoon. Howie Choset of Carnegie Mellon is general chair. Pittsburgh last hosted IROS in 1995. Those are program facts. They are not proof any booth on this tape will still be standing Thursday.
What the new clip adds is the empty-room beat. A look inside before the floor gets busy: displays half-built, equipment on carts, staff on radios. No parade, no packed poster hall, no claim that a humanoid worked a shift. The correspondent’s line is that the atmosphere is relatively quiet and that the hall will look different once the community arrives. That is the cheapest true sentence of conference week. It is also the one that ages in a few hours. Watch it as logistics. Do not watch it as a product launch.
Program Chair Ross Hatton’s note is the scale line to keep: over 1,900 contributed papers, 86 workshops and tutorials, and 170-plus exhibitors. The program site also lists 19 keynotes, three plenary panels, nine competitions and 150 late-breaking posters. Do not swap those for older preview counts. The short does not audit the floor. It only shows the building while those sessions are still incoming. More IROS coverage from this desk is promised after the hall opens.
For a humanoid page the comparison is a factory tour, not a Games final. A quiet convention hall is how research weeks start. A crowded aisle with a working arm is how they get written up. Both can be true by Wednesday and still be early. A Sunday workshop is a useful scene. A booth that runs a demo without a minder is a different product. This tape has not published the second number. Until the floor is live, “IROS is here” is a caption, not a field rating.
So the 27 September lead is the walkthrough and the date. IROS 2026 is open in Pittsburgh, workshops first, exhibits still going in. Watch the short. Do not promote the bar. If tonight’s reception or Monday’s floor produces a named demo with hours, the ranking conversation starts. If the next clip is another empty aisle, this stays a conference-arrival story — which is still news. It is just not a counted fleet.
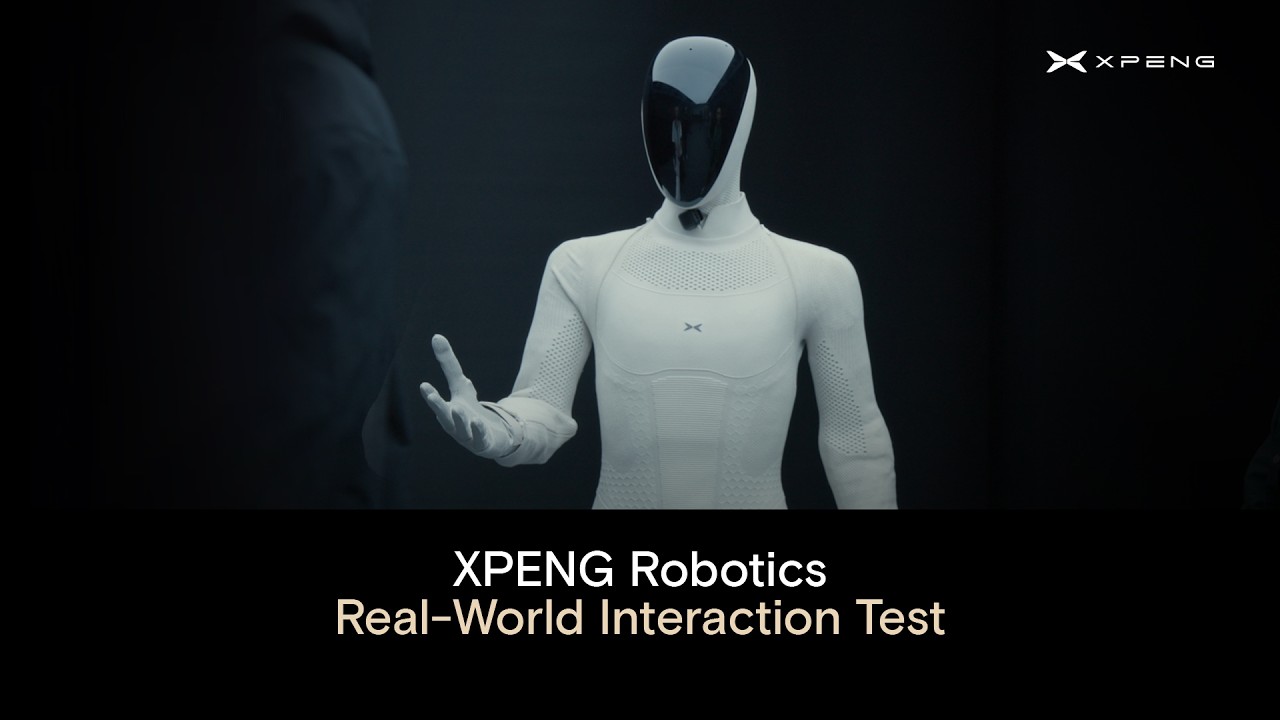
A company demo shows orientation, identity memory, live language switching, and multi-person Q&A on the humanoid.
Read full story →
XPENG posted a five-minute “real-world interaction test” on September 22. IRON stands with three testers and runs four tricks the company says make the humanoid feel closer to a person: it orients toward whoever is speaking, it keeps an identity for each visitor after they swap clothes and places, it answers in Chinese, English, or German without a separate “switch language” command, and it handles overlapping questions as multi-person Q&A. The caption is blunt: IRON recognizes you, understands you, and responds to you. Powered by Physical AI.
The clip is a studio sales conversation, not a store floor or a factory cell. IRON turns head, waist, and torso toward the active voice. After the testers change outfits and positions, it still ties each person to an earlier vehicle preference and corrects one speaker who borrows another’s name. Language follows the last utterance. XPENG attributes that stack to acoustic perception, vision, motion control, a multilingual foundation model, and a balanced training set. The video does not publish latency, tracking accuracy, or how the same stack behaves in noise or a crowd.
IRON is XPENG’s next-generation humanoid, shown since AI Day in November 2025 as a biomimetic body with a spine, covered skin, and high joint count — company materials have cited 82 degrees of freedom on the body and about 21–22 on each hand. Compute is onboard Turing silicon running a VLT + VLA + VLM stack that XPENG also links to its cars. The interaction video is the social layer of that pitch: conversation and recognition first, manipulation later. Retail assistance has been the near-term commercial path XPENG has described, with store deployments discussed for 2027. Screw-driving trials inside XPENG’s own plants have already shown how fast complex hands wear and how hard it is to beat a human on cost. This new tape does not reopen that industrial test.
Autonomous orientation is useful if the robot is a greeter. Dynamic identity memory is useful if a showroom visitor walks away and comes back. Multilingual switching matters in export markets. Multi-intelligence Q&A is the claim that more than one person can talk at once without the session collapsing. All four are shown under lights, with willing testers, on XPENG’s channel. Commenters already asked whether any of it is teleoperated. The company presents it as onboard Physical AI. Until someone else runs the same four tests in a real store, treat the video as a capability reel, not a field result.
Watch XPENG’s IRON interaction test.
Open the official video
Finger coordination changes the grasp as object shape changes. WUJI is shopping the hand to other robot teams.
Read full story →
A new clip shows Gento Luna, the wheeled dual-arm platform from Gento Robotics / Tianji, running WUJI dexterous hands through three household-scale chores: handling bottles, stacking blocks, and putting toys away. The point of the tape is not a new body. It is the fingers. As each object changes shape and size, the hands retune the grasp instead of locking one pinch and hoping friction holds.
Gento Luna is a research and application base more than a biped: dual 7-DoF force-controlled arms, an omnidirectional chassis, full-body compliance, and an open compute stack. WUJI’s current hands are 20-active-DoF five-finger units with in-hand direct-drive joints, built as a component other teams can bolt on. WUJI’s own docs describe Hand 2 as a biomimetic research and integration product with joint-level SDK access, simulation models, and a teleop demo. The video is that pairing in motion — a mobile torso that can reach a table, plus hands that can close around a bottle neck, a cube, or a toy without swapping tools.
Bottles punish a grasp that is too stiff or off-axis. Blocks punish poor finger opposition and sloppy placement. Toys are the messy set: mixed mass, odd outlines, items that roll. Coordinated finger motion is the claim that one hand family can cover that range. WUJI is using the clip as a recruiting card. The closer asks other robotics teams to take the same hands into more real applications, which is how a component vendor grows when it does not ship a full humanoid of its own.
This is still a demonstration. It does not publish cycle counts, drop rates, or how long the motors stay cool. It also does not say whether the policy is fully onboard, teleoperated, or mixed. What it does show is a commercially pitched hand doing the last-centimeter work that parallel-jaw grippers skip, on a platform designed to collect that data.
Watch Gento Luna with WUJI hands.
Open the video
Bill Li walks K5, K7, and the rest of the Silicon Valley lineup. The robots are already on patrol.
Read full story →
Goanna Capital’s plant-floor tour of Knightscope’s Silicon Valley headquarters puts founder, chairman, and CEO William “Bill” Santana Li next to the machines the company actually sells. Knightscope is not pitching a home humanoid. It builds autonomous security robots, emergency communication devices, and the software that ties them to a human operations layer. The firm was founded in 2013 and trades on Nasdaq as KSCP.
The operating numbers Li and the company have repeated through the summer and into GSX in mid-September are specific: 434 clients across 42 U.S. states, and more than 4.4 million autonomous hours logged. Those figures showed up on the Q2 2026 call, in the investor deck, and again in September field briefs. They describe a deployed fleet, not a lab count. The mix includes robots plus emergency devices and licensed agents. Knightscope talks about “plus or minus about 10,000 machines and agents in network,” which is hardware, software, and people under one contract — not 10,000 walking humanoids.
On the floor, Li walks the K5, the familiar five-foot outdoor patrol unit, and the all-new K7, a larger, faster all-terrain robot the company has been gating through prototype reviews. Limited K7 deployments have been aimed at the second half of 2026, with production language pointing at the fourth quarter and a client list restricted at first to Autonomous Security Force accounts. The K7 is the machine Knightscope wants on big sites the K5 navigation stack struggled with. Speed is one advertised change: Li has said it can run up to about 10 miles an hour, well above the K5.
The strategy underneath the tour is unromantic. Machines watch; software sorts; people still take the calls that need judgment. Knightscope’s pitch at GSX was that this stack should sit inside one vendor instead of a pile of subcontractors. Li’s longer line is a million machines that see, hear, and cooperate so the existing guard force has better tools. Four-point-four million hours is the evidence he cites that the current generation already lives outdoors, in every U.S. time zone, across summers and winters. It is also why a headquarters tour is news in a humanoid feed: this is one of the few robot companies whose units are already on paid patrol.
Watch the Knightscope headquarters tour.
Open the videoFive models, four industry packages, a claimed “one-brain” stack. The tape is the Master Mini. The list price is the news.

Faraday Future Intelligent Electric Inc. (NASDAQ: FFAI) used a 19 September Los Angeles event to put nine new embodied-AI device configurations on sale across five models. The company says prices run from $9,990 to $137,900 and that all nine are available for sale and delivery now through FF.com, Amazon and RobotShop. The video above is the Master Mini, the compact humanoid FF is using to own the bottom of that ladder. The longer 919 keynote sits on a separate stream. What changed this week is not a research paper. It is a listed EV name publishing a robot price sheet with a sub-ten-thousand-dollar humanoid on it.
Master Mini is listed at about 95 centimeters and 19.5 kilograms, with three trims: Mini, Mini Pro and Mini Ultra at 48, 117 and 200 TOPS of onboard compute. FF prices them at $9,990, $12,990 and $17,990, each bundled with a skills package the company itself values at $1,000, $1,500 and $2,000. The pitch is classroom coding, open development and robot soccer on one chassis. FF calls it North America’s first compact EAI humanoid under $10,000 that combines those three jobs. That “first” is the company’s line, not an audited category, and the skills-package dollars are FF’s own valuations.
The rest of the nine-configuration card mixes humanoid and wheel-legged machines. All-New Futurist is the full-size flagship: 51 active degrees of freedom, 71 with a dexterous-hand upgrade, a 1,152-watt-hour dual pack and a claimed eight-hour shift under standard conditions. Standard is $89,900. Ultra, with NVIDIA Jetson Thor and a stated 700 TOPS, is $129,900. FX Aegis Hyper, a large industrial quadruped for harsh sites, opens at $137,900. Aegis Mega, a mid-size wheel-leg with a 50-kilogram payload claim, starts at $74,990. Aegis Ultra-W, a lighter security and companion wheel-leg at about 22 kilograms, is $12,990.
Around the hardware FF wrapped four industry packages — K-12 education, university research, security and inspection — plus what it brands Education & Research Ecosystem 1.0. Founder YT Jia’s line is that FF is not building one body that does everything. It is building an EAI brain meant to ride several bodies, with data from those bodies feeding a factory that trains the next skill. FF also claims the catalog now makes it the U.S. firm with the most robot forms. Treat that as a count of its own shelf, not a census of every lab and vendor shipping iron this year.
Sales language is a “6+1” map: B2B, FF Par, e-commerce, video sales, community and Mcube, with RoboShare as the rental plus-one through AIxC Holdings, a vehicle FF controls. Three bundles sit on the sheet — device only, device plus skills, device plus a complete solution. A Middle East partner event was slated for 23 September. A “Built in USA” partner conference and IROS 2026 in Pittsburgh sit on 28–30 September. Those dates are the company’s calendar. Whether every SKU actually ships at the printed price is a delivery question, not a launch-slide question.
What can be written without the slogan layer is still enough to lead. Faraday Future, on 19 September, listed nine configurations across Futurist, Master Mini and the Aegis family. Master Mini starts at $9,990. The top of the sheet is Aegis Hyper at $137,900. Four vertical packages sit on top of that hardware. The tape is the small humanoid walking the education pitch. The story is a Nasdaq EV name selling a robot catalog with a classroom price at the bottom and an industrial quadruped at the top.
The team behind Asimov 1 has open-sourced the robot’s locomotion policy and the training code that produced it. The drop includes a trained policy checkpoint plus Isaac Lab training code: reward definitions, hardware-tuned actuator configurations and domain-randomization settings. The clip starts at ten seconds, where that stack is laid out. The point is a starting walk other labs can fork, not a finished general controller for every pair of legs now leaving a factory in China or California. Asimov 1 itself is the open-hardware biped this policy was trained to move.
A locomotion policy is the controller that turns balance, step timing and contact into a walk. Publishing the checkpoint means someone else can load the weights instead of training from noise. Publishing the Isaac Lab recipe means they can see how those weights were grown: which rewards were counted, how the actuators were modeled on the real motors, and how the simulator was randomized so the policy would not overfit a single floor or a single mass. Without those three files together, a public “walk” is usually just a highlight reel.
That last piece is the useful one for anyone who does not own an Asimov 1. Domain randomization and actuator settings are where a simulated walk usually dies on hardware. By putting those files next to the checkpoint, the release is asking other groups to retune the same loop for a different gearbox, a different mass, or a different gait, rather than rebuild the scaffolding before they can take a first step in their own lab. That is the difference between a demo video and a repo someone can actually break.
The note that came with the video is modest on purpose. Adapt the training setup when the hardware changes. Try another walking style. Build toward a new skill on top of a walk that already exists. It does not claim the policy transfers zero-shot onto a Unitree, a Figure or Faraday Future’s classroom Mini. It claims a foundation that a graduate student can clone without first inventing the reward book. Read it as an invitation to train, not as a guarantee that the next robot will walk on Friday.
Open locomotion stacks have become a second beat beside product launches this year. A $9,990 humanoid is a price on a purchase order. A public Isaac Lab walk is a tool in a repo. One asks a school district to write a check. The other asks a researcher to break the gait on Monday and send a pull request by Friday. Both belong on the same brief. They are not the same kind of news. One is a catalog. One is a method other people can reuse.
The facts in the tape and the caption are the release itself: Asimov 1 policy weights, Isaac Lab training code, rewards, actuator configs, domain randomization. No third-party benchmark or cross-robot transfer study is attached. Treat it as an open walk from the people who built the reference hardware, and then watch who actually trains the next policy on top of it. Until that second paper or fork shows up, the story stops at the files they posted.

Qiyuan Robotics, sold in English as PrimeBOT, held a 20 September launch for two personal machines: the Qiyuan Q1 and the Qiyuan T1. Both standard trims open at 19,999 yuan, about $2,800. The tape starts at twenty-eight seconds. These are home-size robots, not factory bipeds. The company is selling companionship, a custom shell and a follow-cam, with Tencent Cloud WorkBuddy listed as the shared layer for talk and tracking across both bodies. Shanghai was the main stage; other cities ran experience events the same week.
Q1 is the small humanoid. Height is about 88 centimeters. Weight is about 15 kilograms. The body folds into a backpack or carry-on, and the shell can be customized, including 3D-printed parts in the launch pitch. The brief positions it as family company and a street-level gadget, not a research platform. Explorer Edition is listed at 26,999 yuan. That is the trim for buyers who want the same foldable frame with a thicker software and accessory pack. Voice, personality and motion are part of the customization story Qiyuan is selling with the hardware.
T1 is the transformable unit. Standing height is about 100 centimeters. Weight is about 16 kilograms. It switches between wheeled-humanoid and quadruped modes, and it is sold with a camera-follow and camera-move job for indoor-to-outdoor shooting. Pro is 29,999 yuan. Where Q1 is a packable figure you can put away, T1 is the one that changes stance and rolls when a walk is the wrong tool for the hallway or the park path. The company is pitching that change of form as the reason to buy T1 instead of a second Q1.
What the two share is the cloud layer. Both are integrated with Tencent Cloud WorkBuddy for multimodal interaction and intelligent following. That is the home-use argument: a voice, a trail, a small body that does not need a lab bench. It is also a vendor stack. WorkBuddy is Tencent’s. The robots are Qiyuan’s. The launch does not publish a detailed offline-fallback spec for when the network drops in an apartment. If the follow feature needs the cloud, that limit belongs next to the price, not in a footnote after a return.
Orders are set to ship in sequence from 1 October, first come first served. That is a calendar claim, not a tracked first-wave of boxes on doorsteps. A starting price of 19,999 yuan puts both machines in the same consumer band as other compact home humanoids now printing list prices in China, while Faraday Future’s Mini is the dollar figure sitting on the lead tile of this brief. Pre-order channels cited around the launch include the official mini-program and major domestic ecommerce storefronts.
Write the pair as listed, not as a household census. Q1: 88 cm, 15 kg, folds, 19,999 / 26,999 yuan. T1: 100 cm, 16 kg, wheeled-to-quad, 19,999 / 29,999 yuan. Shared WorkBuddy. Ship date 1 October, according to the company. The clip is the launch tape from the Shanghai event, not a week of homes already living with either machine. Until those October boxes land and stay powered, this remains a priced announcement with two distinct bodies on the same receipt.
The Tokyo startup wants robots that slot into existing lines and swap worn parts on the floor.
Read full story →
Tokyo-based O-ID has raised $1.2 million in pre-seed funding to build fully modular humanoid robots for industrial manufacturing and logistics. The round was led by Chicago-based TAWANI Ventures, with participation from Hustle Fund, Techstars, and angel investors — including the founders of Humanoid Guide, who were early investors in 1X. The company will use the money to move its first robot from prototype to production and prepare placements on Japanese factory floors.
The pitch is aimed at labor shortages, not spectacle. Japan is projected to face a shortfall of more than 11 million workers by 2040 as factory staff retire and go unreplaced. In June 2026, Japan set a target of ¥10.5 trillion ($65.1 billion) in public and private investment for “physical AI,” with an aim of deploying 10 million AI-equipped robots by 2040. In the United States, manufacturers could need 3.8 million new workers by 2033, and as many as 1.9 million of those jobs could go unfilled.
Existing industrial robots are rigid, and retooling a plant around them takes capital and time. General-purpose humanoids are more flexible, but a single failed part can take a whole machine offline for months. For large automotive plants, an hour of downtime has been estimated at $2.3 million.
O-ID was founded in Tokyo in 2025 by Norwegian CEO Stian Jakobsen and Dutch CTO Simon Gormuzov, who met at Waseda University. Jakobsen previously worked in cyber defense. Gormuzov spent years in industrial robotics. The company has signed a letter of intent with Sumitomo Electric Industries to discuss applying Sumitomo technologies to humanoid wire harnesses. It has also filed a provisional U.S. patent for its modular connector technology and says Japan-built robots are being designed to meet NDAA requirements as it looks toward U.S. shipments later.
“When enough factory roles go unfilled at once, entire supply chains are at risk. O-ID’s robots are built to work alongside the people still on the floor,” Jakobsen said. TAWANI partner William Pritzker called modular humanoids a way to transfer Japanese robotics supply-chain expertise onto an AI-native platform. Techstars managing director Yuki Shirato said the robots are intended to be modular, mass-producible, repairable, and made in Japan.
Watch O-ID’s modular humanoid video.
Open the official video
It lifts 50 lb and recharges in nine minutes. Early access is planned for 2027.
Read full story →
On September 15, Agility unveiled Digit 5, a redesigned industrial humanoid with new legs, a higher lifting limit, and much faster charging. The pitch is simple: a robot that can work closer to people, so factories need fewer fences and cages around it.
Early access is expected in the first half of 2027, with general availability targeted for the end of that year. Agility also plans to expand beyond North America into the EU and UK. The specs are preliminary company estimates from pre-production testing, and some safety features are still in development.
Agility breaks it into three parts: detecting people, signaling what the robot is about to do, and an independent safety controller that supervises its motion. Depending on the situation, Digit can avoid a person, stop, or drop into a seated position. Agility is also the first launch partner for NVIDIA’s Halos for Robotics platform.
That is not a blanket safety certification. Planned CE and other regulatory marks for Europe are still expected rather than earned, and Agility says its safety measures do not remove all operating risk.
The timeline has slipped: an earlier company filing pointed to an initial Digit v5 release in late 2026. That filing also described a $300 million commitment for 1,000 Digit v5 robots under a three-year robots-as-a-service deal with a related-party customer — subject to milestones, and not yet revenue. Agility reported about $1.78 million in 2025 net sales and a $138.1 million net loss. It says Digit 4 has logged more than 65,000 operating hours, and no price has been announced.
Watch the Digit 5 launch video.
Open the launch video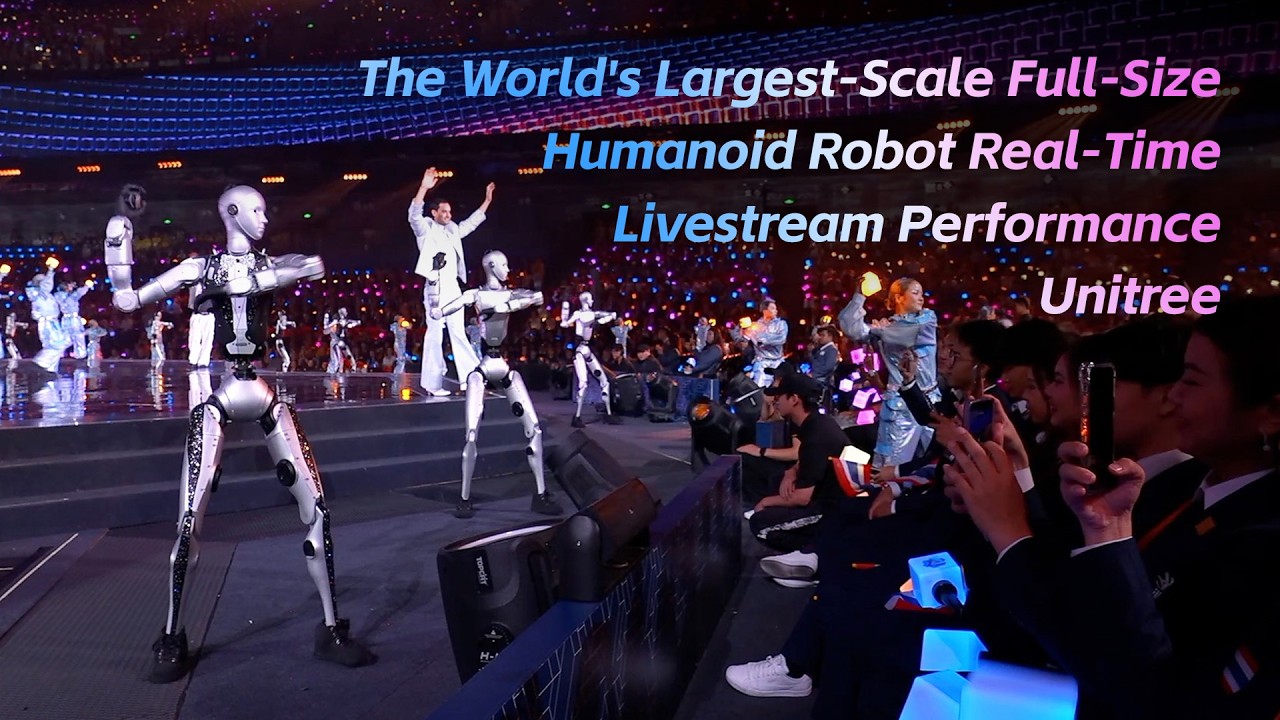
WorldSkills Shanghai opened with a live-streamed full-size robot cluster performance.
Read full story →
At the opening ceremony of WorldSkills Shanghai 2026 on September 22, 19 Unitree humanoid robots performed alongside 120 dancers. Unitree called it the world’s largest-scale performance featuring full-size general-purpose humanoids, staged before more than 10,000 people and live-streamed in real time as a fully AI-driven autonomous robot cluster.
The 48th WorldSkills Competition opened in Shanghai with 1,385 competitors from 68 countries and regions across 64 skill categories. Coverage of the ceremony focused less on medals than on a human-robot dance that organizers billed as a first for full-size humanoids working as an autonomous cluster.
A synchronized stage show is not a factory deployment. It does test timing, balance, multi-robot coordination, and safe proximity to people under lights and noise. Unitree is using the clip to argue that full-size general-purpose humanoids can now run as a coordinated group in public, not only as single demo units.
Watch Unitree’s WorldSkills performance video.
Open the official video
Pick, carry, and shelf placement are being trained as one retail workflow.
Read full story →
A new training clip shows a robot picking products, transporting them, and placing them on shelves in a supermarket setting. The point of the exercise is not a single grasp demo. It is the full loop stores actually run: identify an item, move it through an aisle, and seat it on a shelf without wrecking the display.
Retail is a hard test because products vary in size, weight, wrapping, and placement. A bottle, a box, and a bag do not fail the same way. Lighting changes down an aisle. People walk through the workspace. A policy that works on a lab table can stall when the next SKU is slightly farther back on the shelf.
Shelf work is one of the jobs retailers already spend labor on every day. Scanning robots that only look for gaps are already in some chains. Manipulation that can restock those gaps is a different problem. Real tasks are where robotic capabilities get tested and improved, and a supermarket aisle is a clearer scoreboard than a scripted lab clip.
Watch the supermarket manipulation training video.
Open the training video
Reception, water delivery, massage, and interactive demos put HRI on the show floor.
Read full story →
At the 2026 China International Fair for Trade in Services in Beijing, RealMan robots were shown in human-centered service scenes: visitor reception, water delivery, massage applications, and interactive experiences. The fair ran September 9–13 at Shougang Park and used service robots as a visible part of how exhibitors talk about daily deployment, not only factory work.
CIFTIS this year added consumer-facing robot zones covering retail, performance, and other public settings. Massage robots also appeared elsewhere on the floor, including traditional Chinese massage demos, which matches the service-work theme RealMan put in its own clip.
As robots move closer to real service environments, human-robot interaction becomes part of the product. A warehouse policy can hide behind cages. A reception robot cannot. RealMan has separately pushed a broader 2026 plan to put RealBOT systems into pharmacies, inspections, food production, and other live sites through its Global Link Network. A trade-fair clip is still a demo. The open question is whether those service behaviors hold up when the crowd is not watching a booth.
Watch RealMan’s CIFTIS service-scenario video.
Open the official videoSeven guest-facing jobs, a China Mobile 5G stack, a joint institute. The 20,000th machine off the line is a robot — not, in the PR, a humanoid-only count.

AGIBOT and Chimelong Group launched the first phase of a large-scale embodied-AI deployment at Chimelong Spaceship Park in Zhuhai, with more than 300 robots folded into the guest path. The companies call it a large-scale embodied AI theme park. The press note is careful about the work: not standalone demos, but robots embedded in entertainment, education, visitor services and hotel operations, with dedicated connectivity, multi-robot coordination and safety systems behind them. The launch reel above is the file issued with that announcement. The story is the fleet on a live park floor, not a new model name.
More than 300 AGIBOT robots are assigned across seven use cases: live entertainment, educational experiences, visitor guidance and shopping assistance, retail services, AI-powered companionship, hotel services, and sports. Visitors, the companies say, can watch martial arts, gymnastics and tai chi, play table tennis or run manipulation challenges, ask questions, get directions, or sit through robot-assisted learning. Hotel and companion settings add welcome, multi-turn talk and more personal interaction. Multi-robot shows are described as movement mixed with human performers, music and lighting. That is the visitor menu in the release, not an independent census of which unit does which job on opening day.
The serial number traveling with the launch is a factory count. AGIBOT says the 20,000th robot to roll off its production line was delivered to Chimelong. The About line in the same note lists humanoids, quadrupeds, dexterous systems and commercial cleaning in the portfolio. So the milestone is the 20,000th robot off the line, handed to this resort — not a verified tally of 20,000 bipeds. Linking that crate to one of the company’s largest tourism deployments is the point AGIBOT wants read in the same sentence as the 300.
Behind the path, AGIBOT, Chimelong and China Mobile say they stood up a dedicated 5G network for responsive interaction in high-traffic areas, plus centralized coordination across park and hotel zones. Safety language in the release covers network security, privacy, charging and fire. That stack is how they argue a three-digit fleet can run without becoming a pile of stranded units at the gate. It is still their operating framework. No uptime table or incident log is attached.
The partners also announced a joint research institute on embodied AI in culture and tourism, using this project as the working sample, and they describe the first phase as a base for spreading robots across more of Chimelong’s entertainment, hospitality and visitor-service sites over time. Collaboration language in the note is robot technology plus content design plus venue operations — robots as part of the day’s itinerary, not a single photo-op at the entrance.
What holds from the embargoed release is specific. Site: Chimelong Spaceship Park, Zhuhai. Phase one. More than 300 robots. Seven listed jobs. A China Mobile 5G and coordination claim. A joint institute. The 20,000th robot off AGIBOT’s line, delivered here. That is a launch, not a week of counted guest hours, and it is the largest guest-facing fleet the company has put on paper.

A hexapod teaching kit now ships locomotion, a small arm and a spoken-command stack on one chassis. The listed hardware is an 18-degree-of-freedom body running inverse kinematics; omnidirectional crawl, climb and dance; a two-degree-of-freedom arm for grab and carry; a two-megapixel camera for face, gesture, pet and line tracking; WonderLLM and ESP-Claw for speech; a six-axis IMU; and programming in Arduino, Scratch and MicroPython, with PC software and a phone app for direct drive.
Eighteen degrees of freedom on six legs is the standard three-servo limb. Inverse kinematics keep the body level while the gait changes, which is what lets a hexapod look like it is walking instead of ticking. The two-axis arm is the extra that turns a crawler into a machine that can pick something up and move it. Camera jobs match a first vision lab: find a face, read a gesture, follow a painted line, notice a pet in the frame.
WonderLLM is the branded module for talking to the robot. ESP-Claw is the on-device agent layer, so sensing, a decision and an action can run on the board instead of waiting on a cloud round trip. That pairing is the 2026 hook on an otherwise familiar hexapod recipe. The IMU exists so the chassis knows when a leg has left the ground, or when a student has picked the robot up mid-stride and put it down facing the wrong way.
The software path is built for schools and clubs rather than a factory cell. Scratch and the phone app cover beginners who want motion without writing a gait from scratch. Arduino and MicroPython cover students who want to own the claw, the camera loop and the walk. The pitch is one machine that can crawl on Monday and take a voice command on Friday without a second piece of hardware.
The video is a product demonstration of those features in sequence. It does not include a classroom trial with scored lessons, a published battery figure, or an endurance run that would tell a teacher how long the servos last in a noisy lab. Treat it as the spec list made visible, starting at the fifty-three-second mark where the hardware card is read aloud.
What you have, then, is a six-leg teaching platform with a small manipulator and an on-chip chat stack. It is not a full-size humanoid and it is not sold as one. It is a way for a student to hear a robot answer and then watch it close a claw on a block, which is how a lot of people will first meet embodied software this year.

Content creator Frankie LaPenna fought a six-foot humanoid styled as a T-800 at a private cage match organized by REK Robotics. The video is that bout. LaPenna, in heavy pads, lands punches on the metal. The machine answers with kicks that drive him into the fence and then onto the mat. The announcer frames it as a person stepping in against a six-foot robot. The clip is short, loud and built to travel.
REK billed the night as the first human-versus-Terminator fight and a turning point. That wording is the promoter’s. Similar man-versus-machine exhibitions have been staged before, which is why the “first” belongs in quotation marks. The 18 September event in San Francisco was organized to promote a virtual-reality game in which people pilot robots against one another or against a live opponent in a cage.
The robot is teleoperated from backstage, not choosing its own kicks. Coverage of the bout has identified the body as a modified EngineAI T800 under the Terminator shell and glowing eyes. Kick-force numbers that appeared in entertainment write-ups have not been published as a laboratory measurement. What the footage shows is a remote pilot, a heavy chassis and enough impact to move a padded adult across the floor.
LaPenna is a stunt and prank creator rather than a ranked fighter. After the match he showed a swollen hand from hitting metal, which is the injury detail that holds. REK’s chief executive later told an outlet that LaPenna came back and finished the robot once the viral kick sequence was over. The clip most widely shared still ends with him on the floor. Both accounts can sit in the same week without turning the night into a sanctioned result.
Pads, a cage and a pilot in a headset make this a show with real contact, not a title fight and not a new combat humanoid offered as a product. The thing being sold is the teleoperation loop and the game around it. REK has already said more bouts are coming and that the machine in this clip was not the last one in the lineup.
The facts that survive the edit are simple. The date is 18 September. The promoter is REK. The opponent is a six-foot T-800-styled humanoid driven by a person. The man in the cage is Frankie LaPenna. The tape is the exchange of punches and kicks from that private match, not a factory demonstration and not an autonomous fighter working on its own.
The new biomimetic hand starts at $6,500 before tax and shipping. Every joint is backdrivable and has impact-torque protection.
Read full story →
Unitree published the Dex5-S on September 21 as a precision biomimetic hand built at roughly 1:1 human-hand size. The official English listing puts the starting price at $6,500, tax and shipping excluded. Chinese coverage of the same launch quoted 39,900 yuan as the domestic starting price. Both figures describe a list price for the hand itself, not a complete arm, a humanoid, or an installed research cell.
The selling point is density. Dex5-S carries 22 degrees of freedom in one hand, with 22 motors that Unitree says all support direct drive, smooth backdrivability, and dual-encoder control. Each joint includes limit impact-torque protection so a hard collision is supposed to spare the gears instead of stripping them. Unitree added a little-finger roll degree of freedom that earlier Dex5 hardware did not have, which the company says improves wrap and grasp angles on tools and irregular objects.
Reporting on the launch put the aluminum-shell hand at about 620 grams, with paired left-right envelope dimensions of 102 × 187 × 26 millimeters. Peak one-hand payload is listed at 2 kilograms, with a 1-kilogram continuous working load. Power is a wide 15–65 volt range on an XT30 connector, with peak draw around 200 watts. Interfaces include gigabit Ethernet, USB, and high-speed 485. In the gigabit configuration, a palm camera can plug into the hand without a separate external camera harness.
The official clip shows spoon pickup, scissor cuts, lemon toss-and-catch, and can-tab pulls. Those are demonstration takes on a bench-scale hand. They do not establish cycle life in a factory, autonomy on a walking humanoid, or medical fitness as a prosthesis. Unitree’s own argument is narrower: once a hand is close to human size, it can use human tools and human workspaces without the bulk that older dexterous hands carried. Payload remains modest. Two kilograms peak is useful for utensils and small parts, not for tote work.
Backdrivability matters for learning as much as for safety. A joint that can be pushed around by the world is easier to force-control and easier to train with reinforcement learning than a locked industrial gripper. Impact protection is the complementary claim: the hand can take a hit without becoming scrap. Both claims are manufacturer specifications until third-party endurance numbers show up.
Dexterous hands have been the expensive, late, and fragile part of humanoid programs. A catalog hand at human scale, with a public dollar price, is Unitree trying to sell that bottleneck as a component instead of waiting for a full robot refresh. $6,500 before tax and freight is cheap next to research hands, and it is still only the end effector. Integration, sensing on the Pro model, and whether 22 small motors survive real collisions will decide if Dex5-S is a product or a spec sheet with a launch video.
Watch Unitree’s Dex5-S introduction.
Open the official video
Bernt Børnich told Relentless the 2027 target is gated by quality, not by empty factory floor space.
Read full story →
In a September 18 interview with Ti Morse on Relentless, 1X founder and CEO Bernt Børnich said the company is preparing to manufacture and ship 50,000 NEO humanoids in 2027. He put the constraint in the first minutes: the hard part is not only moving that many machines out the door, but making sure customers do not send them back. That is a quality-and-safety gate, not a press-tour capacity number.
The installed base he described is two California plants running in parallel. Hayward is built out to about 10,000 units a year at a full ramp. Børnich said that rate arrives late in 2026, so Hayward will not actually produce 10,000 robots this calendar year. San Carlos is being built for 100,000 units a year at full capacity. Most of that volume, he said, comes online late in 2027. Combined nameplate capacity is 110,000 a year. The 50,000 shipment target sits well below that ceiling on purpose.
Børnich treated humanoid production as unlike auto production. A well-designed humanoid, in his telling, should have on the order of 1,000 parts rather than a car’s tens of thousands, but there is no mature supplier list for the motors and tendon drives 1X builds in-house. Because those pieces are internal, he said a major CAD change can become a walking robot off the line in about four weeks. Early units will still need remanufacturing and field service. NEO’s size and weight are supposed to let technicians fix many failures on site instead of issuing a recall.
The mix is homes, enterprise sites, and a developer platform. Home deployment is the uneven, less structured case. Enterprise work sits in tighter environments. The developer path is how 1X wants outside builders to generate the messy situations a lab will not invent. Børnich said folding laundry has become straightforward with current models and is not the enterprise job he is selling. He expects specialized models to stay ahead through 2026 and broader competence to show up more in 2027. That is a forecast from the interview, not a published benchmark.
The second half of the conversation is the learning stack. Training data, as he listed it, includes internet video, simulation, synthetic data, human sensor recordings, teleoperation, and robots acting on their own. Deployed machines feed the next model. He has argued that 1X is rarely starved of raw hours and is instead starved of variety: “In reality, you’re almost never data bound. You’re diversity bound.” World models are the company’s bet on learning how scenes change. He also allowed that task-specific vision-language-action training can still beat a world model on a narrow chore such as folding, given where the models are now.
Safety remains unfinished work. Børnich said 1X hopes to show more formal evidence later in 2026. Until that exists, a 50,000-unit year is a manufacturing plan sitting on top of an open reliability question. Shipping volume without a return rate the company can live with would be a failure even if the factories hit their weekly counts.
Most humanoid firms still talk in hundreds of robots. Fifty thousand is a different scale, and Børnich spent the interview refusing to treat factory floor space as the proof. The useful test in 2027 is not whether Hayward and San Carlos can physically assemble NEOs. It is whether the ones that leave stay in the field, generate diverse data, and do not come back in a truck.
Watch Bernt Børnich on Relentless.
Open the interview
RKB filmed MOTOMAN NEXT assembling robots in Factory No. 5, then working the employee cafeteria.
Read full story →
RKB Mainichi Broadcasting posted a September 16 plant visit from Yaskawa Electric’s headquarters in Yahata-Nishi, Kitakyushu. The piece treats “Physical AI” — Yaskawa’s term for AI that recognizes a scene, chooses a procedure, and moves a robot without a fully written program — as the company’s core growth bet. Reporter Kensuke Nishio watches an AI robot take a vague spoken request, pick a pen from a toolbox, and put it in a blue box, narrating the steps as it goes.
That demo is the friendly version of a harder factory job. Yaskawa’s Robot Factory No. 5, which the company says moved into full-scale operation in July 2026 after coming online earlier in the year, is where AI robots assemble other AI robots. Section manager Masayuki Watanabe walks the line and points to MOTOMAN NEXT on screw tightening, the process he calls unavoidable in manufacturing. Conventional programmed robots, in the plant’s telling, already hit about 99 percent success. That still stops a line once every few units and sends a person in. The AI cell is supposed to see a missed thread or a dropped screw and retry on its own. Watanabe said tightening success had moved above 99.9 percent, which would cut the maintenance load if the figure holds off-camera.
A raw-material station uses 3D sensors to read wrinkles in a bag, cut it, and dump contents without wrecking what is inside. Assistant manager Keisuke Shirakami said that kind of work still depends on people lifting heavy sacks, especially in food and beverage blending, and that bag opening is a place Physical AI can go first. The same report then leaves the factory floor for the employee cafeteria. Two AI robots take a panel order, pull instant noodles, and cook udon or soba. A new hire called the workplace presence striking. Cafeteria assistant manager Hiroyasu Yamamoto said the value was simpler: robots now handle the hot, burn-prone steps people used to do.
RKB framed the Kitakyushu work against a global race. It cited the World Humanoid Robot Games held in Beijing in August, with more than 2,000 robots from 15 countries, and a 2024 Stanford country ranking on AI research and investment in which the United States led and Japan sat well back of China. Those are the broadcast’s comparisons, not a new Yaskawa scoreboard. The company’s own answer is motors it has built for decades, plus MOTOMAN NEXT cells that recover from errors instead of halting a line.
Yaskawa’s mid-term plan covering the years through fiscal 2029, laid out in May, commits about ¥250 billion of investment over four years. Japanese coverage of that plan put the fiscal 2029 aims at roughly ¥650 billion in revenue and ¥100 billion in operating profit, with Physical AI and MOTOMAN NEXT sales at the center and humanoid work aimed at offices, hospitals, and other non-factory floors. Factory No. 5 itself was a separate brick-and-mortar bet: on the order of ¥20 billion to move production onto the headquarters site, raise capacity about 1.8 times, and make servo motors in the same plant instead of trucking them across the city. Yomiuri’s June tour put output at 1,500 robots a month, expandable to 2,200, with about 35 of roughly 110 line robots being MOTOMAN NEXT units.
This is not a biped leaving a lab. It is an incumbent robot maker putting agent-style recovery on screw guns, bag cutters, and a cafeteria line, then filming it in the plant that builds the next robot. Ninety-nine-point-nine percent on one process is still a company-reported plant figure. The larger signal is that Yaskawa is spending like Physical AI is a product line, not a slogan, and it is doing the first deployments on work it already understands.
Watch RKB’s Yaskawa Factory No. 5 report.
Open the videoAdcock walks RoboStrategy through Index, the rented houses, Figure 03 at 1,000 units, and a Figure 4 teaser. Company numbers throughout.

Figure released Helix 2.5 on 17 September and sent Figure 03 into 30 Bay Area houses the robots had not seen. The company line: no extra training in those rooms, then useful work. Brett Adcock sat with RoboStrategy this week to unpack it — holy grail, four stages, Index scale, the houses, datasets, whether robot models follow LLM scaling, what 2.5 can actually do, a Figure 4 tease, Figure 03 past 1,000 units, the Schwarzenegger Figure 2s, more robots than employees. The interview is the lead tape. The numbers that matter are on Figure’s own score sheet, not the banter.
Figure reports 237 full-task successes in 420 trials, or 56 percent, with no partial credit. An otherwise identical policy trained without Index pretraining hit 9 percent. Split by chore: bed making 67 percent (94 of 140), towel folding 62 percent (87 of 140), living-room toy tidy 40 percent (56 of 140). A tidy trial only counted if all 13 to 15 toys reached the basket. Beds needed pillows and comforter corners at the head and the comforter pulled smooth. The inverse is the unsupervised problem: 44 percent of trials failed under those rules. That is still Figure grading Figure.
Zero-shot here means the homes, layouts and objects were unseen at evaluation. The three tasks were specified with fine-tuning data collected elsewhere. A frozen checkpoint ran across all 30 houses — no local data, no weight updates after the truck arrived. Figure says no single eval task is more than 1.90 percent of Index pretraining, and that 2.5 used about half the adaptation data of a comparable Helix 02 behaviour while leaving the training house. Index, in the company write-up, now generates about 35 minutes of new human experience every second. Compute commitment cited alongside: $3.5 billion with Nscale. Company figures.
What the robots actually did is whole-body work, not tabletop pick-and-place: walk the room, find the pile, fold cloth, pull a comforter. Figure posted a four-hour cut of continuous runs. Commenters asked for spills, a full sink, a cable on the floor. Fair. This brief will not upgrade tidy-and-make-the-bed into a maid. It will also not pretend 9-to-56 with Index held fixed is a small delta. Pretraining was the only variable in that comparison, per Figure.
The rest of the interview is roadmap talk. Figure 03 production crossing 1,000 units is a milestone RoboStrategy already logged in July as delivered units — treat the on-air recap as the same company claim, not a new audit. Figure 4 is a tease in the chapter list, not a spec sheet. “More robots than employees” is a headcount slogan. Schwarzenegger and the Figure 2s are colour. None of that moves the 56 percent.
Bar sits at four. A measured 30-home eval with published task splits and a control without Index is the strongest generalization tape of the month. It is not unsupervised housework and it is not a third-party bake-off. HPS #4 on this page means the test is real and incomplete. Watch for a dirty-home protocol, or someone else scoring the same three chores.
Unitree put Dex5-S on the channel on 21 September: a precision biomimetic hand, human-scale, from $6,500 before tax and shipping. All 22 joints backdrivable. Each joint listed with limit impact-torque protection. Domestic coverage puts the floor at 39,900 yuan. The 43-second clip is the announcement tape. It is a product drop, not a Games medal and not a factory cell. The number that moves the market is the sticker next to a 22-DoF count most labs still pay five figures for.
Launch write-ups describe five fingers at roughly 1:1 hand size, about 620 grams in one recap, thumb and pinky at five degrees of freedom and the middle three at four. Dual encoders and backdrivable motors are the compliance pitch — an external shove can move the joint instead of fighting a locked gearbox. That matters for reinforcement learning and for not snapping a wine glass. Unitree also flags a Pro SKU with tactile sensing versus a Standard without. Spec sheets are still thin on fingertip force and cycle life.
Dex5-S sits above Dex5-1 in the family tree. The prior hand was described as 20 degrees of freedom with a 16-active / 4-passive split and a large tactile array. The new unit’s claim is every joint driven and backdrivable. Do not flatten that into “more sensors.” It is more actuated axes plus a price that undercuts Allegro, Shadow and most direct-drive research hands. Whether it undercuts OmniHand or Wuji on a timed grasp is untested here.
The video drew the usual respect for showing metal instead of only renders, and the usual “that is not how you open a can.” Fair on both. A $6.5K 22-DoF hand will land on G1 / H1 / H2 arms because that is Unitree’s stack. Integration hours will decide if the DoF count is usable or just countable.
Bar at three. A named SKU, a public price, and a backdrivability claim across all joints is more than a concept reel. It is not a third-party durability log. Three bars means the product exists and the test has not.
Watch for a force table, a Pro versus Standard split you can order, and a humanoid wearing two of them through a shift. Until then Dex5-S is the cheapest ticket into the 20-plus-DoF club Unitree has sold.
XPENG’s new IRON clip is a real-world interaction test, labeled as such. Four capabilities: autonomous orientation toward the speaker, dynamic identity memory, seamless multilingual switching, multi-intelligence Q&A. The caption says IRON recognizes you, understands you, responds to you, powered by Physical AI. The footage is three testers playing car buyers in the robotics lab. That framing matters. This is not a dealership log. It is an R&D demonstration of the social stack sitting on the production-line body XPENG walked off the line earlier this month.
In the identity beat, one tester borrows another’s nickname; IRON corrects him and recalls vehicle interest. The company says recognition holds when the three swap places and clothes. Memory is described as face plus voiceprint plus conversation history, updated on later encounters. Language switch is presented without a separate “now speak English” command — Mandarin and English in the exchanges. XPENG credits a multilingual foundation model and balanced training data. No published accuracy, latency or overlapping-speaker score accompanies the reel.
Hardware context from the September production announcement, not this video: 76 body degrees of freedom, 21 per hand on the production revision, three Turing chips and a company rating of up to 2,250 TOPS onboard. Mass production targeted by end of 2026, commercial deliveries talked for 2027. Those dates stay on the factory slide. The interaction tape does not prove them.
Physical AI is XPENG’s corporate banner — cars, IRON, flying boxes on the same Turing story. VLM conversation and VLA action are the split the company has used since AI Day. This clip is almost all VLM: look at the person, remember the person, answer the person. Walking and grasping are off-screen. Do not write that IRON now sells cars.
Useful as a humanoid-as-clerk sketch. Thin as evidence. Three scripted buyers in a lab is how you start a memory demo. It is not how you measure a showroom.
Bar stays at zero. A labeled R&D interaction test belongs on the page beside Helix’s scored homes and Unitree’s priced hand. It does not get a field rating until XPENG publishes a recognition table or parks IRON on a real floor with real shoppers.
Omnidirectional base frees the arms. Mid-air dual-arm force control is the point of the tape. No pharmacy hours attached.

LimX Dynamics put Wuji Hand 2 on TRON 2 and ran a traditional-Chinese-medicine counter: pick herbs from drawers, weigh them, grind, pack. The clip posted late August is still the cleanest arm-plus-hand integration tape this month, which is why it leads on 21 September. The company line is hardware-software synergy. The useful sentence is narrower. An omnidirectional wheeled base carries the body so the 7-DoF arms and the 20-DoF hands can stay on the work. Mid-air dual-arm force control holds a scale that is not sitting on a table. That is a coordination demo. It is not a pharmacy roster.
TRON 2 is LimX’s multi-form platform: dual arms on a torso that can stand on wheels, legs, or a fixed base. Published spec: 7 degrees of freedom per arm, ±0.5 millimetre repeat positioning, 5 kilograms maximum per arm (3 kilograms extended), spherical wrist, optional gripper or dexterous hand. The pharmacy tape uses the wheeled-leg / omnidirectional setup so the robot can square up to a cabinet without asking the hands to walk the payload across the floor. Wuji Hand 2 is the ICRA-era direct-drive five-finger unit — 20 active degrees of freedom, serial rotary joints, no tendon maze in the digits.
Japanese and Chinese write-ups of the same video walk the sequence. One hand opens a drawer; the other extracts dried materia medica. Both hands then hold a beam scale off the counter while material is added. Grinding and bagging close the loop. The mid-air weigh is the hard part. The arm is no longer just a mover. It is a stable platform while the fingers dose. LimX lists 100-millisecond teleop delay on the kit; this reel does not say whether the run was teleop, scripted, or a learned policy. Do not invent that.
Wuji’s thank-you in LimX’s post is the integration note that matters. A lot of 2026 hand clips assume a fixed arm. This one assumes a mobile torso and a third-party hand that actually bolts on. LimX already lists BrainCo and Wuji as tested end effectors. That is a product path: sell the body, let the hand vendor ride along, collect the contact data that neither firm can gather alone. The TCM shop is a photogenic stand-in for any cabinet-plus-scale job.
What the tape does not show: cycle time, miss rate, a named pharmacy chain, or a shift without a spotter. Treat “handles TCM pharmacy work” as the caption on a validation video, which is how LimX posted it on 26 August. Re-upping it for Monday is fine. Promoting it to a deployment is not. Embodied-AI labs will care because drawer, scale, mortar and bag are four contact regimes in one take.
Bar stays at zero. Two vendors sharing a scene is news. A counted counter is a different story. Watch for the same stack on a second site, or a VLA paper that cites this run as training data. Until then: wheeled base, Wuji fingers, mid-air weigh, pack the bag, cut.

Dobot’s X-Trainer explainer is back in circulation: an advanced dual-arm teleoperation and AI training platform built around two Nova 2 cobots. The pitch is higher education, research and technical training — capture repeatable demonstration data without welding a rig from scratch. Imitation learning, computer vision, human-robot interaction. The chapters walk introduction, teleop, why the data matters, lab pain, hardware, SDK, curriculum. It is a product video for a kit that has been on the market since 2024. It belongs here because physical-AI labs keep buying dual-arm data, not because it walks.
Hardware is two 6-axis Nova 2 slaves plus two 6-DoF master hands with end handles. Nova 2 repeatability is listed at ±0.05 millimetres. Combined dual-arm span is about 1,200 millimetres; single-arm reach 625 millimetres. Collision detection is five-level; the cobots carry ISO 15066 collaborative certification. Dual e-stops sit on the table. Master-hand load on the operator is advertised under 400 grams. That is the safety case for putting undergraduates on the handles.
Software is DobotStudio Pro plus an API that exposes master joint angles, lock/sync, slave Cartesian control, gripper stroke, and RGB/depth frames. Record starts from a green button on the handle. GitHub’s embodied-dobot/x-trainer stack maps the leader into Isaac Lab, VR (Quest/PICO) and a 30-hertz HDF5 pipeline aimed at VLA training. Dobot has claimed a 70 percent cut in scenario training time, down to about two hours for simple tasks. That figure is marketing from the 2024 launch. Leave it labeled.
Why a humanoid page cares: most foundation-model teams still collect bimanual data on tables, not on bipeds. X-Trainer is the industrial-grade version of that table. Students get collision-limited cobots instead of a research arm that can break a wrist. Researchers get cameras and a leader that already talks to LeRobot-style formats. It does not replace a Digit or a TRON 2. It feeds them.
The clip is not news of a new robot. It is news of the channel still selling data infrastructure while the rest of the week argues about hands and policies. Fair placement as digest two. Do not write “humanoid trainer.” Write “dual-arm cobot classroom.”
Rating stays at zero. A shipping education kit with a new explainer is useful context, not a field rating. Watch for a published student dataset or a paper that names X-Trainer as the capture rig. Until then it is two Nova 2s and a pair of handles doing what they were built to do.
Linkerbot’s 19 September short is a speed argument, not a launch. LinkerHand L30 is tendon-driven, high degree of freedom, and fast because the actuators sit behind the fingers. Little mass left to accelerate. That, the caption says, is what coordinated work at this joint count requires. Footage from earlier this year is cut with more recent takes. The title on the channel calls it the fastest high-DoF hand they know of. That superlative stays in the video. It does not become a measured ranking here.
The product manual is the sheet we will use. L30 is a modular anthropomorphic hand from Linxin Qiaoshou / Linkerbot. Transmission is UHMWPE tendons in PTFE tubes, motors remote from the digits. Coordinated control of five fingers: 17 degrees of freedom, 21 joints (17 active, 4 passive), including a wrist degree of freedom on that count. Control interface CAN FD. Reseller pages scatter 21- and 22-DoF labels; treat those as marketing variants of the same architecture, not a second product.
Published performance numbers that repeat across decent listings: about 1.4 kilograms, ±0.20 millimetre repeatability, fingertip forces in the low-newton range on the flagship tendon version, core motion advertised near 400–450 degrees per second. Payload figures disagree between shops — 2 kilograms on one sheet, much higher on another — so this brief will not pick a load. Speed and remote actuation are the claims the new clip actually illustrates.
Why tendons again after a week of Wuji direct-drive: different packaging. Direct drive puts a motor at the joint and accepts heat and distal mass. Tendons move the mass into the palm or forearm and accept stretch, routing and maintenance. L30 is the second bet. If the cut-together reel is honest, the fingers look light because they are. If the “fastest we know” line is just editing, it will show the first time someone times an open-close against Wuji Hand 2 or OmniHand on the same task.
Linkerbot already had an L30 on the market before this montage. The news is the speed framing plus an admission that some shots are old. That honesty helps. A lab buying a high-DoF tendon hand still has to ask about tendon life, calibration drift and whether the wrist DoF is in the SKU they will receive.
Rating stays at zero. A tendon flagship with a new cut is the hardware counterpoint to TRON 2’s Wuji integration and Dobot’s classroom arms. Three ways to get fingers on a task this week. None of them is a counted line. Watch for an L30 on a named humanoid, timed, not montaged.
Same chores, same robot — Index pretraining raised full-task success from 9% to 56% in 30 rented homes.
Read full story →
Figure’s Sept. 17 Helix 2.5 release is less a new robot than a bet on data. The company sent Figure 03 into 30 rented Bay Area homes it had never mapped, then argued that pretraining on Index — its human-behavior dataset — is what made the difference.
Hold the chores, the hardware, the architecture, and the evaluation fixed, Figure says, and an Index-pretrained policy finished 56% of trials. A matched policy trained from scratch finished 9%. That is 237 of 420 full-task attempts versus a baseline Figure rounds to 9%.
No data was collected in the test houses. No weights were updated after the robots arrived. The beds, towels, and toys in the evaluation were kept out of the task-specification set.
The three jobs themselves were not improvised. Bed making, towel folding, and living-room tidy were specified with fine-tuning data gathered somewhere else. Zero-shot applies to the rooms and the objects, not to inventing household work on contact.
Success meant the whole job. Partial piles did not count.
Figure also says Helix 2.5 matched a comparable Helix 02 success rate with half as much task-adaptation data, then ran that policy across 30 unseen homes instead of the single house used to train the earlier behavior.
Helix 2.5 was pretrained from random weights on Index. Helix 02 started from a pretrained vision-language model. Figure’s claim is that the human-video corpus, not a borrowed VLM, now carries most of the transfer.
Index, by the company’s count, adds about 35 minutes of new human experience every second. Figure has committed $3.5 billion of compute to Helix training and says doubling Index data improved downstream action-prediction loss on a smooth enough curve to forecast its largest run before that run was trained.
Fifty-six percent is a research result, not a product SLA. Figure has said general humanoid robotics is not solved. A policy that clears beds more often than toy piles will not replace a housekeeper. The live question after Sept. 17 is whether more Index data keeps buying new-house performance, or whether the curve flattens before reliability is high enough to leave the demo.
Watch Figure’s Helix 2.5 30-home generalization video.
Open the official video
It lifts 50 lb and recharges in nine minutes. Early access is planned for 2027.
Read full story →
On September 15, Agility unveiled Digit 5, a redesigned industrial humanoid with new legs, a higher lifting limit, and much faster charging. The pitch is simple: a robot that can work closer to people, so factories need fewer fences and cages around it.
Early access is expected in the first half of 2027, with general availability targeted for the end of that year. Agility also plans to expand beyond North America into the EU and UK. The specs are preliminary company estimates from pre-production testing, and some safety features are still in development.
Agility breaks it into three parts: detecting people, signaling what the robot is about to do, and an independent safety controller that supervises its motion. Depending on the situation, Digit can avoid a person, stop, or drop into a seated position. Agility is also the first launch partner for NVIDIA’s Halos for Robotics platform.
That is not a blanket safety certification. Planned CE and other regulatory marks for Europe are still expected rather than earned, and Agility says its safety measures do not remove all operating risk.
The timeline has slipped: an earlier company filing pointed to an initial Digit v5 release in late 2026. That filing also described a $300 million commitment for 1,000 Digit v5 robots under a three-year robots-as-a-service deal with a related-party customer — subject to milestones, and not yet revenue. Agility reported about $1.78 million in 2025 net sales and a $138.1 million net loss. It says Digit 4 has logged more than 65,000 operating hours, and no price has been announced.
Watch the Digit 5 launch video.
Open the launch video
Drone footage shows the steel frame nearly done. Production timing is still unsettled.
Read full story →
A September 17 drone update from longtime Giga Texas watcher Joe Tegtmeyer shows the steel frame of Tesla’s dedicated Optimus factory roughly five column grids short of the building’s north perimeter beam. The frame is close to complete, but the plant is not close to building robots yet.
Tesla’s Q2 2026 shareholder update lists both its California and Texas Optimus facilities as under construction, without stating an installed annual capacity for either. In Fremont, the company said it had decommissioned the Model S and Model X lines and was installing the first Optimus production lines, with production anticipated in 2026. Early robots there would support data collection and development in its Optimus Academy.
Tegtmeyer expects first limited production at Giga Texas in late 2027. Teslarati’s coverage of the same update refers to high-volume production in summer 2027, and says Fremont began mass-producing Gen 3 in January, which sits uneasily with Tesla’s own July disclosure. A construction video cannot settle those differences.
A finished steel frame is a visible sign that Tesla is committed to Optimus manufacturing at scale. It does not show that assembly equipment has been installed, commissioned, or run at production speed. The next evidence to watch is equipment going in, commissioning, and sustained output.
Watch Giga Texas Site Update
Open the videoThe pitch is One Model, One Data Interface, Any Body. The hours are company hours. The bar stays dark.

Reward AI says human-level manipulation is not more data or more compute. OM-1 is the company’s general-purpose robot policy: learn from people at human speed, then run the same policy on industrial arms and humanoids. That is the line on the 14 September tape and the OM-1 blog, not an audited cell. The reel marks bartending at 00:11, a nut at 00:45, ethernet at 01:02, phone packaging at 01:10, laundry at 01:32, tube sorting at 01:47, and a humanoid toss at 02:04. Treat those as promotional cases. Bar stays at zero until someone else times the work.
The hardware Reward AI published is consistent across the blog and the launch posts. Omnibody Hand is a wearable seven-DoF capture device built on Stanford DexCap, not a joint-by-joint human copy. Thumb-index pinch and coordinated power grasp are the functions it keeps. One Data Interface adds tactile arrays, proximity, palm cameras and electromagnetic tracking so people do not have to slow down for the recording. Those are spec-sheet facts. They are not proof that a new body ran last night without a minder.
What the new clip adds is the no-teleop pitch. OM-1 is supposed to learn from human data alone — no robot hours, no separate post-train stage — and emit speed, force and grasp timing for any body. A high-frequency control layer, trained in simulation, is what maps that onto hardware and eats delay and load. The company says a hard long-horizon task can come up from less than thirty minutes of raw demonstration. That is the story Reward AI wants. It is also the story that is cheapest to film and hardest to verify off their floor.
Reward AI has spent the week moving from stealth to public rooms. DexCap was the academic beat. OM-1 is the work-shaped sibling: one interface, many bodies, not choreography. Fair enough as a marketing sequence. It does not retire the question every foundation policy still owes: how many sites, how many hours, how many human resets per shift. Multi-robot collab is named in the social copy. Named customers are not.
For a humanoid page the comparison is every stack that still routes skill through teleop and on-robot fine-tuning, not a dancing reel. OM-1’s argument is that those hops keep robots slow. Both can be true and still be early. A bench that pours a drink is a useful scene. A policy that holds a roster across mixed bodies is a different product. Reward AI has not published the second number. Until it does, “Any Body” is a caption, not a field rating.
So the 19 September lead is the tape and the label. OM-1 is a general-purpose policy trained on robot-free human data, with a seven-DoF glove and a control layer that is supposed to travel. Watch the clip from 11 seconds. Do not promote the bar. If a named lab posts its own timings, the ranking conversation starts. If the next video is another clean bench, this stays a company intelligence story — which is still news. It is just not a counted fleet.

Apex Hand, Dexcel Robotics’ high-DoF five-finger unit, is on a clip that is more vendor tape than medal table. The company says it was the only high-DoF hand used across both high-load and precision-manipulation challenges at the World Humanoid Robot Games 2026. That is the caption, not an organizing-committee roster. Independent coverage of the new eight-event hand track still runs through AGIBOT’s OmniHand. Treat Apex’s line as a promotional case shot against a Beijing backdrop.
The sheet Dexcel and Rysen publish is consistent across product pages. Apex lists 21 degrees of freedom with 16 active, about 1.2 kilograms, fingertip force above 20 newtons, and a 30-kilogram maximum-load claim. Joints are sold as backdrivable. Skin is sold as full-hand e-skin. Repeatability is under 0.5 millimetres. Founder copy describes a tendon-driven hybrid, not a pure direct-drive finger. Those are spec-sheet facts. They are not a start list from the Oval.
What the new clip adds is the two-lane pitch. One body is supposed to take load and still do fine work — tools and tweezers without a claw swap. The Games, 22–26 August at the National Speed Skating Oval, were the first edition with a dedicated dexterous-hand track. That is the story Dexcel wants: dexterity, strength and reliability tested next to competitors. It is also the story that is cheapest to cut with stadium b-roll and hardest to verify without a named heat.
Dexcel has spent a year moving Apex from launch reels toward public rooms. Smartphone use and a Kapandji score were the early beats. This tape is the next one: stop talking about a hexagon of specs and start talking about the Games. Fair enough as a marketing sequence. It does not retire the question every hand still owes: how many cycles, how many resets, how many fingers swapped per shift.
For industrial readers the comparison is OmniHand, not a parallel-jaw that already packs boxes. OmniHand’s argument is a published Games result. Apex’s argument is one end effector covering heavy and fine. Both can be true and still be early. A hand that holds 30 kilograms on a sheet is a useful scene. A hand that held a scored run in Beijing is a different product. Dexcel has not published the second number.
Rating stays at zero. A high-DoF hand claiming both load and precision at the Games is worth logging next to policy tapes like OM-1. One is trying to look transferable. The other is trying to look unbreakable. Neither is a deployment metric. Watch for a named team and a named event, not a second take of the same fingers on a clean floor.

WUJI is on a clip that is more origin story than product launch. The company says it takes only a few seconds to see a dexterous hand come to life, and that those seconds sit on seven years — motor to direct-drive hand, small factory to ICRA. That is Wuji Tech’s line, not a third-party audit. The official file runs twenty-three minutes under From Motor to Dexterous Hand. Treat the short hook as the sell. Treat the runtime as the history they chose to publish.
The hardware WUJI published is consistent across the site and docs. Wuji Hand lists 20 active degrees of freedom, four per finger, serial direct-drive joints, a skeleton of about 580 grams, 15 newtons at the fingertip and 10 kilograms static grasp. Hand 2, shown at ICRA 2026 booth 121, adds back-drivable actuation, force-position control and a 1-kilohertz loop. Those are spec-sheet facts. They are not proof the hand held a shift after the booth closed.
What the new clip adds is the no-playbook pitch. From data collection to end execution, Wuji Glove and Wuji Hand are supposed to be one stack: capture, stream, act. Direct drive is why. A tendon map hides slack. A joint the controller owns is what a learning pipeline can write to. That is the story WUJI wants. It is also the story that is easiest to narrate over a wake-up shot and hardest to keep when heat and dust show up.
WUJI has spent 2026 moving from factory trials toward public rooms. ICRA was the work-shaped sibling of the first Hand launch — thermal headroom and models in MuJoCo, not only a pretty curl. This week’s film is the next beat: stop talking about a motor and start talking about seven years. Fair enough as a marketing sequence. It does not retire the cycle-count question every hand still owes.
For a humanoid page the comparison is Apex and OmniHand, not a gripper that already ships. Digit’s argument is a cell coming down. WUJI’s argument is a light 20-DoF palm a policy can instrument. Both can be true and still be early. A booth that makes fingers twitch is a useful scene. A line that keeps those fingers on for a week is a different product. WUJI has not published the second number.
Rating stays at zero. A seven-year direct-drive path is worth logging next to OM-1 and Apex. One is trying to look employed as intelligence. The others are trying to look honest as hardware. None is a deployment metric. Watch the clip, keep the 20-DoF sheet, and wait for a buyer with hours. If the next video is another wake-up, this stays a company hardware story — which is still news. It is just not a counted fleet.
The pitch is continuous service work and multi-robot collab. The sites are AGIBOT’s. The hours are not public.

AGIBOT says A3 Ultra is already working in hotels, auto dealerships, supermarkets and metro inspection, with more sites coming. That is the company’s line on a 17 September tape, not an audited roster. Chinese coverage the same week named 4S shops, hotel rooms and convenience stores as the scenes in the reel: greet, pour water, talk a car, make a bed, restock a shelf. Treat those as promotional cases. What is solid is the product: a full-size service humanoid unveiled at WAIC 2026, now sold as a shift machine rather than a stage act. Bar stays at zero until someone else counts the units.
The hardware AGIBOT published at launch is consistent across trade write-ups. A3 Ultra stands 1.74 metres and weighs about 60 kilograms, with 51 degrees of freedom and up to five kilograms on each arm. Runtime is listed at up to eight hours, with direct charge, a battery swap and autonomous docking so the “continuous operation” sentence does not mean one pack for a day. Compute is NVIDIA Thor. Perception is the usual service stack: 3D LiDAR, RGB-D, fisheye and binocular cameras, plus GPS, RTK and UWB. Those are spec-sheet facts. They are not proof that a metro inspector ran last night without a minder.
What the new clip adds is the collaboration pitch. A3 Ultra is supposed to work on its own, take different tasks, and coordinate with other robots. Shanghai press described multi-unit greeting and delivery in a dealership, two-handed bed-making in a hotel, and night restock in a store. That is the story AGIBOT wants: one body, many jobs, other machines in the loop. It is also the story that is cheapest to film and hardest to verify. A humanoid that can switch tasks on a show floor is not the same as a humanoid that holds a roster across a chain.
AGIBOT has spent 2026 moving the A series from factory counts toward public rooms. The A3 platform already collected gold-medal clips at the World Humanoid Robot Games. A3 Ultra was the work-shaped sibling at WAIC — endurance and charging, not choreography. This week’s video is the next beat: stop talking about mass production and start talking about hotels. Fair enough as a marketing sequence. It does not retire the question every service humanoid still owes: how many sites, how many hours, how many human resets per shift.
For a humanoid page the comparison is Digit, not a dancing A3. Digit’s argument is a safety cell coming down. A3 Ultra’s argument is a lobby filling up. Both can be true and still be early. A dealership that lets a robot hand over keys is a useful scene. A metro inspection that runs without a safety officer walking behind is a different product. AGIBOT has not published the second number. Until it does, “everyday operations” is a caption, not a field rating.
So the 18 September lead is the tape and the label. A3 Ultra is a 174-centimetre service humanoid with an eight-hour pack and a swap path, and its maker says it is in hotels, shops, showrooms and tunnels. Watch the clip from 20 seconds. Do not promote the bar. If a named chain posts its own hours, the ranking conversation starts. If the next video is another lobby, this stays a company deployment story — which is still news. It is just not a counted fleet.

ALICE M1, AeiROBOT’s wheeled mobile humanoid, is on a clip that is more kinematics than marketing. The robot carries an object to a target pose by driving position and orientation together while both hands stay on it. The two arms and the load are treated as one closed kinematic chain, so the relative pose between the hands does not drift. That is the point of the tape: keep the grasp from shearing the part while the whole upper body walks the object through space.
Once the part sits at the target, ALICE M1 self-motions. Self-motion here means using redundant degrees of freedom to change shoulders, elbows, waist and knees without moving the object or the hands. The load stays put. The skeleton rearranges around it. In a tight aisle that is how you unload a joint that is near a limit, or slide a shoulder off a shelf edge, without putting the box down and picking it up again. The clip is a lab demonstration of that idea, not a warehouse scorecard.
The platform under the arms is the M1 already on AeiROBOT’s sheet: height 130 to 180 centimetres, about 97 kilograms with the base, 31 degrees of freedom, omnidirectional wheeled drive rather than a biped gait. Arms are 7-DoF; hands 6-DoF. Compute options include NVIDIA AGX Orin. That wheeled base is why a closed-chain carry is a fair demo. The robot is not also fighting balance on two feet while it solves the chain.
Closed-chain bimanual control is old theory and still rare on a product page. Most humanoid clips show two arms that happen to touch the same box. This one states the constraint: relative hand pose held constant, then null-space motion for posture. If the implementation is as clean as the caption, it is useful in aisles and cages. If the object still wriggles off-camera, it is a slide. The video is the evidence. There is no independent timing study attached.
For industrial readers the useful sentence is the last one in AeiROBOT’s own copy: keep the grasp and keep working when the room is cramped. That is a real failure mode on mobile manipulators — the part is fine, the elbow is not. Self-motion is how you buy another centimetre without a regrasps. Whether M1 does that at speed, under mass, next to a person, is not in this reel.
Rating stays at zero. A kinematics demo on a wheeled humanoid is worth logging next to service-floor tapes like A3 Ultra. One is trying to look employed. The other is trying to keep two hands honest. Neither is a deployment metric. Watch for a timed carry through a real fixture, not a second take of the same box on a clean floor.

VOGEBOT is a Chinese quadruped that puts four wheels on four legs and a person on top. The clip making the rounds this week — including a Portuguese-language tech recap — treats it as a mobility experiment, not a humanoid. Wheels for the smooth bits, legs for the ruts, a saddle instead of a gripper. That is a different product family from A3 Ultra and ALICE M1, and it belongs here only as the rideable-robot beat that keeps colliding with humanoid news feeds.
Public write-ups describe a wheeled quadruped that can take a rider across slopes and uneven ground. Independent spec sheets are thin. Do not borrow numbers from DaxAI’s Qiji horse or Unitree’s B2-W just because those also carry a person. VOGEBOT is its own tape. What we can say from the video and the caption is the layout: four legs, four wheels, one rider, rough terrain as the selling point. Speed, mass, range and maker legal name are not in a document we will treat as locked.
Rideable quadrupeds are having a second life in China after Unitree showed a person on B2-W and DaxAI showed a full-size robot horse. VOGEBOT sits in that lane: personal transport that can step where a scooter cannot. Inspection and rescue get named in recaps because every rideable robot eventually does. Those uses are speculation until a named agency buys one. For now the verified object is a demo machine that carries a human and mixes wheels with legs.
Why it is in a humanoid brief: readers keep asking whether the future of “robot mobility” is two legs at human height or four legs under a seat. Digit and A3 Ultra bet on walking through a door. VOGEBOT bets on not needing the door. Both answers can ship. Only one of them folds towels. The digest is here so the page does not pretend every interesting robot this week was a biped.
Safety is the open file. A wheeled-leg platform with a rider is a vehicle. Balance, braking, and what happens when a leg tucks at speed are not addressed in a highlight reel. Until there is a certification story or a test report, treat “carry a person” as a demonstration, not an invitation. Same standard we use for robot horses.
Rating stays at zero. A rideable hybrid is news; it is not a humanoid deployment. Watch the clip, keep the name distinct from Qiji and B2-W, and wait for a spec page with a company letterhead. If VOGEBOT publishes mass, speed and a buyer, it earns a longer slot. Today it is a mobility sidebar with a clean video ID and no invented numbers.
September 2026
Supply-chain reports confirm Tesla ordering parts for ~15,000 Optimus units in 2026, targeting ~1,000 units/week by late year. Production focuses on the dedicated “Optimus Academy” inside Fremont for real-world training data collection; supply-chain hurdles remain significant.
September 15, 2026
Agility unveiled Digit 5, built on over 65,000 hours of commercial operation and new 13-DoF hands. The platform enables true close-proximity human collaboration without barriers; IPO via Churchill Capital Corp XI merger and Fort Robotics MoU for safety infrastructure also announced.
September 23, 2026
Boston Dynamics opened a dedicated Atlas training and testing center at Hyundai’s Georgia Metaplant. The facility prepares production-intent Atlas units for automotive manufacturing roles, emphasizing tool handling and reinforcement-learning policies. All 2026 Atlas output remains committed to Hyundai + Google DeepMind.
August 25, 2026
BotQ production sustained at one robot per hour. Figure 03 now sorting and sequencing parts at Spartanburg; continuous multi-day package demos draw industry attention.
August 2026
Global humanoid shipments surge 272% YoY. Chinese makers hold ~97% of volume; Unitree IPO and factory deployments accelerate the commercial phase.
Late July – August 2026
Former Model S/X space converted; low-volume builds start for internal training and data collection. External sales still targeted later.
July 23, 2026
Figure AI becomes the first U.S. humanoid company to surpass 1,000 units produced. Throughput jumps and supply-chain localization continue.
July 2026
Digit fleets expand at GXO and new sites including Toyota Canada. Operating hours and contracted pipeline strengthen commercial leadership claims.
July 2026
All 2026 Atlas production committed to Hyundai and Google DeepMind. Heavy-lift and whole-body control demos advance the industrial case.
June 2026
After successful Figure 02 body-shop work, Figure 03 takes on more complex parts sorting and sequencing in a live production environment.
June 2026
JCPenney parent deploys Figure 03 fleets at Reno logistics center — one of the first major retail-supply-chain humanoid contracts.
Late May – June 2026
Open physical-AI foundation model unifies world generation, visual reasoning and action simulation — core infrastructure for humanoid training pipelines.
May 2026
1,250+ operating hours, 90,000+ parts handled, contribution to 30,000+ X3 vehicles — the clearest Western commercial proof point to date.
May 2026
Manufacturing and logistics pilots deepen; Jabil partnership advances “robots that build robots” manufacturing model.
May–June 2026
AgiBot, Unitree, UBTech and Xiaomi push high-volume production and real factory task training (nut installation, panel sorting, logistics).
April 2026
Additional logistics and automotive customers come online; RaaS model and operating-hour data continue to differentiate Agility.
April–May 2026
Limited Optimus units operate on battery-cell and parts-handling tasks inside Fremont and Texas while production lines are prepared.
Spring 2026
Omniverse, Cosmos and human-motion foundation models tighten the loop between synthetic data, policy learning and real humanoid control.
March 2026
World models, simulation pipelines and reference humanoid platforms take center stage as the industry shifts from demos to scalable training data.
March 2026
First production units allocated to Hyundai industrial sites and Google DeepMind research; strength and whole-body control emphasized.
Q1 2026
Live trackers, HPS-style leaderboards and side-by-side capability databases emerge as key reference points for operators and investors.
February 2026
Digit expands from pure logistics into automotive manufacturing environments under a formal Robots-as-a-Service contract.
February 2026
BMW results, early warehouse deals and production-rate targets set the competitive baseline that Chinese volume players and Tesla will be measured against.
Early 2026
High shipment numbers and new production capacity announcements reinforce China’s early lead in pure unit volume.
January 2026
Boston Dynamics presents the production-intent electric Atlas; 2026 output fully committed to Hyundai and research partners.
January 2026
Conversion of former vehicle production space begins; internal deployment and data-collection focus remains the near-term priority.
January 2026
Agility, Figure, Apptronik and Chinese platforms move from pilots into multi-site, multi-customer operations as the industry enters its first true deployment year.